Langostino — The Swarm Drone
Open-source AI autopilot for the real world: understand it, build it, and fly it.
An open-source autonomous flight reference platform, built with a global community.
Table of Contents
[See It In Action](#see-it-in-action)
[About The Project](#about-the-project)
[Getting Started](#getting-started)
[Flight Plan](#flight-plan)
[Deep Dive Articles](#deep-dive-articles)
[Documentation](#documentation)
[Project Structure](#project-structure)
[Community](#community)
[FAQ](#faq)
[Share Pack](#share-pack)
[License](#license)
See It In Action
Assemble the drone and fly it autonomously
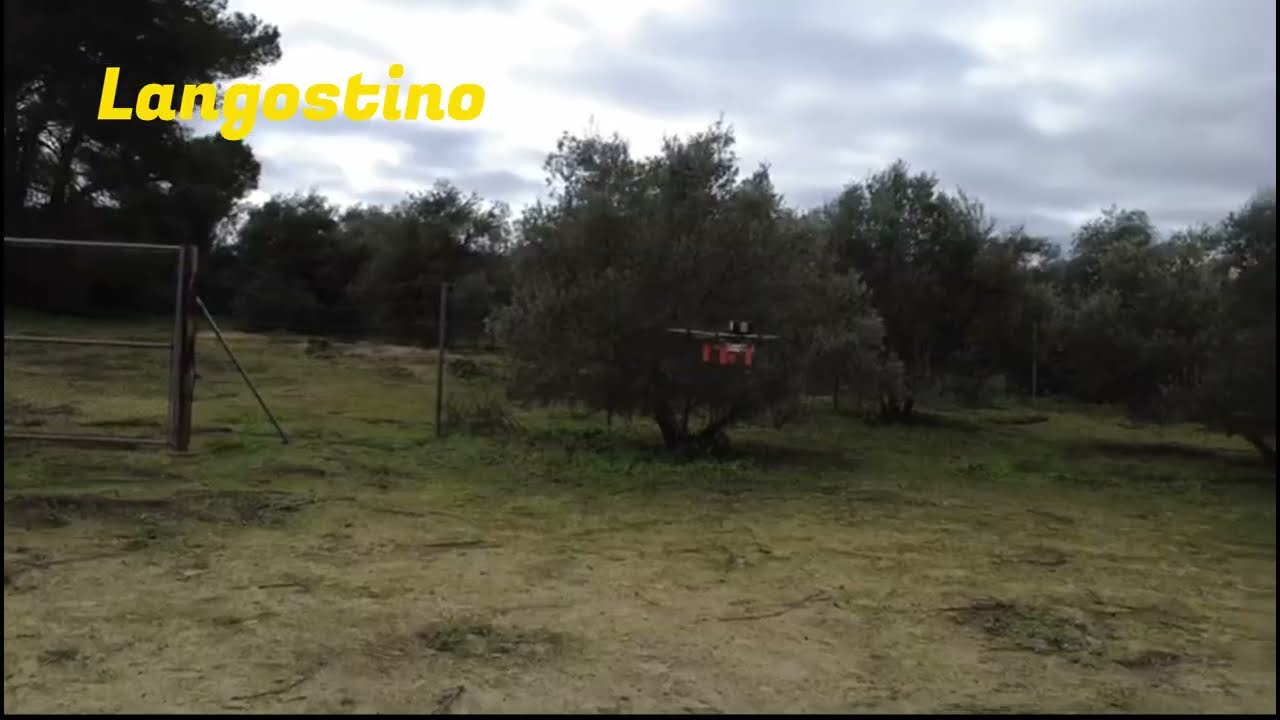
"Build from scratch" drone holding its position
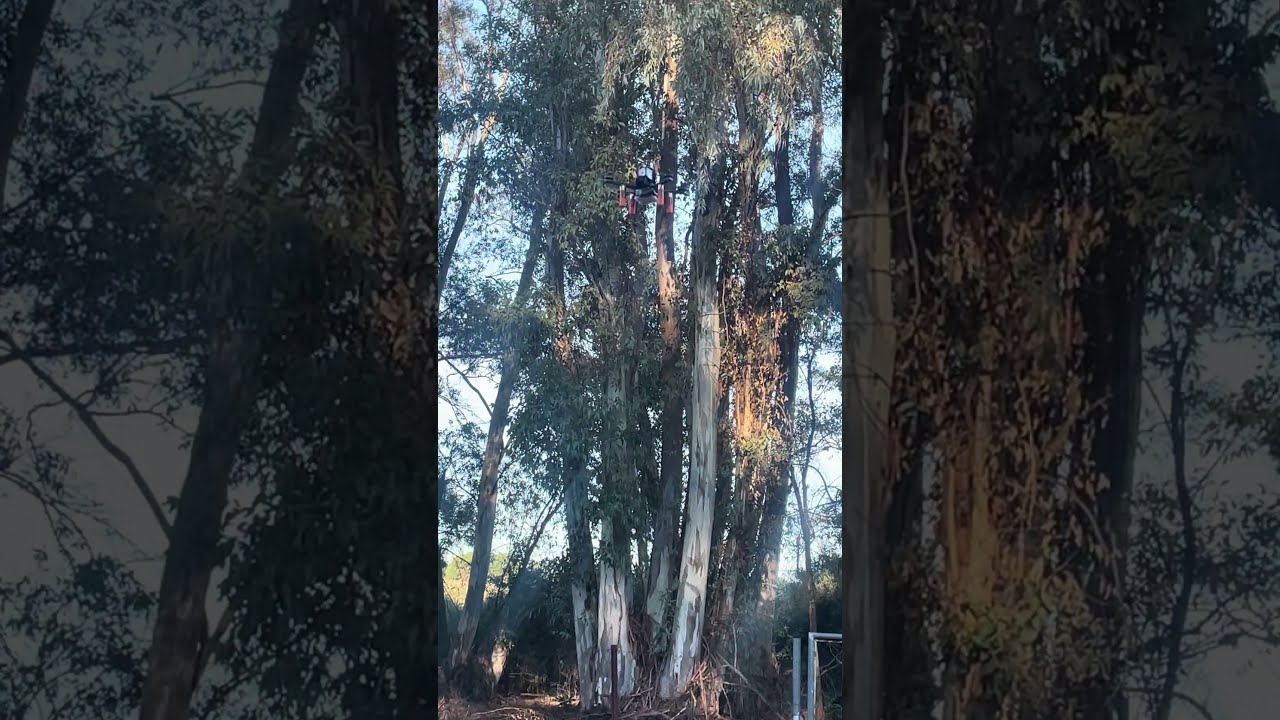
Fly it and improve it!
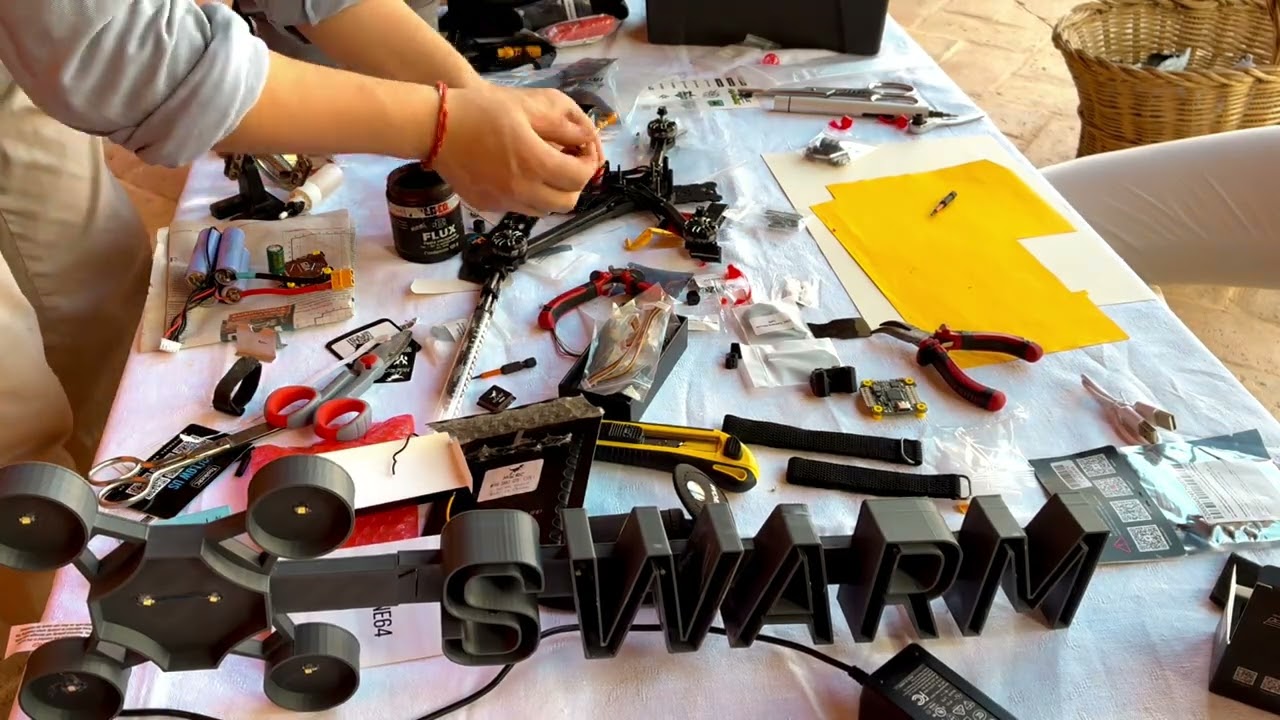
Do it yourself, from ZERO!
Example of what you will be building
If this made you curious, star the repo and share the demo.
About The Project
Langostino is an open-source reference drone for real-world autonomous flight — designed to be easy to understand, build, and extend.
- A practical AI autopilot project focused on flying in the real world (not a black box)
- A complete reference platform: code, docs, and a clear path from "zero" to "first flight"
- Made to be adapted: use it as a starting point for your own drone and your own experiments
- Community-driven: built in the open, improved by builders and contributors worldwide
Why It Matters
Autonomous drones shouldn't feel like magic or closed black boxes. Langostino exists to make real-world autonomy understandable and buildable — so more people can learn, iterate, and ship useful aerial systems.
By sharing a reference drone in the open, we lower the barrier from "curious" to "first flight", and turn progress into something the whole community can reuse.
Built With
Getting Started
[!CAUTION] ⚠️ Langostino is a real flying machine.
- Follow local regulations
- Test in a safe environment responsibly and keep propellers off during bench tests.
- Drones can cause injury and property damage.
- Use prop guards and appropriate failsafes
Pick what you want to do next — you don't need to be an expert to start.
I'm just curious
    Watch the demo (above)
    Star this repo
    Share it with a friend
I want to build it from scratch
Includes the parts list (BOM) and step-by-step build instructions.
I want to use the model
I want to contribute
    Join [Discord](https://discord.gg/txzvKMSd)
    Read [CONTRIBUTING.md](CONTRIBUTING.md)
    Pick a [good first issue](https://github.com/swarm-subnet/Langostino/issues?q=is%3Aissue+is%3Aopen+label%3A%22good+first+issue%22)
Flight Plan
Your path from zero to first flight:
-
Get the parts — Use the BOM as your shopping list to source every component.
-
Assemble the airframe — Follow the build guide step-by-step. Build guide →
-
Install, then wire it up — Follow the quickstart checklist step by step. Quickstart →
-
Troubleshooting — Diagnose setup, hardware, and runtime issues quickly with step-by-step checks. Troubleshooting guide →
-
Go outside & share — Short flight, record a clip, star the repo, post your build. Join Discord →
Want the bigger picture? See the Swarm roadmap →
Deep Dive Articles
Want to understand the project in depth? Check out our Substack series that walks through every aspect of building and flying Langostino.
| Chapter | Topic | Description |
|---|---|---|
| Chapter 1 | Inside the Drone | Hardware components and drone anatomy |
| Chapter 2 | The Wiring Brain | Wiring, connections, and power distribution |
| Chapter 3 | From Data to Motion | Software architecture and data flow |
| Chapter 3.5 | Additional Configurations | Advanced configuration and tuning |
Documentation
Find detailed guides for every aspect of the project.
| Category | Document | Description |
|---|---|---|
| Building | Assembly Guide | Complete build guide from parts to first flight |
| Bill of Materials | Full parts list with purchase links | |
| INAV | INAV Configuration | Flight controller setup, PID tuning, MSP configuration |
| ROS2 | Setup Guide | Ubuntu + ROS2 Humble installation on Raspberry Pi |
| Commands Guide | ROS2 commands and node operations | |
| Config Parameters | Complete ROS2 node configuration reference | |
| Tools | Map Proxy | Offline map tile server for ground station |
| Help | Troubleshooting | Common issues and solutions |
| Contributing | How to contribute to the project |
Project Structure
Click to expand
swarm-ros/
├── src/
│   └── swarm_ai_integration/       # Main ROS2 package
│       ├── swarm_ai_integration/   # Python nodes (FC adapter, LiDAR, AI)
│       ├── config/                 # ROS2 parameter files
│       ├── launch/                 # Launch files
│       └── scripts/                # Utility scripts
├── scripts/
│   ├── setup_22_04.sh              # Ubuntu 22.04 setup script
│   ├── setup_24_04.sh              # Ubuntu 24.04 setup script
│   ├── network_setup_*.sh          # Network configuration scripts
│   ├── verify_setup.sh             # Installation verification
│   └── launch.sh                   # Quick launch script
├── docs/
│   ├── assembly/                   # Build guides and BOM
│   ├── SETUP_GUIDE.md              # ROS2 environment setup
│   ├── INAV_GUIDE.md               # Flight controller configuration
│   ├── COMMANDS_GUIDE.md           # ROS2 commands reference
│   ├── CONFIG_PARAMS_GUIDE.md      # Configuration parameters
│   └── TROUBLESHOOTING_GUIDE.md    # Common issues and fixes
├── assets/
│   └── 3D_print_STL/               # 3D printable parts (mounts, etc.)
├── inav-custom-firmware/           # Custom INAV firmware builds
├── mapproxy/                       # Offline map tile server
├── model/                          # AI model files
├── flight-logs/                    # Flight data logs
└── README.md                       # This file
Community
Langostino is built with a global community of builders and contributors. If you're building, testing, or improving it — we want to hear from you.
Share your build log or flight clip in Discord — we feature the best builds.
FAQ
Do I need to be an engineer?
No. Langostino is designed to be approachable: clear docs, a guided setup, and a community that can help you get started.
How do I get started?
Start with the Quick Setup Guide if you already have compatible hardware. Otherwise, refer to the Assembly Guide for a list of materials and steps to follow. Join Discord if you have any questions.
How do I contribute?
Join Discord, check CONTRIBUTING.md, and pick a good first issue.
Share Pack
Want to help Langostino reach more builders? Copy/paste one of these.
X (Twitter)
Open-source AI autopilot for real-world drones

Langostino is a reference drone you can understand, build, and fly — built with a global community.

https://github.com/swarm-subnet/Langostino
Where to share
- Hackaday — open hardware / DIY audience
- DIY Drones — builders who actually fly
- Reddit — consider: r/drones, r/Multicopter, r/robotics (follow each subreddit's rules)
License
Distributed under the MIT License. See LICENSE for more information.
Happy flying!