Asimov v0, an open-source bipedal robotic legs
Asimov is a complete bipedal leg for humanoid robots, built with off-the-shelf components and compatible with low-volume manufacturing processes.
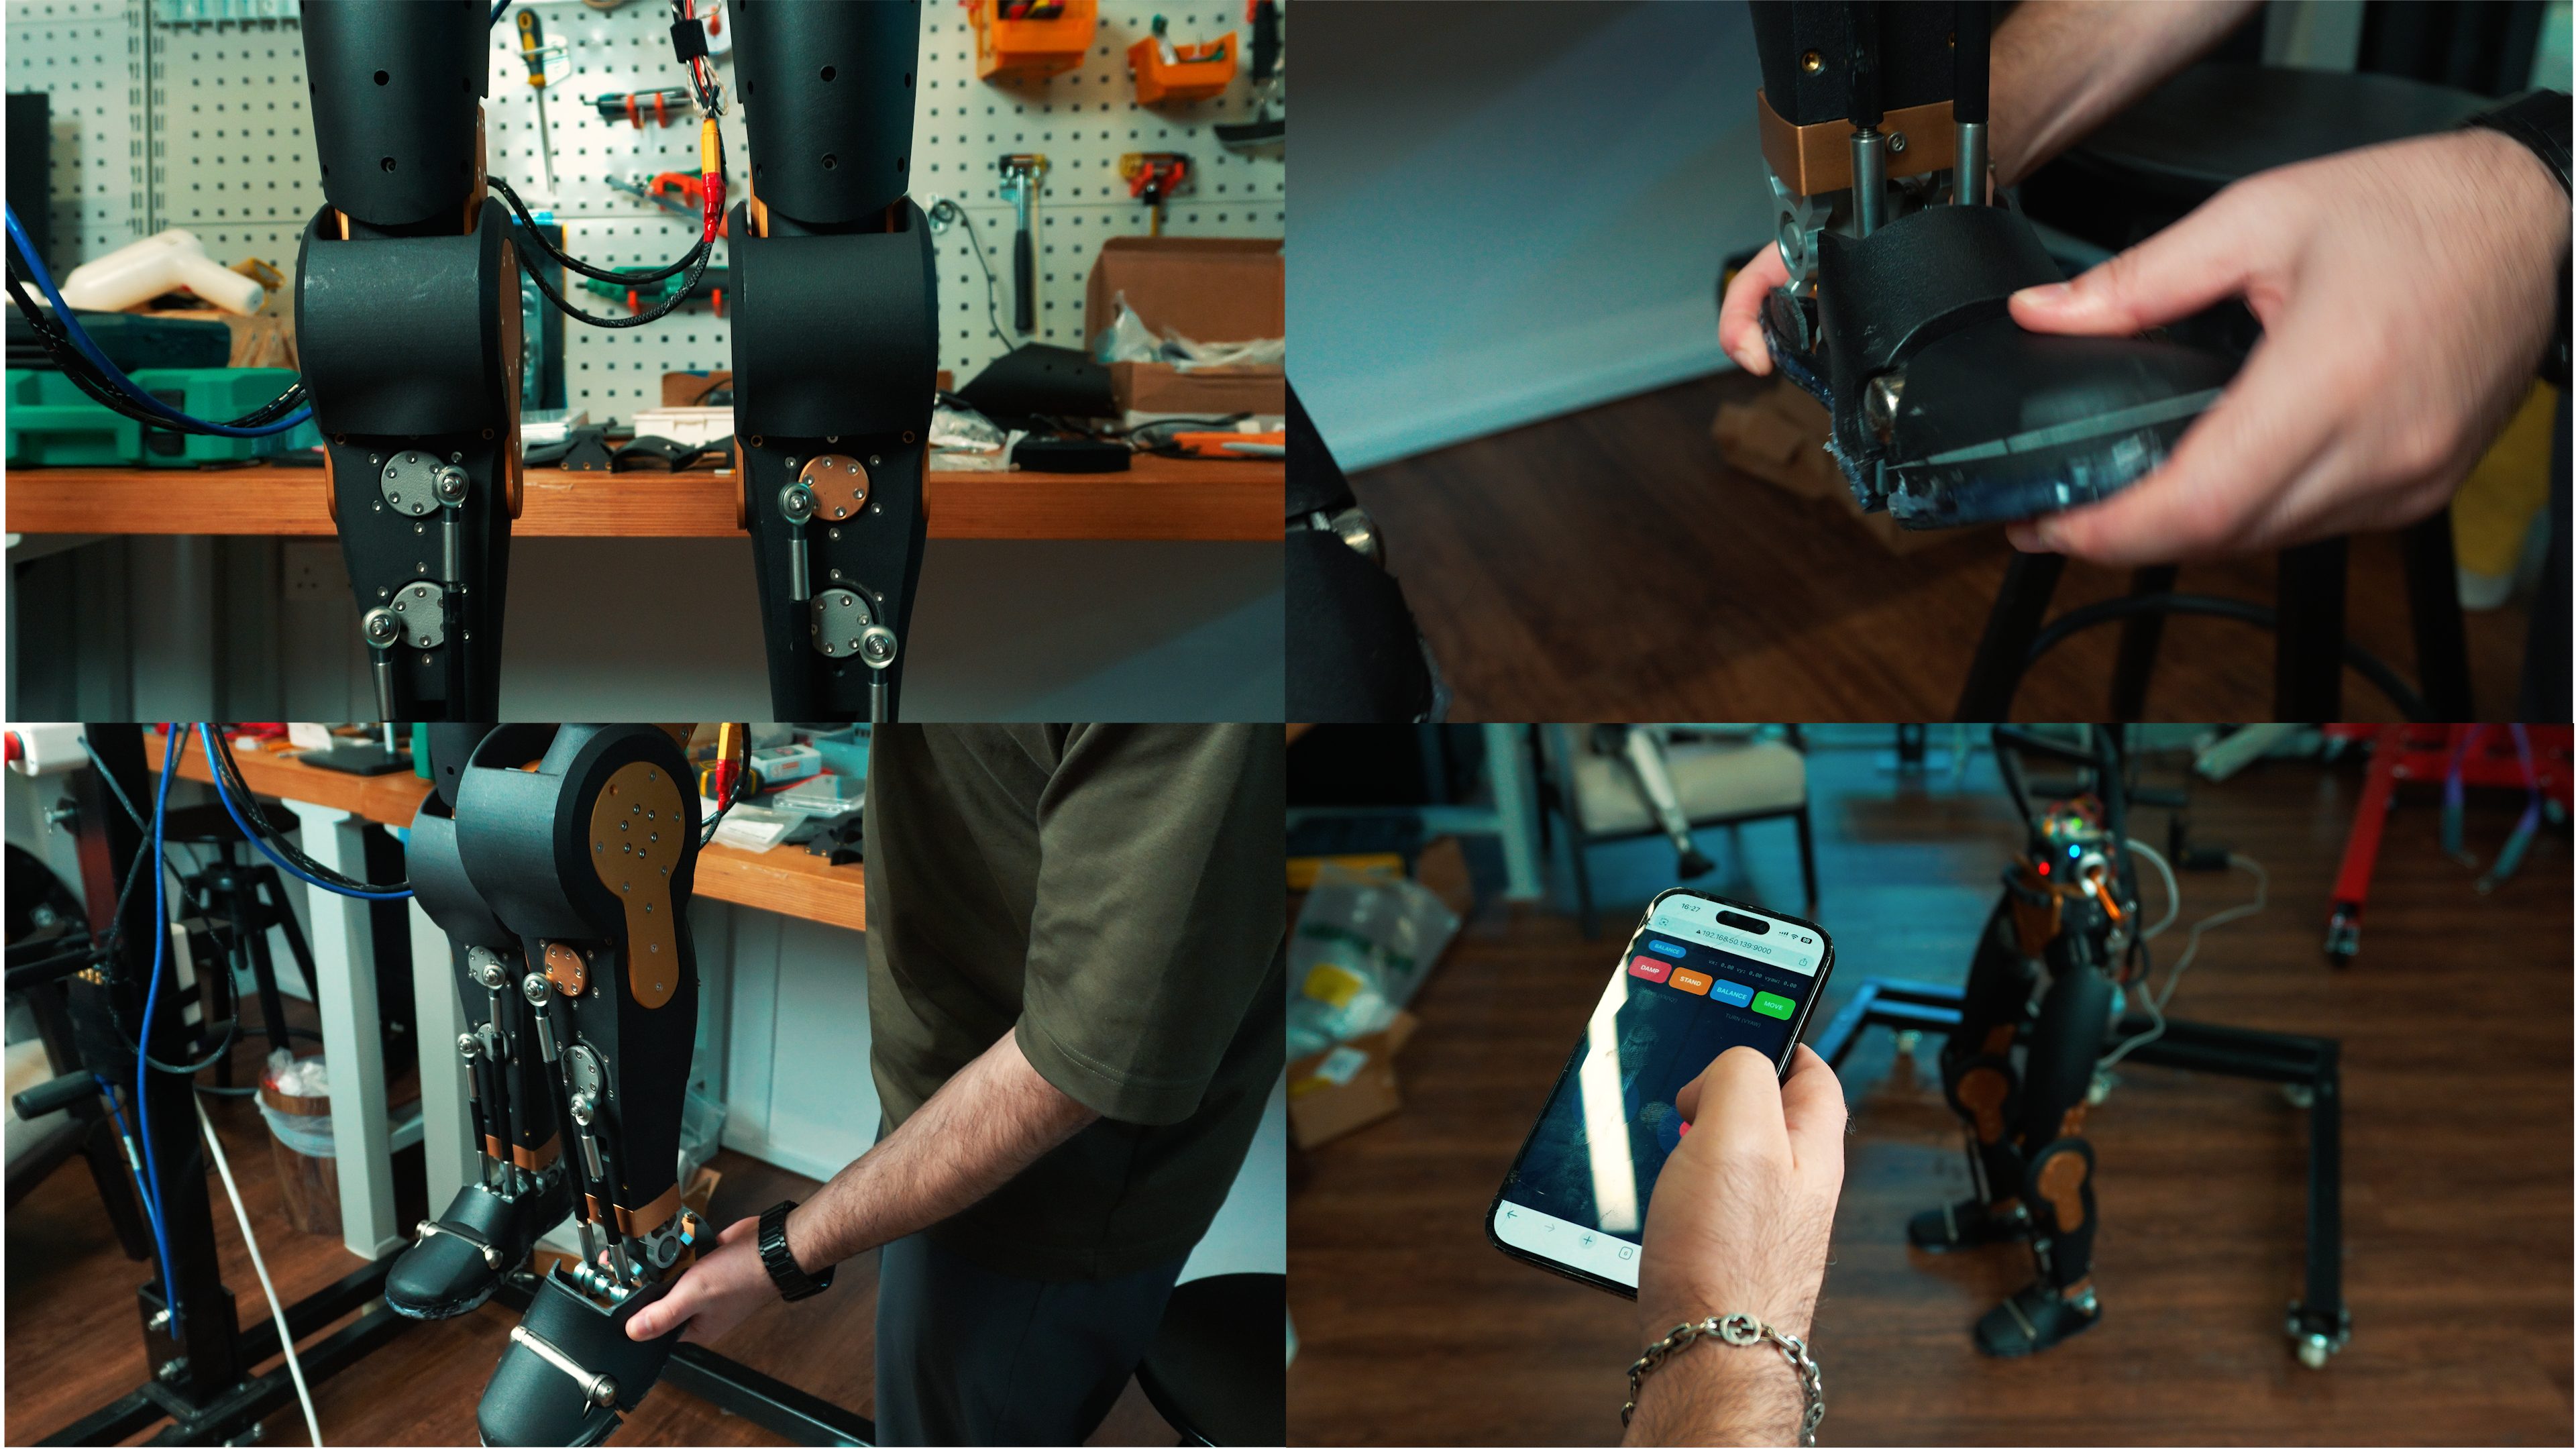
Specifications
- 12 DOF actuation, 6 DOF per leg
- Articulated toe
- RSU (Revolute Spherical Universal) ankle mechanism
- MJF 3D printing compatible
Left Leg
| Name | Joint | Min | Max | Peak Torque |
|---|---|---|---|---|
| L_Hip_Pitch | Hip flexion/extension | -120° | +57° | 120 Nm |
| L_Hip_Roll | Hip abduction/adduction | -45° | +45° | 90 Nm |
| L_Hip_Yaw | Hip rotation | -45° | +45° | 60 Nm |
| L_Knee_Pitch | Knee flexion/extension | 0° | +86° | 75 Nm |
| L_Ankle_A | Ankle dorsi/plantarflexion | -70° | +70° | 36 Nm |
| L_Ankle_B | Ankle inversion/eversion | -70° | +70° | 36 Nm |
Right Leg
| Name | Joint | Min | Max | Peak Torque |
|---|---|---|---|---|
| R_Hip_Pitch | Hip flexion/extension | -57° | +120° | 120 Nm |
| R_Hip_Roll | Hip abduction/adduction | -45° | +45° | 90 Nm |
| R_Hip_Yaw | Hip rotation | -45° | +45° | 60 Nm |
| R_Knee_Pitch | Knee flexion/extension | -86° | 0° | 75 Nm |
| R_Ankle_A | Ankle dorsi/plantarflexion | -70° | +70° | 36 Nm |
| R_Ankle_B | Ankle inversion/eversion | -70° | +70° | 36 Nm |
Motors
- Motors from Encos
| Joint | Model |
|---|---|
| Pitch | EC-A6416-P2-25 |
| Roll | EC-A5013-H17-100 |
| Yaw | EC-A3814-H14-107 |
| Knee_Pitch | EC-A4315-P2-36 |
| Ankle_A | EC-A4310-P2-36 |
| Ankle_B | EC-A4310-P2-36 |
Support the project
Asimov is Menlo Research's open-source humanoid robot:
- If you want to support development: asimov.inc/early
- For partnerships: [email protected]