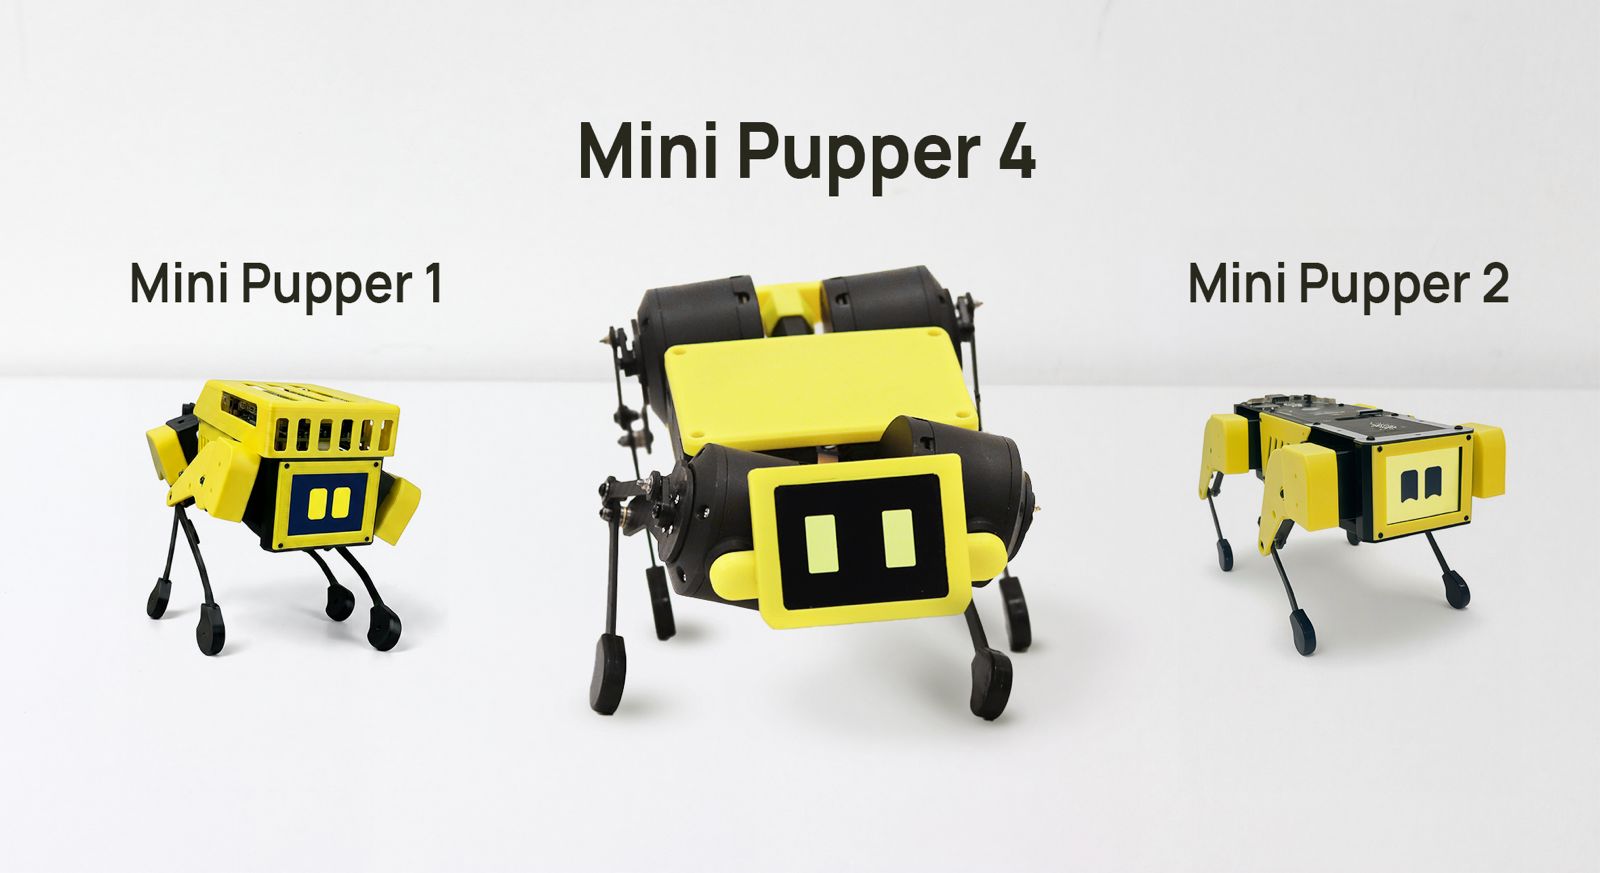
Mini Pupper 4
From Learning to Earning — Powered by 3-DoF Coreless Smart Servos.
Official Website · Facebook Group · Discord Community · Online Shop · Contributing Guide
Capabilities & Frameworks
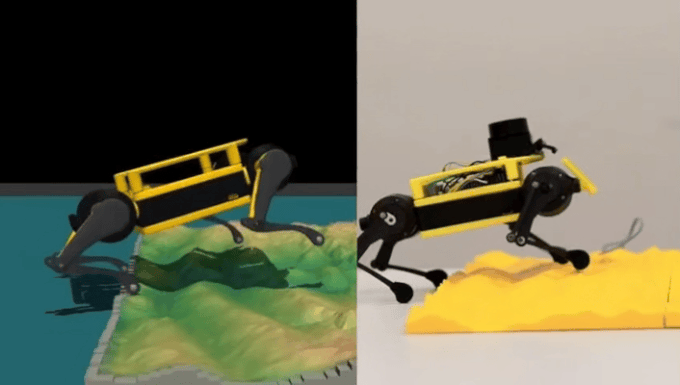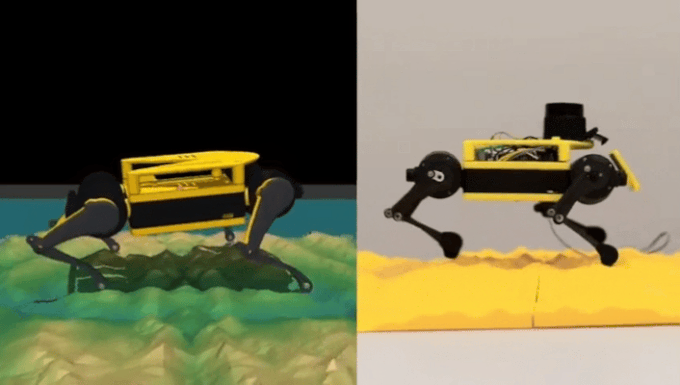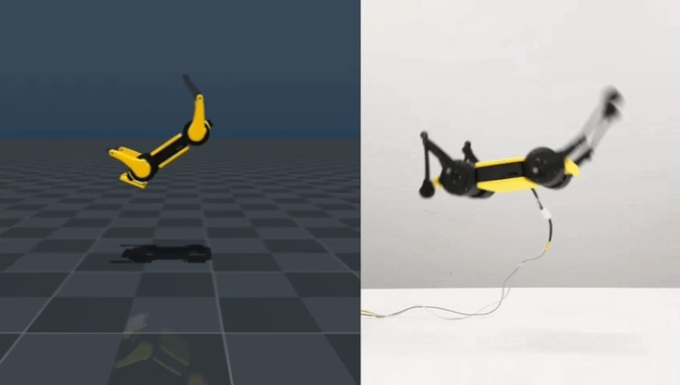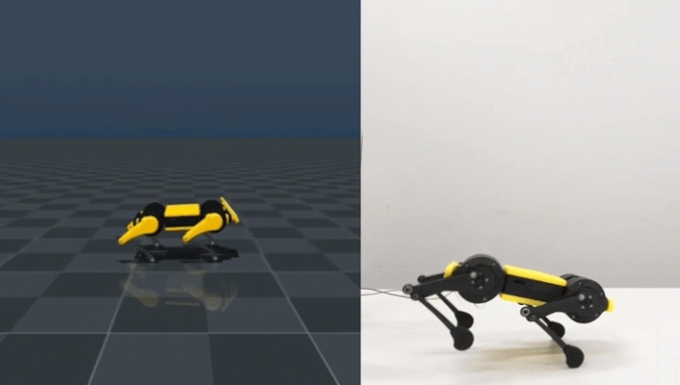
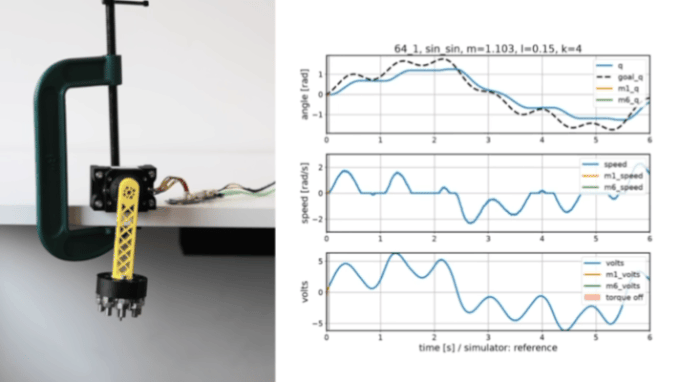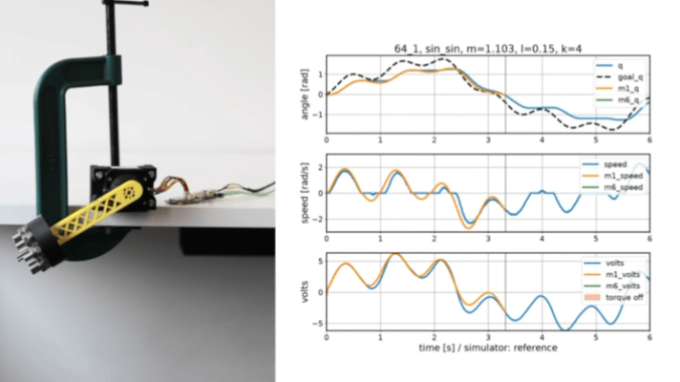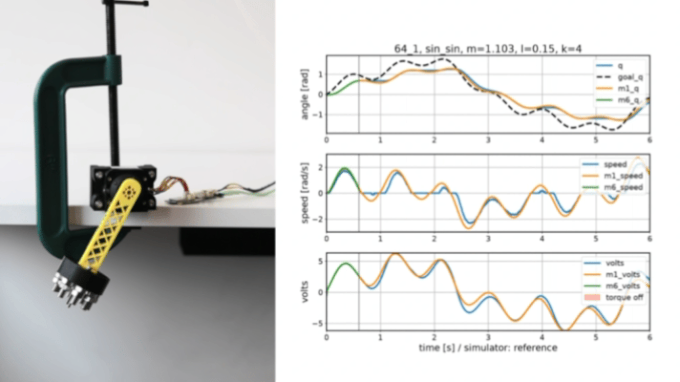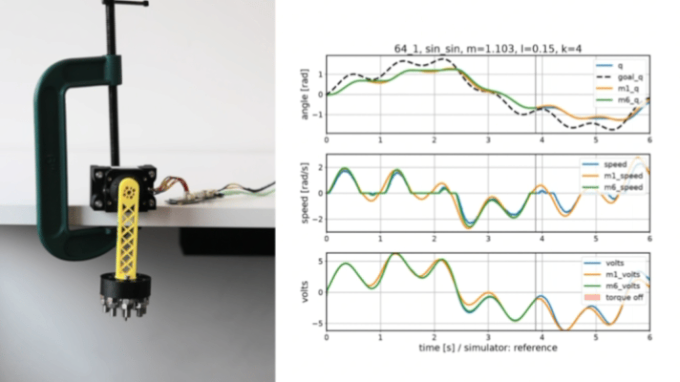
Close the Sim2Real Gap. Train complex neural network policies flawlessly in high-fidelity simulation, and deploy straight to the real physical robot.
Native BAM Integration. Fully compatible with Better Actuator Models (BAM) to capture precise joint friction physics, letting you focus on your advanced applications.
Low-Level micro-ROS. Native support for micro-ROS pipelines directly on the microcontroller for reliable, real-time actuator control.
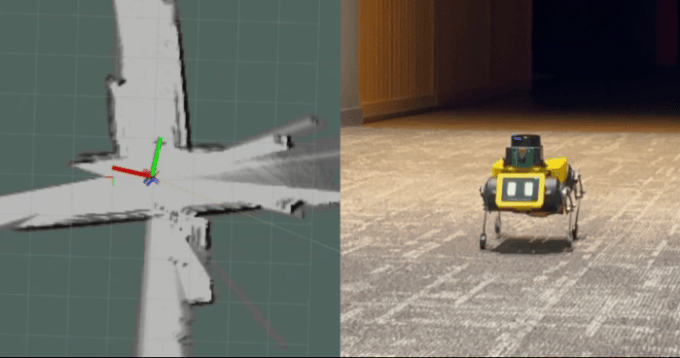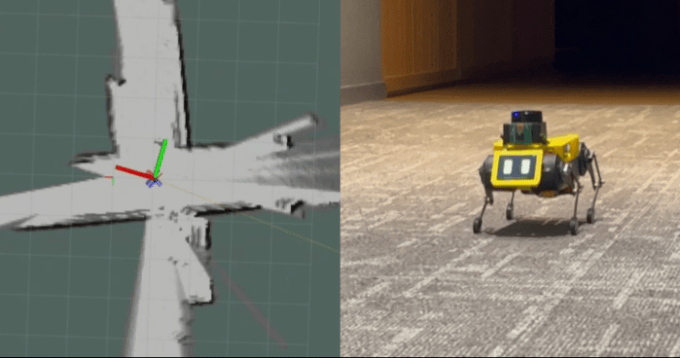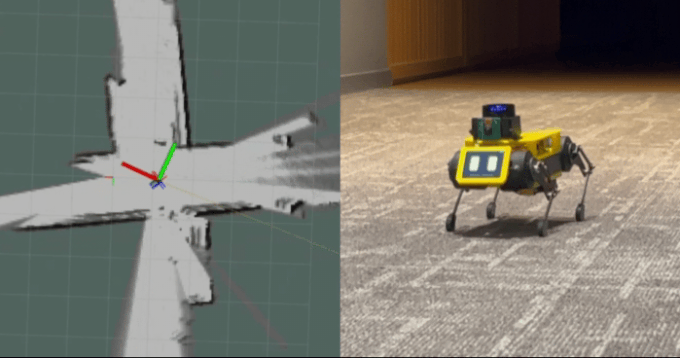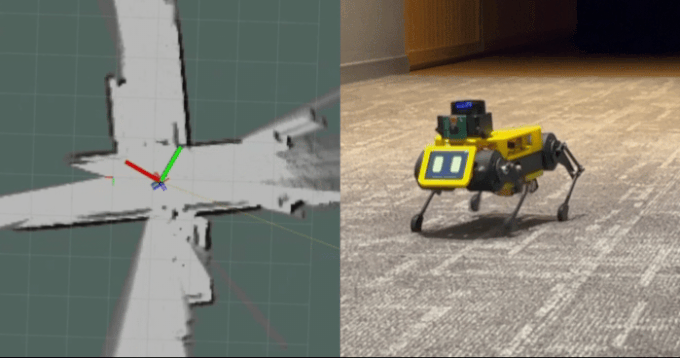
Next-Gen ROS 2 Jazzy. Ready-to-run out-of-the-box templates for advanced SLAM mapping, path planning, and autonomous Nav2 stacks.
All capabilities stem from our proprietary high-performance, 3-DoF coreless smart servo joints — the ultimate, versatile building block for modern open-source robotics.
Open Source Repo Guide
| Github Repo | Description |
|---|---|
| 🤖 RL | The physics engine backend: MuJoCo and NVIDIA Isaac environments, PPO pipelines, domain randomization, and the baked-in ONNX export runtime. |
| ⚙️ BAM Friction Engine | Hardware actuator physics repository. The MangDang MD-300C-150 servo is fully benchmarked and adapted to BAM. |
| 🛹 ROS 2 Core Stack | ROS software platform. We follow the official Open Robotics roadmap with stable support up to ROS 2 Jazzy and Lyrical. |
| 📡 micro-ROS Stack | micro ROS software platform. Real-time lower-level agent bridging. |
| 🧠 MCU Brain | Complete firmware layer source code for the onboard microcontroller, including embedded local AI routing. |
| 🍓 Raspberry Pi Brain | High-level application space source code tailored for the Raspberry Pi computing chassis. |
| 🤝 CONTRIBUTING.md | Developer guidelines for compiling, local simulation testing, layout conventions, and code submission rules. |
| 📖 Online Manual | Comprehensive documentation hub, including modular mechanical blueprints, PCB schematics, and open research challenges. |
| mini pupper 1 bsp | BSP(board support package) for Mini Pupper 1. |
| mini pupper 2 bsp | BSP(board support package) for Mini Pupper 2. |
| mini pupper web controller | This code provides a web GUI for Mini Pupper 1&2 running StanfordQuadruped. |
Contributions
Repositories
| Repository | Description | Status |
|---|---|---|
| minipupper_kinematics | This repositories contains Jupyter notebook that used to gain a better understanding of the kinematics of a quadruped robot in general and Mini Pupper 1 in particular. | experimental |
| mini-pupper-jupyter-notebooks | ROSCon2022 Jupyter Notebooks for Mini Pupper 1. | experimental |