← 开源
legubiao

quadruped_ros2_control

ROS2-Control implementations for Quadruped robots, include sim2real

Model DevelopmentEnvironmentsPhysical AIC++
在 GitHub 打开
增长势头
+024 小时新增 Star0.0%
578
Star
75
Fork
+2
本周
1
贡献者
创建于 2024-09-09 · 更新于 2026-10-13 · 今日第 16677 名
主要开发者

legubiao/quadruped_ros2_control 排名第 16,677,有 578 个星标。

同类别比较

legubiao/quadruped_ros2_control 排名第 16,677,此处有 8 个同类条目;lin-shuyu/VAE-LSTM-for-anomaly-detection 排名第 16,678。

同类别比较
名称排名指标
Project-Splinter/MonoPort16,670
语言:
Python
星标数:
578
分叉数:
81
简介:
Volumetric Human Teleportation (SIGGRAPH 2020 Real-Time Live) Monocular Real-Time Volumetric Performance Capture(ECCV 2020)
Zardinality/WGAN-tensorflow16,672
语言:
Jupyter Notebook
星标数:
578
分叉数:
195
简介:
a tensorflow implementation of WGAN
clvrai/furniture16,673
语言:
Python
星标数:
578
分叉数:
63
简介:
IKEA Furniture Assembly Environment for Long-Horizon Complex Manipulation Tasks
jannerm/ddpo16,675
语言:
Python
星标数:
578
分叉数:
35
简介:
Code for the paper "Training Diffusion Models with Reinforcement Learning"
lin-shuyu/VAE-LSTM-for-anomaly-detection16,678
语言:
Jupyter Notebook
星标数:
578
分叉数:
95
简介:
We propose a VAE-LSTM model as an unsupervised learning approach for anomaly detection in time series.
materialyzeai/matgl16,679
语言:
Python
星标数:
578
分叉数:
120
简介:
Graph deep learning library for materials
Bartzi/see16,685
语言:
Python
星标数:
577
分叉数:
146
简介:
Code for the AAAI 2018 publication "SEE: Towards Semi-Supervised End-to-End Scene Text Recognition"
Mostafa-Samir/DNC-tensorflow16,688
语言:
Jupyter Notebook
星标数:
577
分叉数:
161
简介:
A TensorFlow implementation of DeepMind's Differential Neural Computers (DNC)
关键参数与规格
关键参数与规格
参数值
语言C++
类别Model Development
子类别Environments,Physical AI
关键词Agent-ready APIs, Digital twins, Embodied
星标数578
分叉数75
贡献者1
创建日期2024-09-09
更新日期2026-10-13
1 天星标数0
7 天星标数2
排名16,677
上次排名16,466
排名变化-211
7 天星标排名8,788
上次 7 天星标排名6,462
7 天星标排名变化-2,326
总星标排名17,284
上次总星标排名17,257
总星标排名变化-27
README 摘录

Quadruped ROS2 Control This repository contains the ros2-control based controllers for the quadruped robot. Controllers: contains the ros2-control controllers Commands: contains command node used to send command to the controller Descriptions: contains the urdf model of the robot Hardwares: contains the ros2-control hardware interface for the robot **Warning:** Default branch was developed under ROS2 Jazzy. For ROS2 Humble, please check out **humble** branch. Quick Start rosdep Compile the package 1. 1 Mujoco Simulator or Real Unitree Robot

**Warning:** CycloneDDS ROS2 RMW may conflict with unitree_sdk2. If you cannot launch unitree mujoco simulation without , then you cannot used . This conflict could be solved by one of below two methods: 1. Uninstall CycloneDDS ROS2 RMW, used another ROS2 RMW, such as FastDDS **[Recommended]**. Follow the guide in unitree_ros2 to configure the ROS2 RMW by Compile Unitree Hardware Interfaces Follow the guide in unitree_mujoco to launch the unitree mujoco go2 simulation Launch the ros2-control Run the

keyboard control node 1. 3 Gazebo Harmonic Simulator Install Gazebo Compile Gazebo Playground Launch the ros2-control Run the keyboard control node For more details, please refer to the unitree guide controller and go2 description. You have successfully launched the quadruped robot in the simulation. Here are some suggestions for you to have a try: **More Robot Models** could be found at description **Try more controllers**. OCS2 Quadruped Controller: Robust MPC-based controller for quadruped robot RL Quadruped Controller: Reinforcement

learning controller for quadruped robot **Simulate with more sensors** Gazebo Quadruped Playground: Provide gazebo simulation with lidar or depth camera. **Real Robot Deploy** Unitree Go2 Robot: Check here about how to deploy on go2 robot. Reference Conference Paper [1] Liao, Qiayuan, et al. "Walking in narrow spaces: Safety-critical locomotion control for quadrupedal robots with duality-based optimization. " In *2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)*, pp. *legged\_control: An open-source NMPC, WBC, state estimation

, and sim2real framework for legged robots*. *rl\_sar: Simulation Verification and Physical Deployment of Robot Reinforcement Learning Algorithm.

常见问题

记录了多少星标和分叉?

legubiao/quadruped_ros2_control 有 578 个星标和 75 个分叉。

仓库排名是多少?

legubiao/quadruped_ros2_control 排名第 16,677。

记录的语言和类别是什么?

legubiao/quadruped_ros2_control 有 578 个星标,语言为 C++,类别为 Model Development。

哪个仓库排名最接近?

legubiao/quadruped_ros2_control 与 lin-shuyu/VAE-LSTM-for-anomaly-detection 比较,后者排名第 16,678,有 578 个星标。

README

Quadruped ROS2 Control

This repository contains the ros2-control based controllers for the quadruped robot.

  • Controllers: contains the ros2-control controllers
  • Commands: contains command node used to send command to the controller
  • Descriptions: contains the urdf model of the robot
  • Hardwares: contains the ros2-control hardware interface for the robot

Warning: Default branch was developed under ROS2 Jazzy. For ROS2 Humble, please check out humble branch.

Todo List:

  • [x] [2025-02-23] Add Gazebo Playground
    • [x] OCS2 controller for Gazebo Simulation
    • [x] Refactor FSM and Unitree Guide Controller
  • [x] [2025-03-30] Add Real Go2 Robot Support
  • [x] [2025-05-20] Isaac Sim Support
  • [ ] OCS2 Perceptive locomotion demo

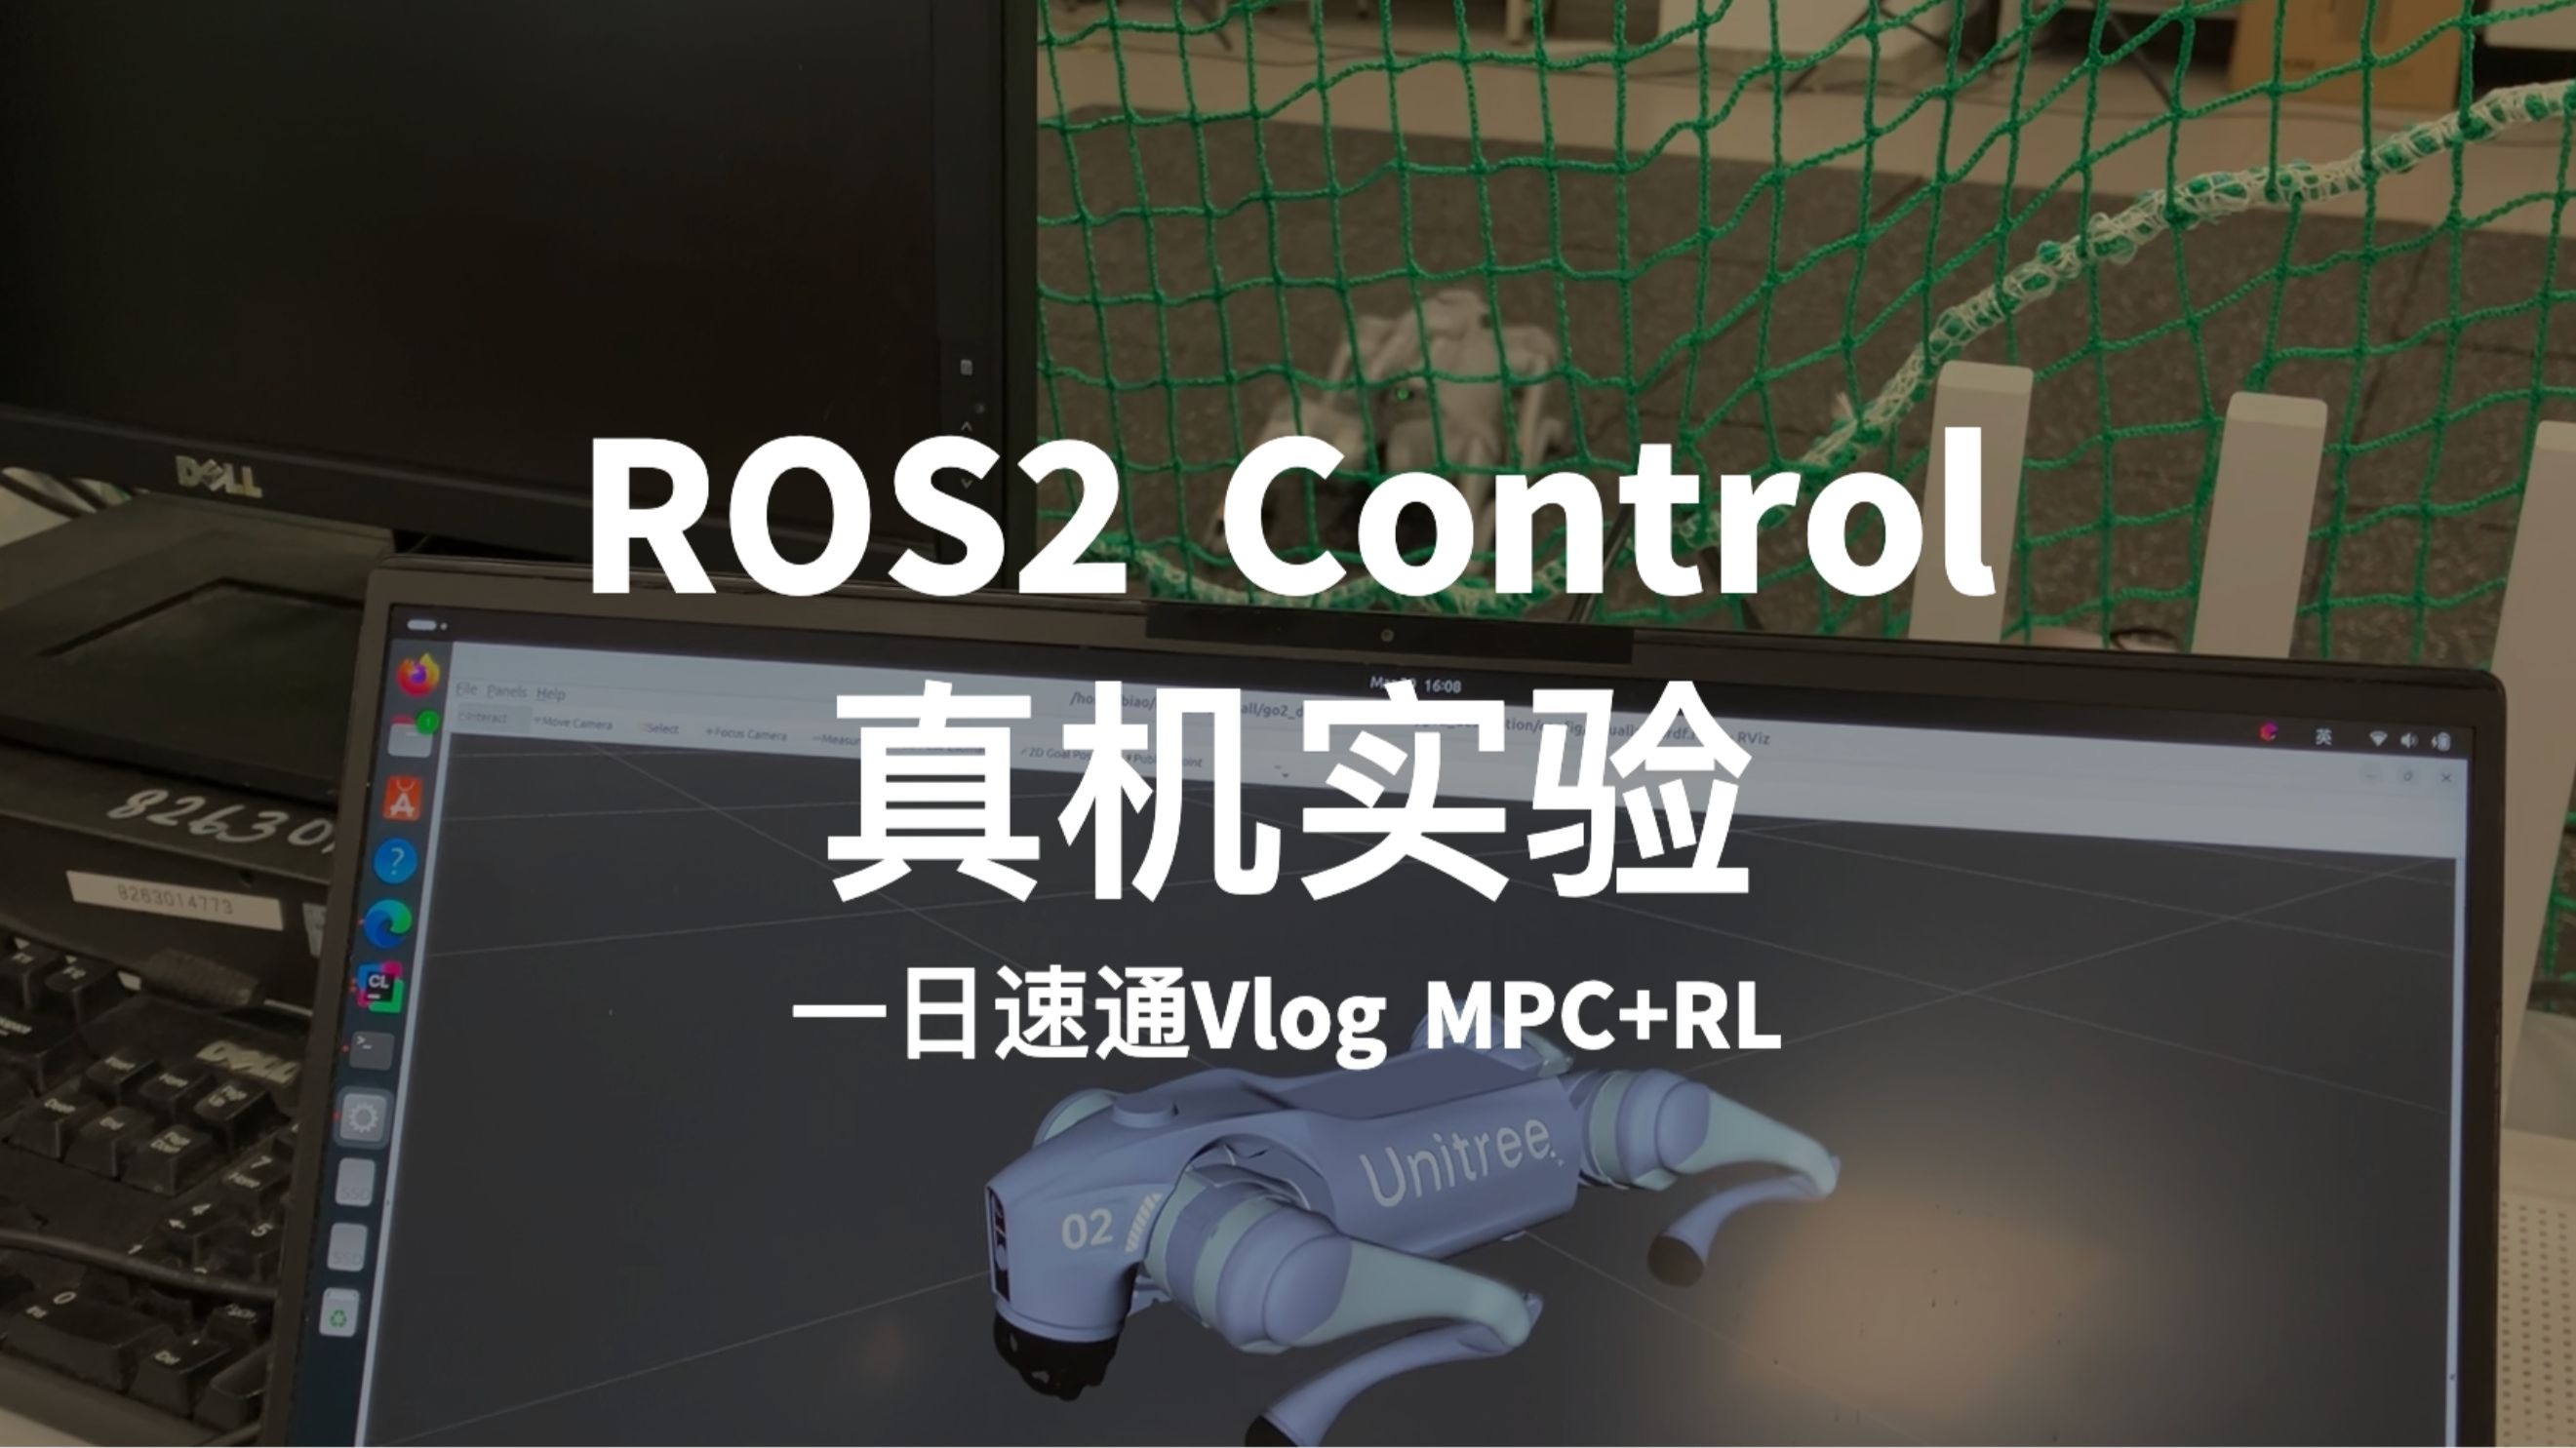
Video on Real Unitree Go2 Robot:
1. Quick Start

  • rosdep
    cd ~/ros2_ws
    rosdep install --from-paths src --ignore-src -r -y
    
  • Compile the package
    colcon build --packages-up-to unitree_guide_controller go2_description keyboard_input --symlink-install
    

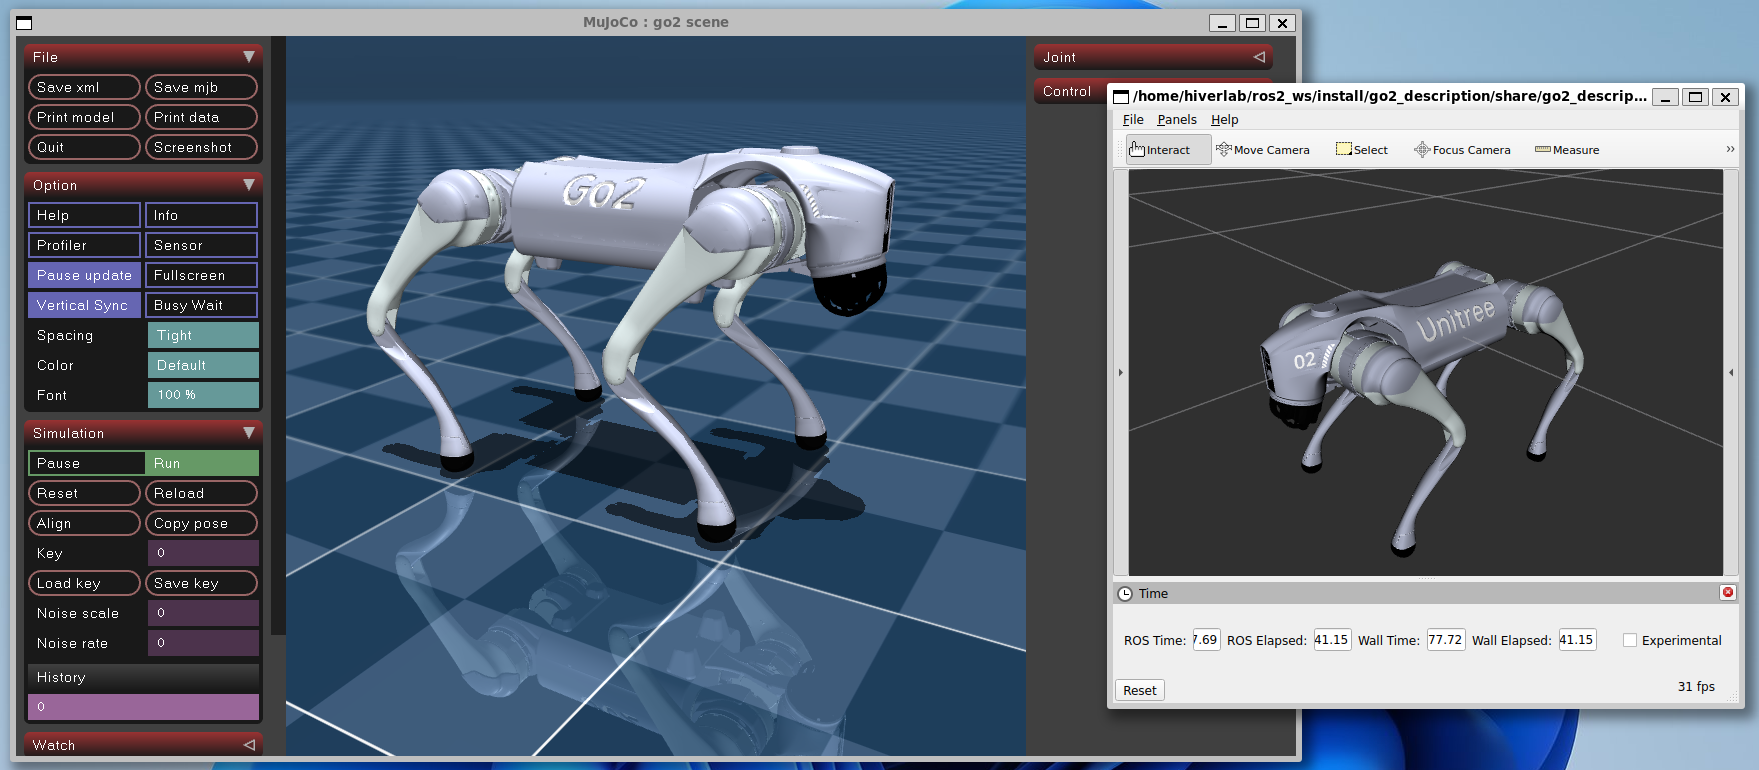
1.1 Mujoco Simulator or Real Unitree Robot

Warning: CycloneDDS ROS2 RMW may conflict with unitree_sdk2. If you cannot launch unitree mujoco simulation without sudo, then you cannot used unitree_mujoco_hardware. This conflict could be solved by one of below two methods:

  1. Uninstall CycloneDDS ROS2 RMW, used another ROS2 RMW, such as FastDDS [Recommended].
  2. Follow the guide in unitree_ros2 to configure the ROS2 RMW by compiling cyclone dds.
  • Compile Unitree Hardware Interfaces
    cd ~/ros2_ws
    colcon build --packages-up-to hardware_unitree_sdk2
    
  • Follow the guide in unitree_mujoco to launch the unitree mujoco go2 simulation
  • Launch the ros2-control
    source ~/ros2_ws/install/setup.bash
    ros2 launch unitree_guide_controller mujoco.launch.py
    
  • Run the keyboard control node
    source ~/ros2_ws/install/setup.bash
    ros2 run keyboard_input keyboard_input
    

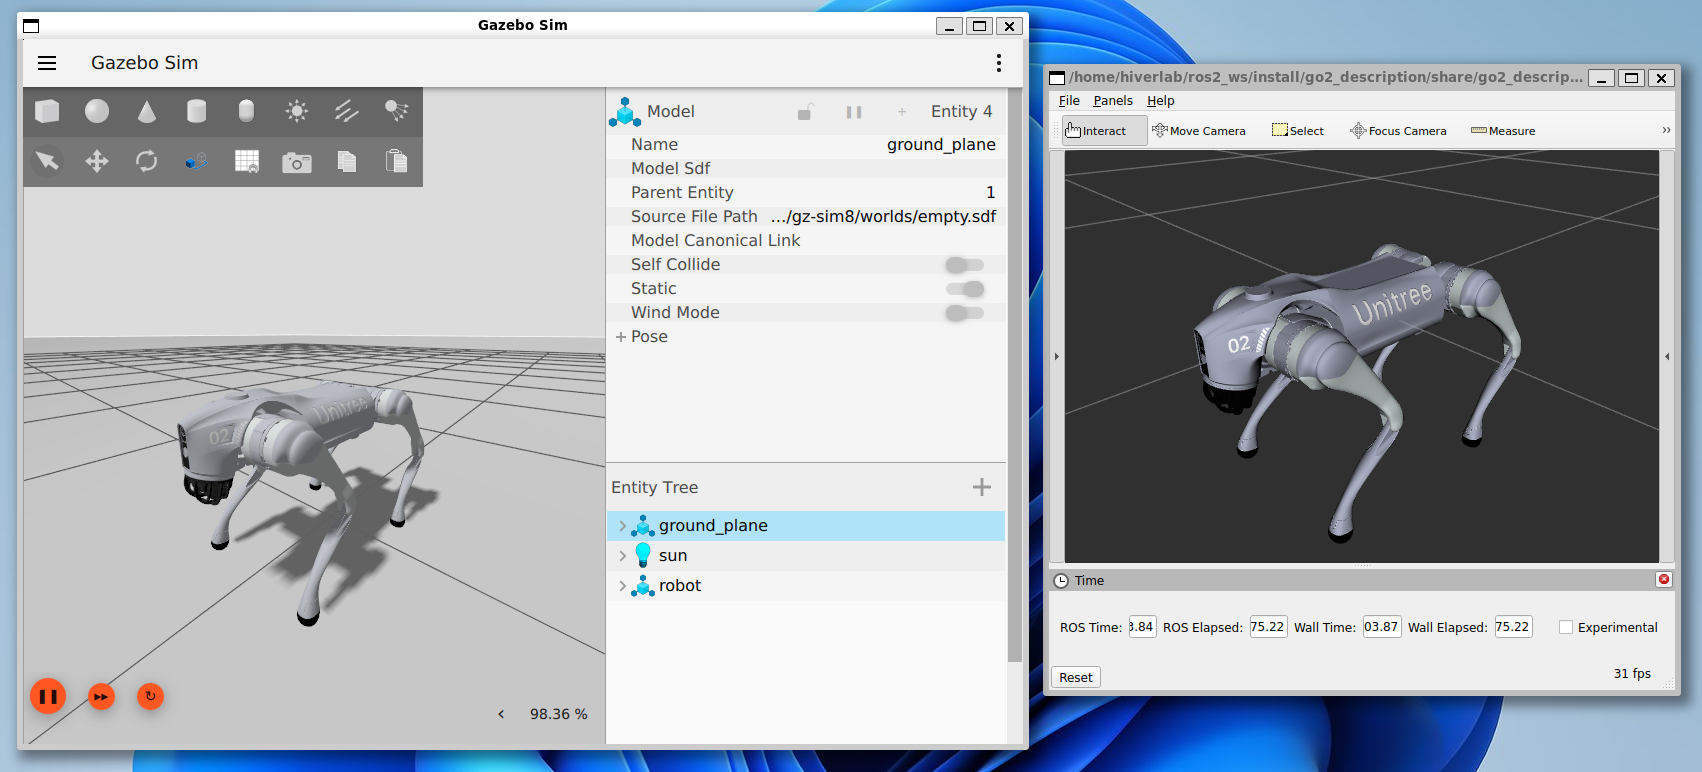
1.3 Gazebo Harmonic Simulator

  • Install Gazebo

    sudo apt-get install ros-jazzy-ros-gz
    
  • Compile Gazebo Playground

    colcon build --packages-up-to gz_quadruped_playground --symlink-install
    
  • Launch the ros2-control

    source ~/ros2_ws/install/setup.bash
    ros2 launch unitree_guide_controller gazebo.launch.py
    
  • Run the keyboard control node

    source ~/ros2_ws/install/setup.bash
    ros2 run keyboard_input keyboard_input
    

For more details, please refer to the unitree guide controller and go2 description.

What's Next

Congratulations! You have successfully launched the quadruped robot in the simulation. Here are some suggestions for you to have a try:

Reference

Conference Paper

[1] Liao, Qiayuan, et al. "Walking in narrow spaces: Safety-critical locomotion control for quadrupedal robots with duality-based optimization." In 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 2723-2730. IEEE, 2023.

Miscellaneous

[1] Unitree Robotics. unitree_guide: An open source project for controlling the quadruped robot of Unitree Robotics, and it is also the software project accompanying 《四足机器人控制算法--建模、控制与实践》 published by Unitree Robotics. [Online]. Available: https://github.com/unitreerobotics/unitree_guide

[2] Qiayuan Liao. legged_control: An open-source NMPC, WBC, state estimation, and sim2real framework for legged robots. [Online]. Available: https://github.com/qiayuanl/legged_control

[3] Ziqi Fan. rl_sar: Simulation Verification and Physical Deployment of Robot Reinforcement Learning Algorithm.

  1. Available: https://github.com/fan-ziqi/rl_sar
排名相邻
同类项目