BiomedGPT: A Generalist Vision-Language Foundation Model for Diverse Biomedical Tasks
关键参数与规格
关键参数与规格
参数
值
语言
Python
类别
Models
子类别
Vision models
关键词
3D
星标数
717
分叉数
98
贡献者
5
创建日期
2021-07-08
更新日期
2026-10-05
1 天星标数
0
7 天星标数
0
排名
14,612
上次排名
14,464
排名变化
-148
7 天星标排名
14,566
上次 7 天星标排名
14,571
7 天星标排名变化
5
总星标排名
14,610
上次总星标排名
14,581
总星标排名变化
-29
国家
USA
README 摘录
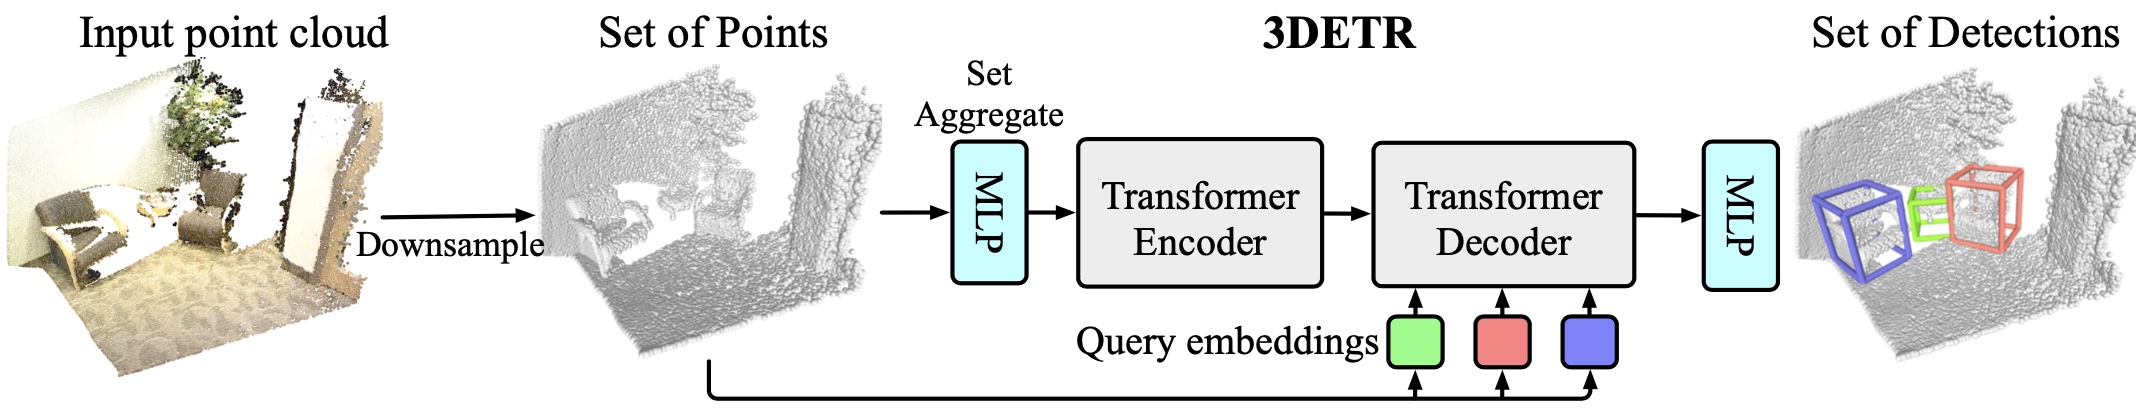
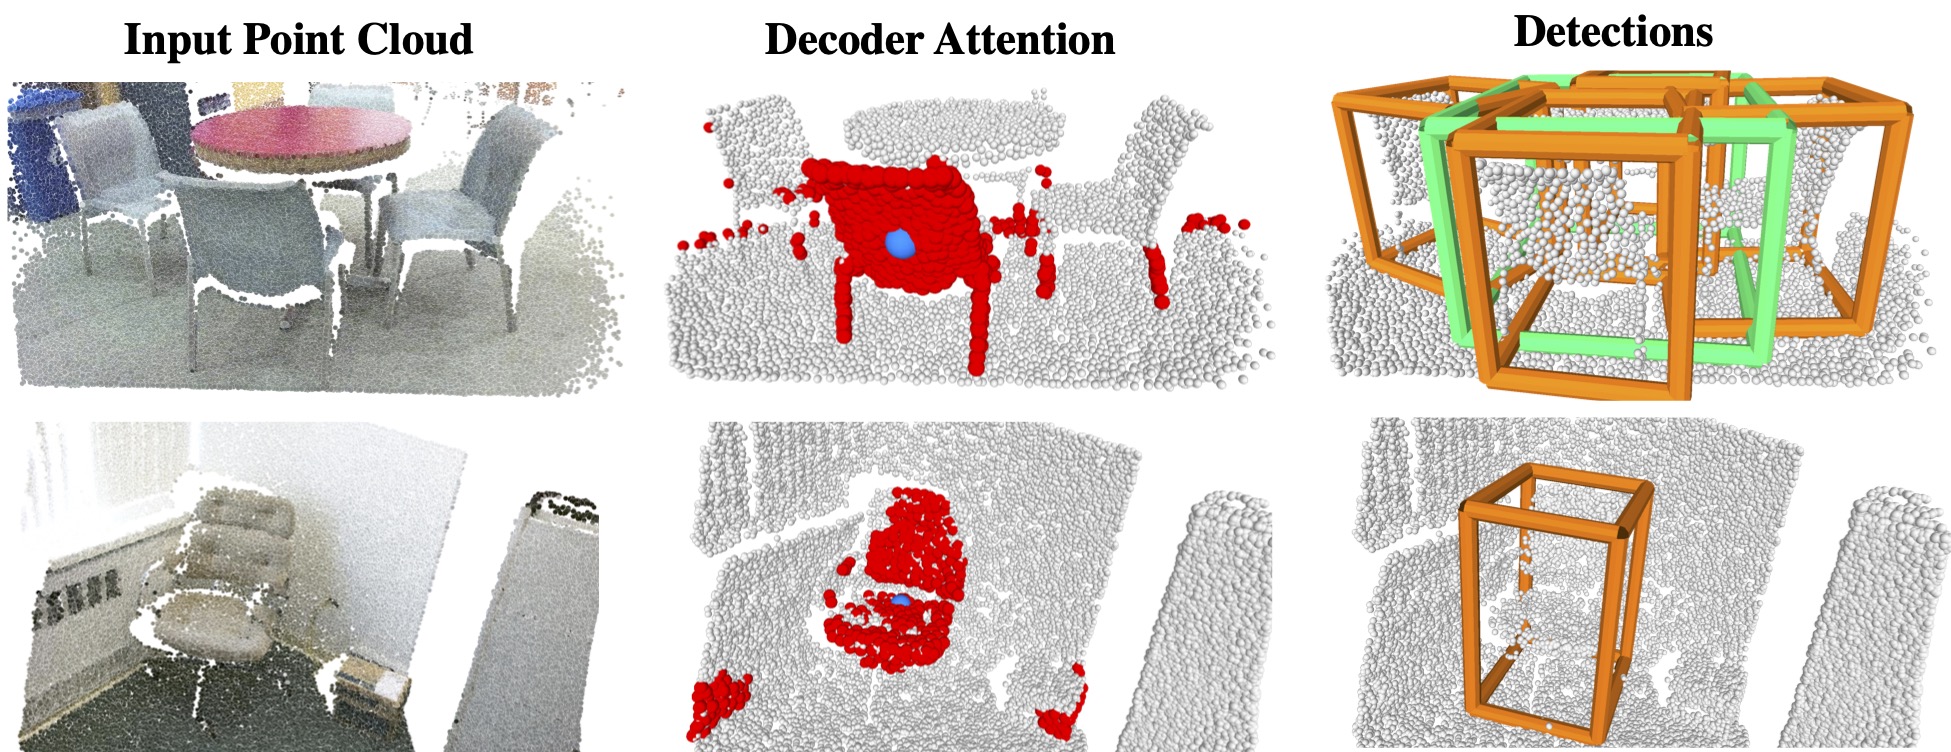
3DETR: An End-to-End Transformer Model for 3D Object Detection PyTorch implementation and models for **3DETR**. **3DETR** (**3D** **DE**tection **TR**ansformer) is a simpler alternative to complex hand-crafted 3D detection pipelines. It does not rely on 3D backbones such as PointNet++ and uses few 3D-specific operators. 3DETR obtains comparable or better performance than 3D detection methods such as VoteNet. The encoder can also be used for other 3D tasks such as shape classification. More details in
the paper "An End-to-End Transformer Model for 3D Object Detection". ** Our code is based on prior work such as DETR and VoteNet and we aim for simplicity in our implementation. We hope it can ease research in 3D detection. Pretrained Models We provide the pretrained model weights and the corresponding metrics on the val set (per class APs, Recalls). We provide a Python script to easily download the weights/metrics files. Arch Dataset Epochs AP25 AP50 Model weights
Eval metrics 3DETR-m SUN RGB-D 1080 59. 3 weights metrics 3DETR SUN RGB-D 1080 58. 3 weights metrics 3DETR-m ScanNet 1080 65. 0 weights metrics 3DETR ScanNet 1080 62. 9 weights metrics Model Zoo For convenience, we provide model weights for 3DETR trained for different number of epochs. Arch Dataset Epochs AP25 AP50 Model weights Eval metrics 3DETR-m SUN RGB-D 90 51. 0 weights metrics 3DETR-m SUN RGB-D 180 55. 5 weights
metrics 3DETR-m ScanNet 720 63. 2 weights metrics Running 3DETR Installation Our code is tested with PyTorch 1. You will need to install layers by running You will also need Python dependencies (either or ) Some users have experienced issues using CUDA 11 or higher. **Optionally**, you can install a Cythonized implementation of gIOU for faster training. Benchmarking Dataset preparation We follow the VoteNet codebase for preprocessing our data. The instructions for preprocessing SUN RGB-D are here and ScanNet
are here. You can edit the dataset paths in and or choose to specify at runtime. Testing Once you have the datasets prepared, you can test pretrained models as We use 128 queries for the SUN RGB-D dataset and 256 queries for the ScanNet dataset. You will need to add the flag when testing the 3DETR-m checkpoints. Please note that the testing process is stochastic (due to randomness in point cloud sampling and sampling the queries) and so
results can vary within 1% AP25 across runs. This stochastic nature of the inference process is also common for methods
3DETR: An End-to-End Transformer Model for 3D Object Detection
PyTorch implementation and models for 3DETR.
3DETR (3DDEtection TRansformer) is a simpler alternative to complex hand-crafted 3D detection pipelines.
It does not rely on 3D backbones such as PointNet++ and uses few 3D-specific operators.
3DETR obtains comparable or better performance than 3D detection methods such as VoteNet.
The encoder can also be used for other 3D tasks such as shape classification.
More details in the paper "An End-to-End Transformer Model for 3D Object Detection".
Code description. Our code is based on prior work such as DETR and VoteNet and we aim for simplicity in our implementation. We hope it can ease research in 3D detection.
Pretrained Models
We provide the pretrained model weights and the corresponding metrics on the val set (per class APs, Recalls).
We provide a Python script utils/download_weights.py to easily download the weights/metrics files.
We use 128 queries for the SUN RGB-D dataset and 256 queries for the ScanNet dataset.
You will need to add the flag --enc_type masked when testing the 3DETR-m checkpoints.
Please note that the testing process is stochastic (due to randomness in point cloud sampling and sampling the queries) and so results can vary within 1% AP25 across runs.
This stochastic nature of the inference process is also common for methods such as VoteNet.
If you have not edited the dataset paths for the files in the datasets folder, you can pass the path to the datasets using the --dataset_root_dir flag.
Training
The model can be simply trained by running main.py.
python main.py --dataset_name --checkpoint_dir
To reproduce the results in the paper, we provide the arguments in the scripts folder.
A variance of 1% AP25 across different training runs can be expected.
You can quickly verify your installation by training a 3DETR model for 90 epochs on ScanNet following the file scripts/scannet_quick.sh and compare it to the pretrained checkpoint from the Model Zoo.
If you find this repository useful, please consider starring :star: us and citing
@inproceedings{misra2021-3detr,
    title={{An End-to-End Transformer Model for 3D Object Detection}},
    author={Misra, Ishan and Girdhar, Rohit and Joulin, Armand},
    booktitle={{ICCV}},
    year={2021},
}