gym-carla
An OpenAI gym third party environment for CARLA simulator.
System Requirements
- Ubuntu 16.04
Installation
- Setup conda environment
$ conda create -n env_name python=3.6
$ conda activate env_name
- Clone this git repo in an appropriate folder
$ git clone https://github.com/cjy1992/gym-carla.git
- Enter the repo root folder and install the packages:
$ pip install -r requirements.txt
$ pip install -e .
- Download CARLA_0.9.6, extract it to some folder, and add CARLA to
PYTHONPATHenvironment variable:
$ export PYTHONPATH=$PYTHONPATH:$YourFolder$/CARLA_0.9.6/PythonAPI/carla/dist/carla-0.9.6-py3.5-linux-x86_64.egg
Usage
- Enter the CARLA root folder and launch the CARLA server by:
$ ./CarlaUE4.sh -windowed -carla-port=2000
You can use Alt+F1 to get back your mouse control.
Or you can run in non-display mode by:
$ DISPLAY= ./CarlaUE4.sh -opengl -carla-port=2000
- Run the test file:
$ python test.py
See details of test.py about how to use the CARLA gym wrapper.
Description
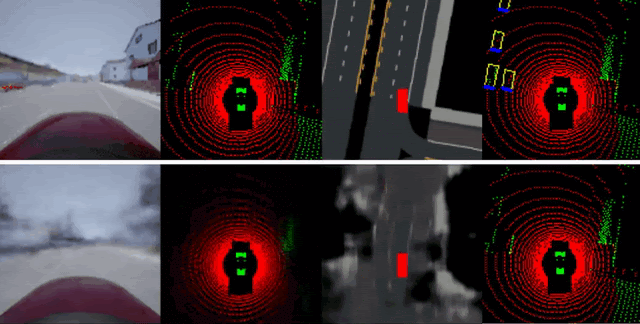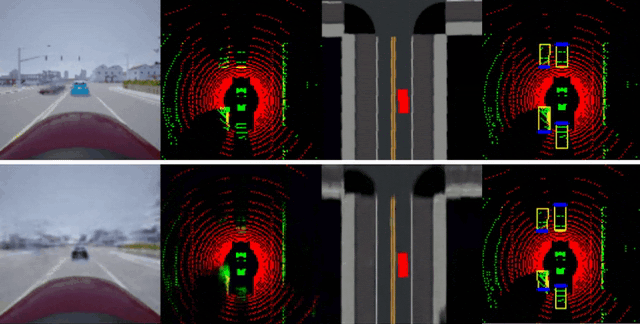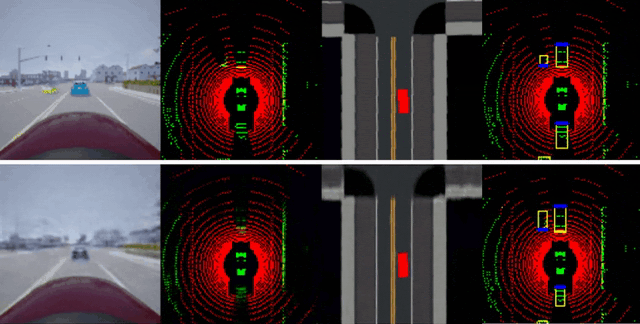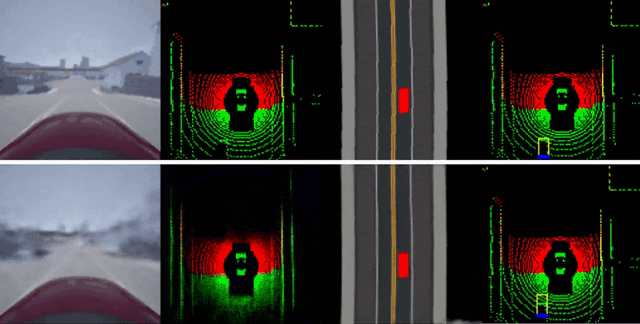
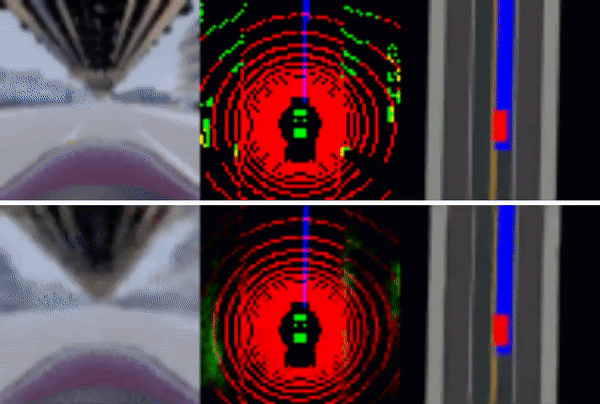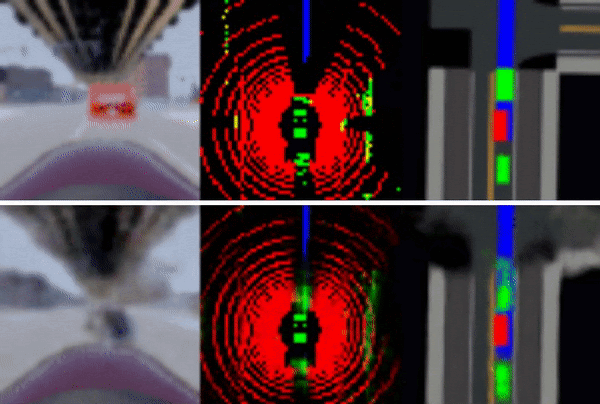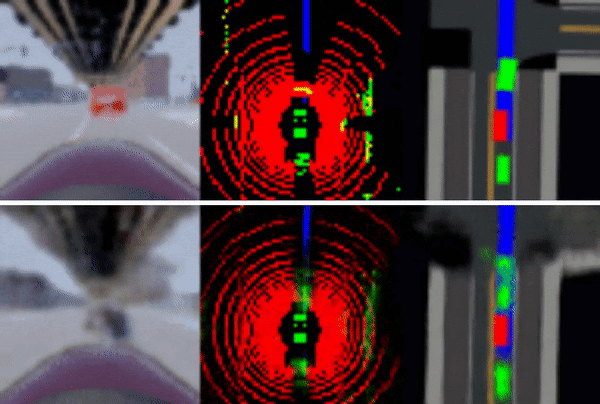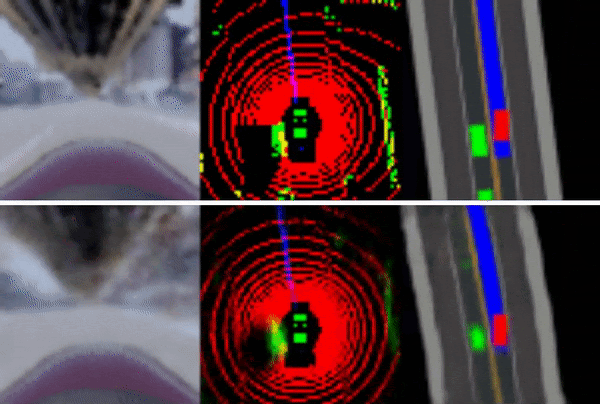
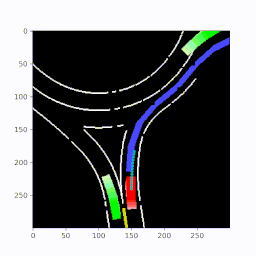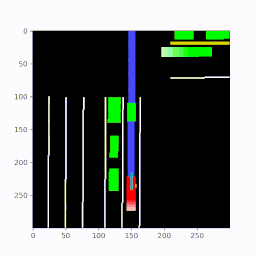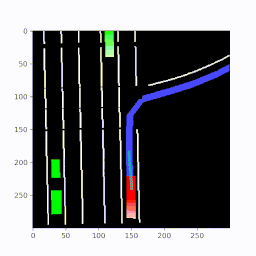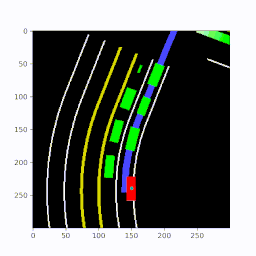
- We provide a dictionary observation including front view camera (obs['camera']), birdeye view lidar point cloud (obs['lidar']) and birdeye view semantic representation (obs['birdeye']):
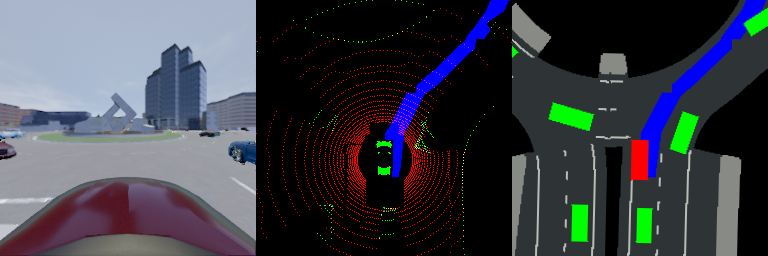
We also provide a state vector observation (obs['state']) which is composed of lateral distance and heading error between the ego vehicle to the target lane center line (in meter and rad), ego vehicle's speed (in meters per second), and and indicator of whether there is a front vehicle within a safety margin.
-
The termination condition is either the ego vehicle collides, runs out of lane, reaches a destination, or reaches the maximum episode timesteps. Users may modify function _terminal in carla_env.py to enable customized termination condition.
-
The reward is a weighted combination of longitudinal speed and penalties for collision, exceeding maximum speed, out of lane, large steering and large lateral accleration. Users may modify function _get_reward in carla_env.py to enable customized reward function.
Related Repos and Papers
Deep Reinforcement Learning for Autonomous Driving
-
See https://github.com/cjy1992/interp-e2e-driving, which provides implementations for the paper Interpretable End-to-end Urban Autonomous Driving with Latent Deep Reinforcement Learning and paper Model-free Deep Reinforcement Learning for Urban Autonomous Driving, as well as several deep RL baselines for autonomous driving on CARLA.
Deep Imitation Learning for Autonomous Driving
-
See paper Deep Imitation Learning for Autonomous Driving in Generic Urban Scenarios with Enhanced Safety.

Autonomous Driving Perception and Representation Learning
-
See https://github.com/cjy1992/detect-loc-map, which provides implementations for the paper End-to-end Autonomous Driving Perception with Sequential Latent Representation Learning.