← 开源
andybarry

flight

Flight code for MIT CSAIL Robot Locomotion Group flying-through-forests project

AI EngineeringMake agent see hear talkC
在 GitHub 打开
增长势头
+024 小时新增 Star0.0%
990
Star
264
Fork
+0
本周
1
贡献者
创建于 2014-02-07 · 更新于 2026-10-03 · 今日第 12202 名
主要开发者

andybarry/flight 排名第 12,202,有 990 个星标。

同类别比较

andybarry/flight 排名第 12,202,此处有 8 个同类条目;lmgame-org/GamingAgent 排名第 12,204。

同类别比较
名称排名指标
cookjohn/cnki-skills12,173
语言:
Python
星标数:
994
分叉数:
83
VILA-Lab/ATLAS12,183
语言:
Python
星标数:
992
分叉数:
106
简介:
A principled instruction benchmark on formulating effective queries and prompts for large language models (LLMs). Our paper: https://arxiv.org/abs/2312.16171
pollockjj/ComfyUI-MultiGPU12,187
语言:
Python
星标数:
992
分叉数:
89
简介:
This custom_node for ComfyUI adds one-click "Virtual VRAM" for any UNet and CLIP loader as well MultiGPU integration in WanVideoWrapper, managing the offload/Block Swap of layers to DRAM *or* VRAM to maximize the latent space of your card. Also includes nodes for directly loading entire components (UNet, CLIP, VAE) onto the device you choose
xiaotianfotos/homerail12,188
语言:
TypeScript
星标数:
992
分叉数:
224
简介:
Voice-first local agent orchestration runtime for auditable DAG workflows.
lmgame-org/GamingAgent12,204
语言:
Python
星标数:
990
分叉数:
107
简介:
[ICLR 2026] LLM/VLM gaming agents and model evaluation through games.
Alibaba-NLP/VRAG12,209
语言:
Python
星标数:
989
分叉数:
95
简介:
Multimodal Retrieval-augmented Generation Framework Built by Tongyi Lab, Alibaba Group.
neo4j-contrib/mcp-neo4j12,216
语言:
Python
星标数:
988
分叉数:
263
简介:
Neo4j Labs Model Context Protocol servers
githubnext/agentics12,218
语言:
Makefile
星标数:
987
分叉数:
146
简介:
A sample pack of GitHub Agentic Workflows!
关键参数与规格
关键参数与规格
参数值
语言C
类别AI Engineering
子类别Make agent see hear talk
关键词Autonomous vehicles, Computer vision, Object detection, Robotics
星标数990
分叉数264
贡献者1
创建日期2014-02-07
更新日期2026-10-03
1 天星标数0
7 天星标数0
排名12,202
上次排名12,130
排名变化-72
7 天星标排名13,313
上次 7 天星标排名13,324
7 天星标排名变化11
总星标排名11,238
上次总星标排名11,218
总星标排名变化-20
README 摘录

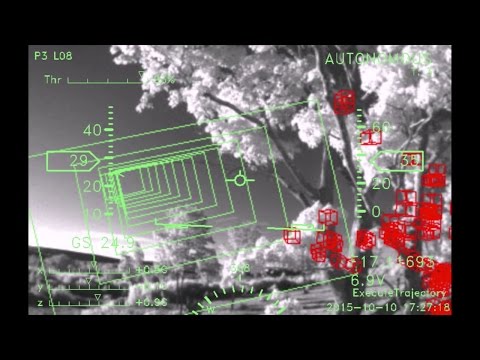
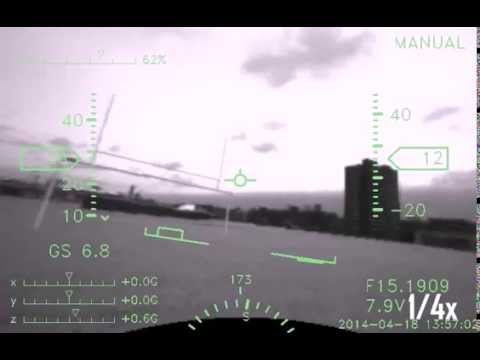
flight ====== Flight code for MIT CSAIL Robot Locomotion Group flying-through-forests project This code powers: Self-flying drone dips, darts and dives through trees at 30 mph video thesis (pdf) techincal video *FPGA vs. pushbroom stereo vision for MAVs*: paper (pdf) *Pushbroom stereo for high-speed navigation in cluttered environments*: paper (pdf) video *Fast and Accurate Knife-Edge Maneuvers for Autonomous Aircraft*: video abstract (pdf) thesis (pdf) Pushbroom stereo files are here: Main class [cpp] Camera capture, recording management
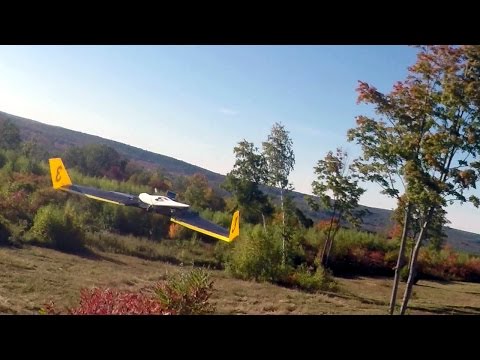
, debugging UI, etc. [cpp] Stereo image and synced sensor data: Datasets See also: Full parts list (PDF) Drake toolbox for planning, control, and analysis Simulation code CAD Pronto state estimator Contact / abarry.

常见问题

记录了多少星标和分叉?

andybarry/flight 有 990 个星标和 264 个分叉。

仓库排名是多少?

andybarry/flight 排名第 12,202。

记录的语言和类别是什么?

andybarry/flight 有 990 个星标,语言为 C,类别为 AI Engineering。

哪个仓库排名最接近?

andybarry/flight 与 lmgame-org/GamingAgent 比较,后者排名第 12,204,有 990 个星标。

README

flight

Flight code for MIT CSAIL Robot Locomotion Group flying-through-forests project

This code powers:

Pushbroom stereo files are here:

Stereo image and synced sensor data:

See also:

Contact / abarry.org for more information.

排名相邻
同类项目