Implementation of ChatGPT RLHF (Reinforcement Learning with Human Feedback) on any generation model in huggingface's transformer (blommz-176B/bloom/gpt/bart/T5/MetaICL)
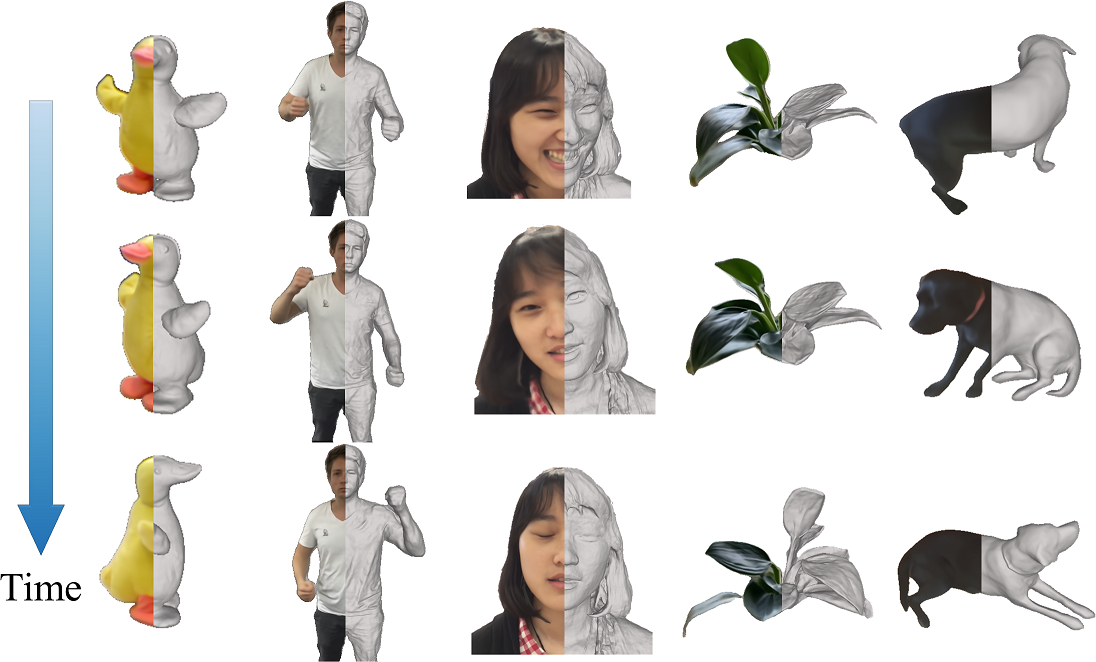
Neural Surface Reconstruction of Dynamic Scenes with Monocular RGB-D Camera NeurIPS 2022 (Spotlight) Paper | Project Page | OpenReview | Poster We propose Neural-DynamicReconstruction (NDR), a template-free method to recover high-fidelity geometry, motions and appearance of a dynamic scene from a monocular RGB-D camera. Usage Data Convention The data is organized as NeuS Here follows the data format in IDR, where denotes the world-to-image projection matrix, and denotes the normalization matrix. Pre-processed Data You can
download a part of pre-processed KillingFusion data here and unzip it into . Important Tips: If the pre-processed data is useful, please cite the related paper(s) and strictly abide by related open-source license(s). Setup Clone this repository and create the environment (please notice CUDA version) Dependencies (click to expand) torch==1. 2 Running **Training** **Evaluating pre-trained model** Data Pre-processing To prepare your own data for experiments, please refer to pose initialization. Geometric Projection **Compiling
renderer** **Rendering meshes** Input path of original data, path of results, and iteration number, e. Some code snippets are also borrowed from IDR and NeRF-pytorch. The pre-processing code for camera pose initialization is borrowed from Fast-Robust-ICP. The evaluation code for geometry rendering is borrowed from StereoPIFu_Code. We thank all the authors for their great work and repos. Contact If you have questions, please contact Hongrui Cai. Citation If you find our code or paper useful
, please cite If you find our pre-processed data useful, please cite the related paper(s) and strictly abide by related open-source license(s).
常见问题
记录了多少星标和分叉?
USTC3DV/NDR-code 有 564 个星标和 60 个分叉。
仓库排名是多少?
USTC3DV/NDR-code 排名第 16,940。
记录的语言和类别是什么?
USTC3DV/NDR-code 有 564 个星标,语言为 Python,类别为 Model Development。
We propose Neural-DynamicReconstruction (NDR), a template-free method to recover high-fidelity geometry, motions and appearance of a dynamic scene from a monocular RGB-D camera.
|-- cameras_sphere.npz    # camera parameters
|-- depth
    |-- # target depth for each view
    ...
|-- image
    |-- # target RGB each view
    ...
|-- mask
    |-- # target mask each view (For unmasked setting, set all pixels as 255)
    ...
Here cameras_sphere.npz follows the data format in IDR, where world_mat_xx denotes the world-to-image projection matrix, and scale_mat_xx denotes the normalization matrix.
Pre-processed Data
You can download a part of pre-processed KillingFusion data here and unzip it into ./.
Important Tips: If the pre-processed data is useful, please cite the related paper(s) and strictly abide by related open-source license(s).
Setup
Clone this repository and create the environment (please notice CUDA version)
This project is built upon NeuS. Some code snippets are also borrowed from IDR and NeRF-pytorch. The pre-processing code for camera pose initialization is borrowed from Fast-Robust-ICP. The evaluation code for geometry rendering is borrowed from StereoPIFu_Code. Thanks for these great projects. We thank all the authors for their great work and repos.
Contact
If you have questions, please contact Hongrui Cai.
Citation
If you find our code or paper useful, please cite
@inproceedings{Cai2022NDR,
  author    = {Hongrui Cai and Wanquan Feng and Xuetao Feng and Yan Wang and Juyong Zhang},
  title     = {Neural Surface Reconstruction of Dynamic Scenes with Monocular RGB-D Camera},
  booktitle = {Thirty-sixth Conference on Neural Information Processing Systems (NeurIPS)},
  year      = {2022}
}
If you find our pre-processed data useful, please cite the related paper(s) and strictly abide by related open-source license(s).