


CLRNet: Cross Layer Refinement Network for Lane Detection
Pytorch implementation of the paper "CLRNet: Cross Layer Refinement Network for Lane Detection" (CVPR2022 Acceptance).
Introduction
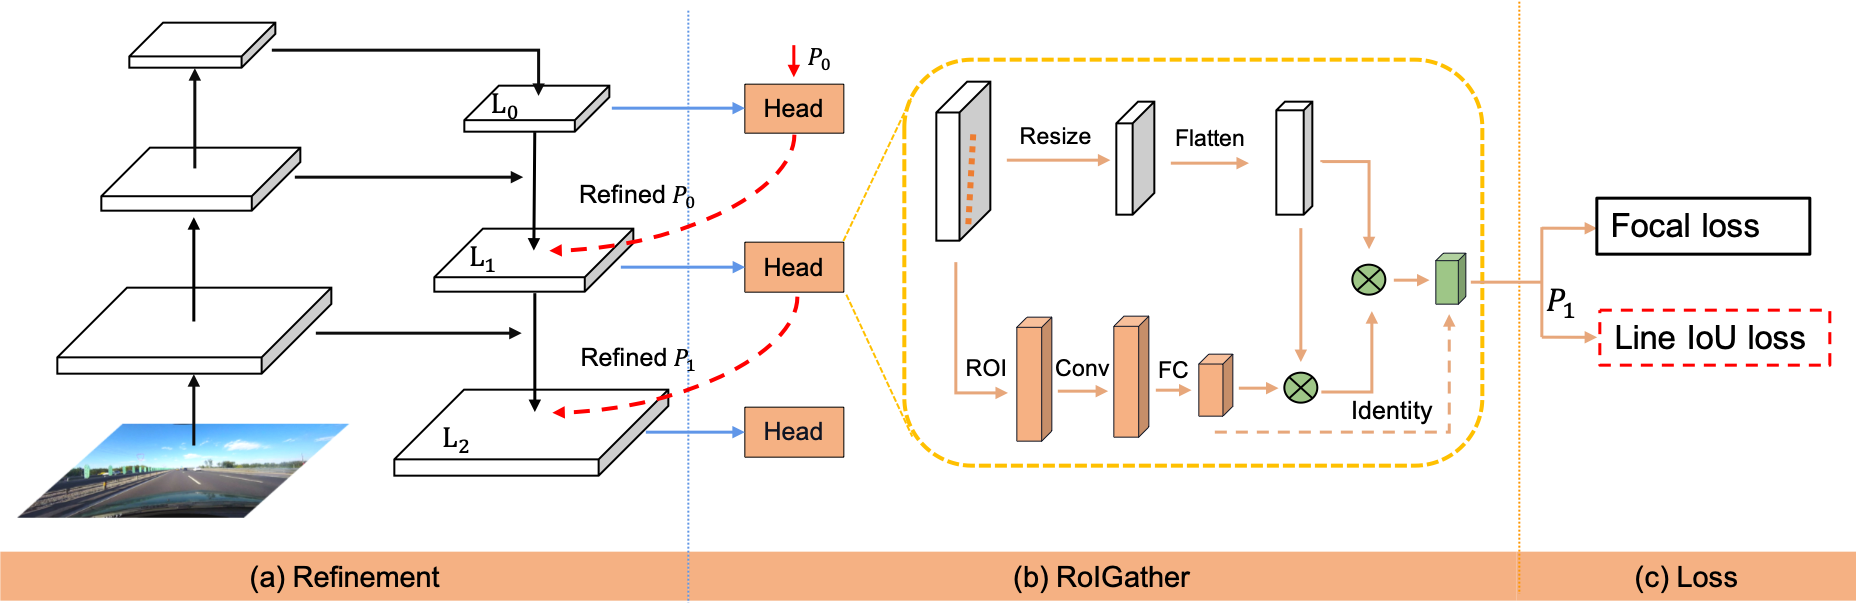
- CLRNet exploits more contextual information to detect lanes while leveraging local detailed lane features to improve localization accuracy.
- CLRNet achieves SOTA result on CULane, Tusimple, and LLAMAS datasets.
Installation
Prerequisites
Only test on Ubuntu18.04 and 20.04 with:
- Python >= 3.8 (tested with Python3.8)
- PyTorch >= 1.6 (tested with Pytorch1.6)
- CUDA (tested with cuda10.2)
- Other dependencies described in
requirements.txt
Clone this repository
Clone this code to your workspace.
We call this directory as $CLRNET_ROOT
git clone https://github.com/Turoad/clrnet
Create a conda virtual environment and activate it (conda is optional)
conda create -n clrnet python=3.8 -y
conda activate clrnet
Install dependencies
# Install pytorch firstly, the cudatoolkit version should be same in your system.

conda install pytorch torchvision cudatoolkit=10.1 -c pytorch

# Or you can install via pip
pip install torch==1.8.0 torchvision==0.9.0

# Install python packages
python setup.py build develop
Data preparation
CULane
Download CULane. Then extract them to $CULANEROOT. Create link to data directory.
cd $CLRNET_ROOT
mkdir -p data
ln -s $CULANEROOT data/CULane
For CULane, you should have structure like this:
$CULANEROOT/driver_xx_xxframe    # data folders x6
$CULANEROOT/laneseg_label_w16    # lane segmentation labels
$CULANEROOT/list                 # data lists
Tusimple
Download Tusimple. Then extract them to $TUSIMPLEROOT. Create link to data directory.
cd $CLRNET_ROOT
mkdir -p data
ln -s $TUSIMPLEROOT data/tusimple
For Tusimple, you should have structure like this:
$TUSIMPLEROOT/clips # data folders
$TUSIMPLEROOT/lable_data_xxxx.json # label json file x4
$TUSIMPLEROOT/test_tasks_0627.json # test tasks json file
$TUSIMPLEROOT/test_label.json # test label json file
For Tusimple, the segmentation annotation is not provided, hence we need to generate segmentation from the json annotation.
python tools/generate_seg_tusimple.py --root $TUSIMPLEROOT
# this will generate seg_label directory
LLAMAS
Dowload LLAMAS. Then extract them to $LLAMASROOT. Create link to data directory.
cd $CLRNET_ROOT
mkdir -p data
ln -s $LLAMASROOT data/llamas
Unzip both files (color_images.zip and labels.zip) into the same directory (e.g., data/llamas/), which will be the dataset's root. For LLAMAS, you should have structure like this:
$LLAMASROOT/color_images/train # data folders
$LLAMASROOT/color_images/test # data folders
$LLAMASROOT/color_images/valid # data folders
$LLAMASROOT/labels/train # labels folders
$LLAMASROOT/labels/valid # labels folders
Getting Started
Training
For training, run
python main.py [configs/path_to_your_config] --gpus [gpu_num]
For example, run
python main.py configs/clrnet/clr_resnet18_culane.py --gpus 0
Validation
For testing, run
python main.py [configs/path_to_your_config] --[test|validate] --load_from [path_to_your_model] --gpus [gpu_num]
For example, run
python main.py configs/clrnet/clr_dla34_culane.py --validate --load_from culane_dla34.pth --gpus 0
Currently, this code can output the visualization result when testing, just add --view.
We will get the visualization result in work_dirs/xxx/xxx/visualization.
Results
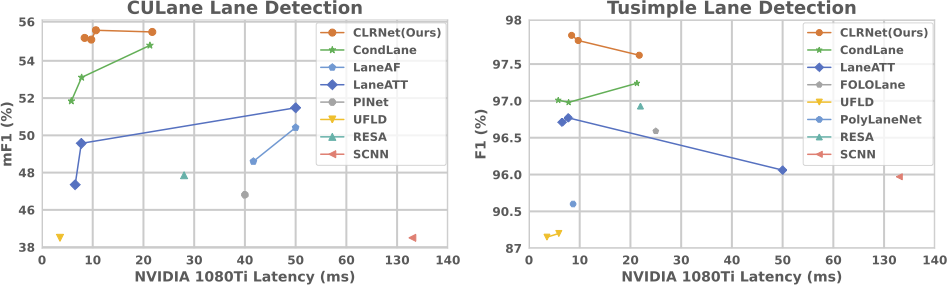
CULane
| Backbone | mF1 | F1@50 | F1@75 |
|---|---|---|---|
| ResNet-18 | 55.23 | 79.58 | 62.21 |
| ResNet-34 | 55.14 | 79.73 | 62.11 |
| ResNet-101 | 55.55 | 80.13 | 62.96 |
| DLA-34 | 55.64 | 80.47 | 62.78 |
TuSimple
| Backbone | F1 | Acc | FDR | FNR |
|---|---|---|---|---|
| ResNet-18 | 97.89 | 96.84 | 2.28 | 1.92 |
| ResNet-34 | 97.82 | 96.87 | 2.27 | 2.08 |
| ResNet-101 | 97.62 | 96.83 | 2.37 | 2.38 |
LLAMAS
| Backbone |
valid
mF1 F1@50 F1@75 |
test
F1@50 |
| :---: | :---: | :---:|
| ResNet-18 |
70.83 96.93 85.23 | 96.00 |
| DLA-34 |
71.57 97.06 85.43 | 96.12 |
“F1@50” refers to the official metric, i.e., F1 score when IoU threshold is 0.5 between the gt and prediction. "F1@75" is the F1 score when IoU threshold is 0.75.
Citation
If our paper and code are beneficial to your work, please consider citing:
@InProceedings{Zheng_2022_CVPR,
    author    = {Zheng, Tu and Huang, Yifei and Liu, Yang and Tang, Wenjian and Yang, Zheng and Cai, Deng and He, Xiaofei},
    title     = {CLRNet: Cross Layer Refinement Network for Lane Detection},
    booktitle = {Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
    month     = {June},
    year      = {2022},
    pages     = {898-907}
}