Rofunc: The Full Process Python Package for Robot Learning from Demonstration and Robot Manipulation

Repository address: https://github.com/Skylark0924/Rofunc
Documentation: https://rofunc.readthedocs.io/


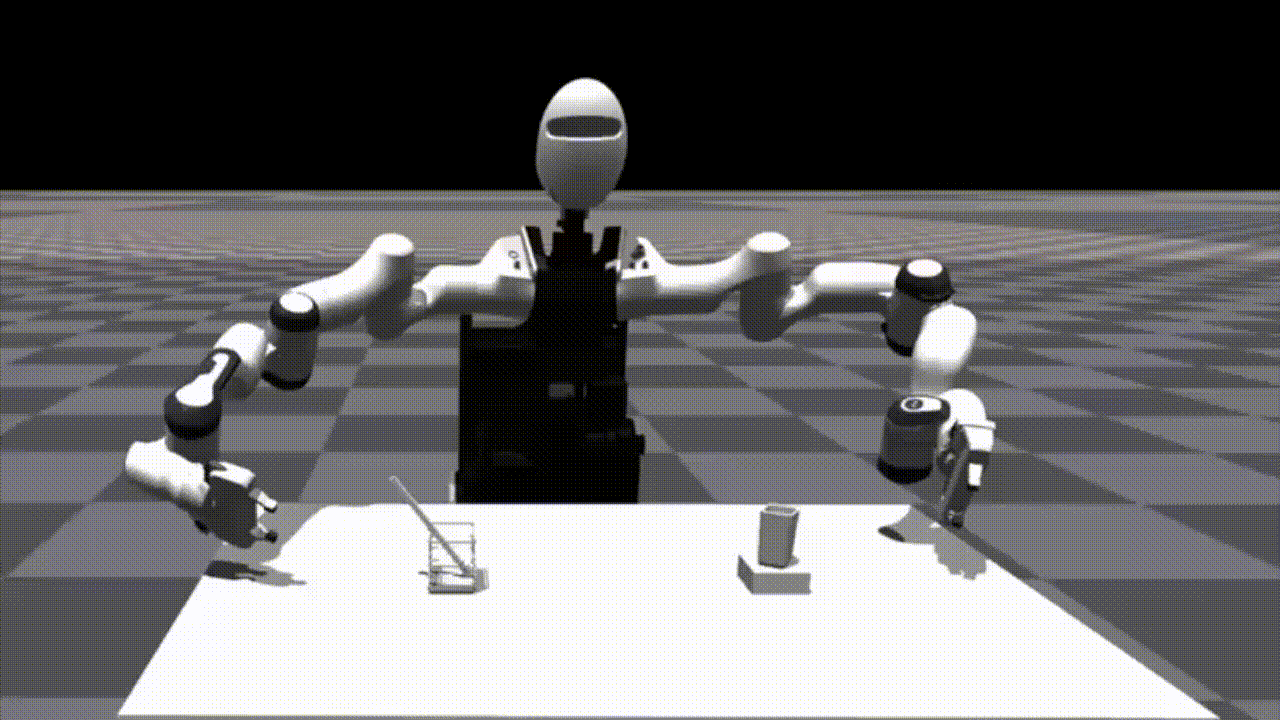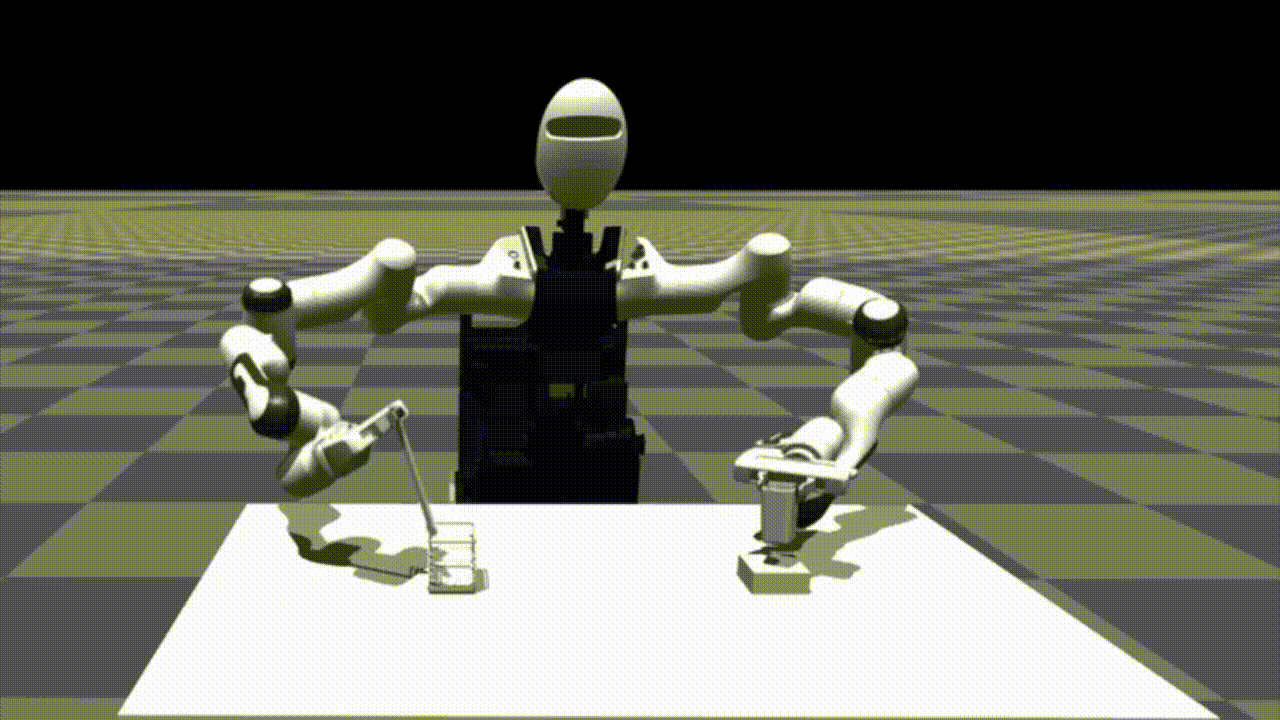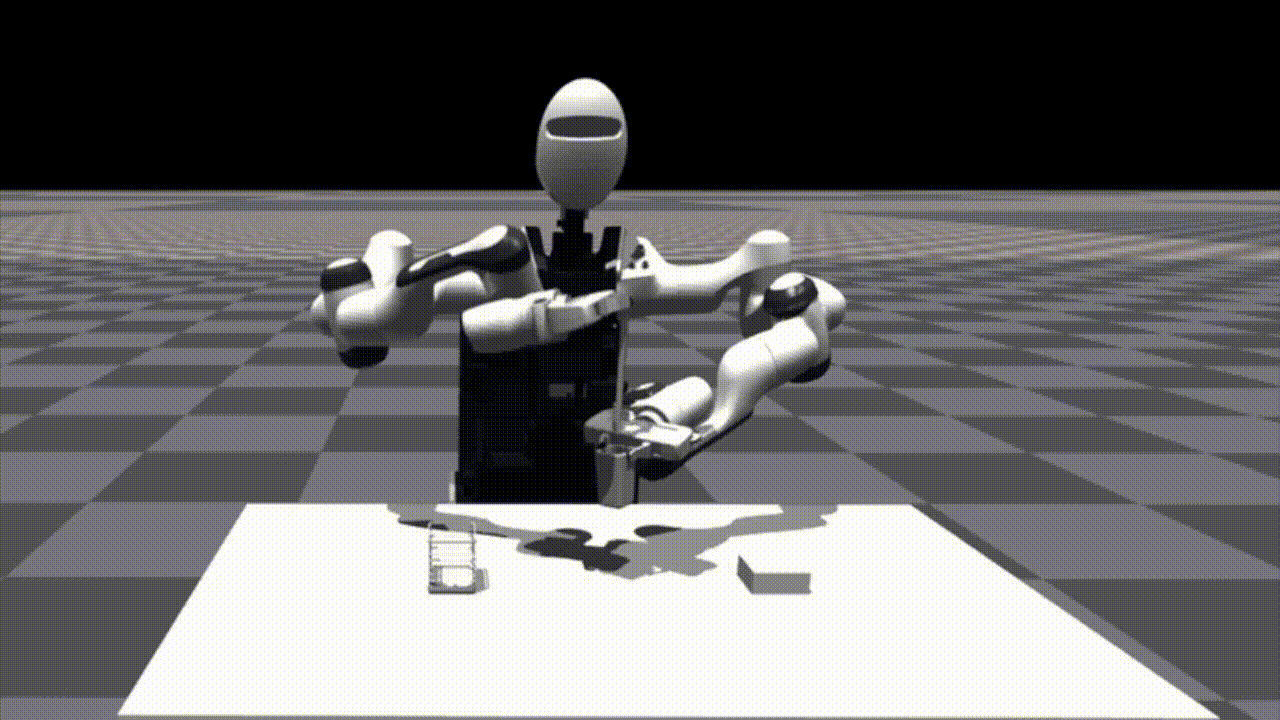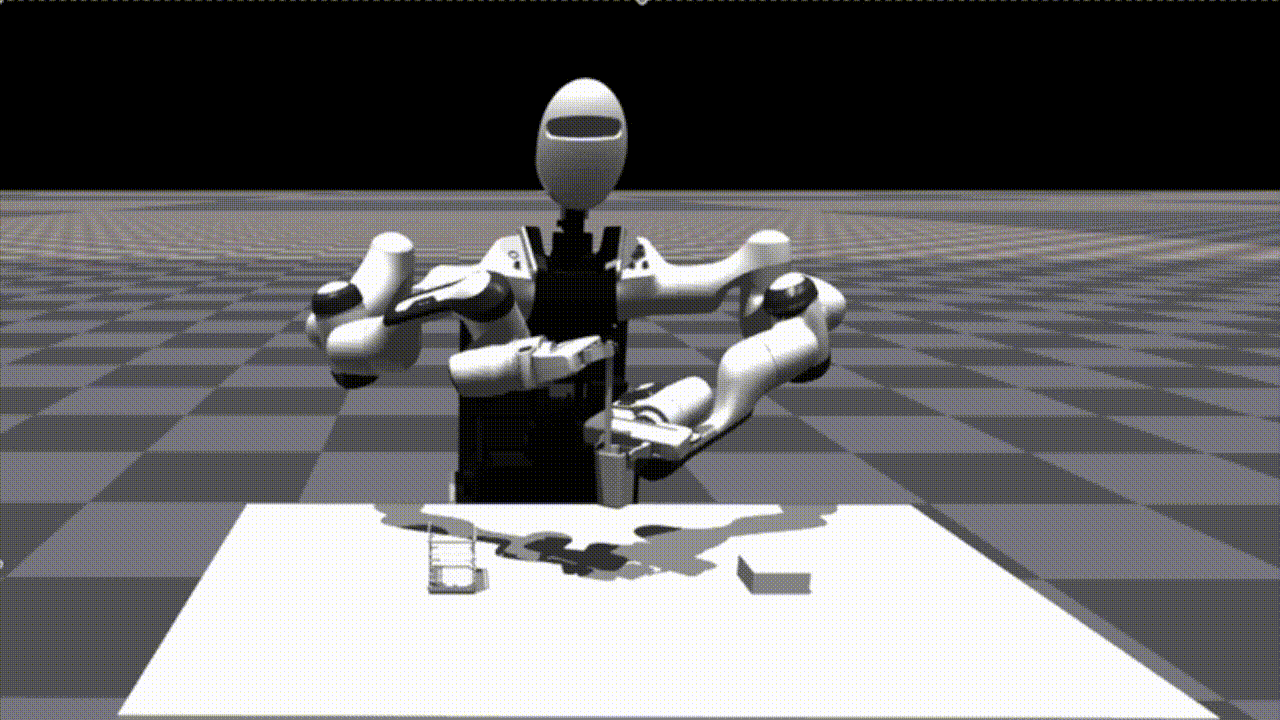

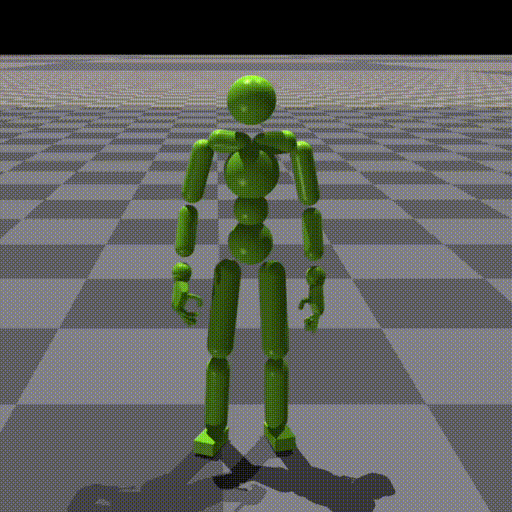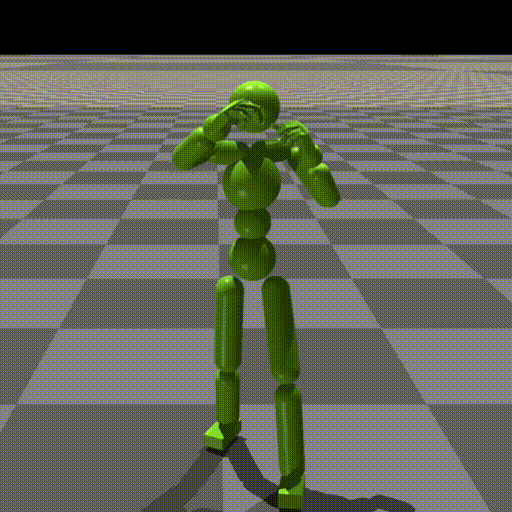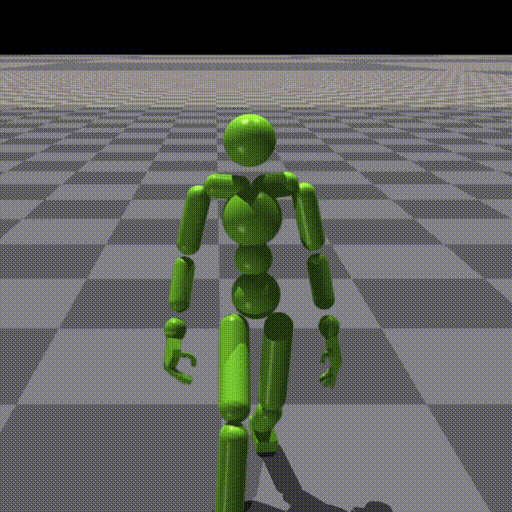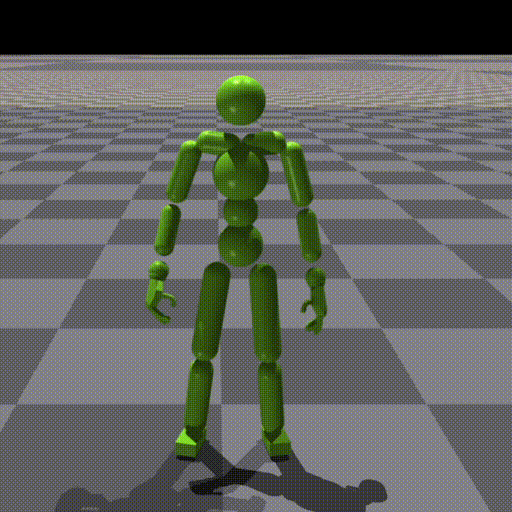
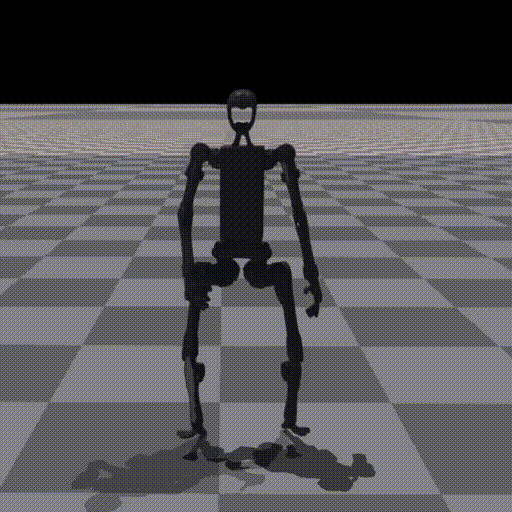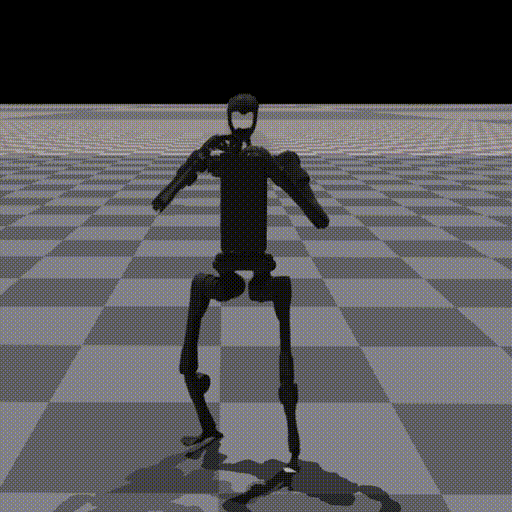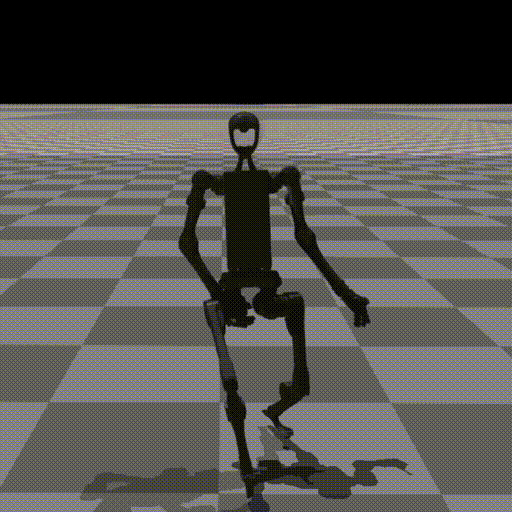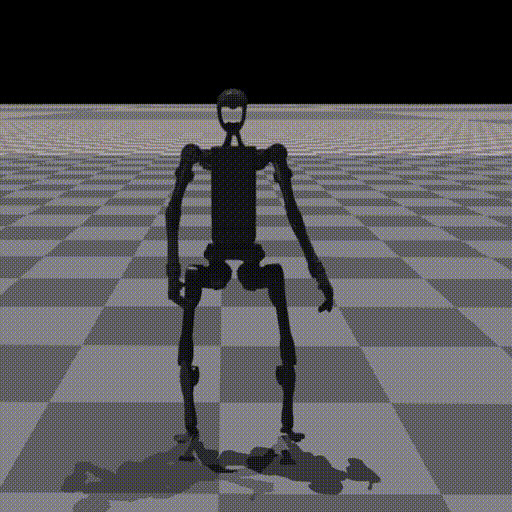


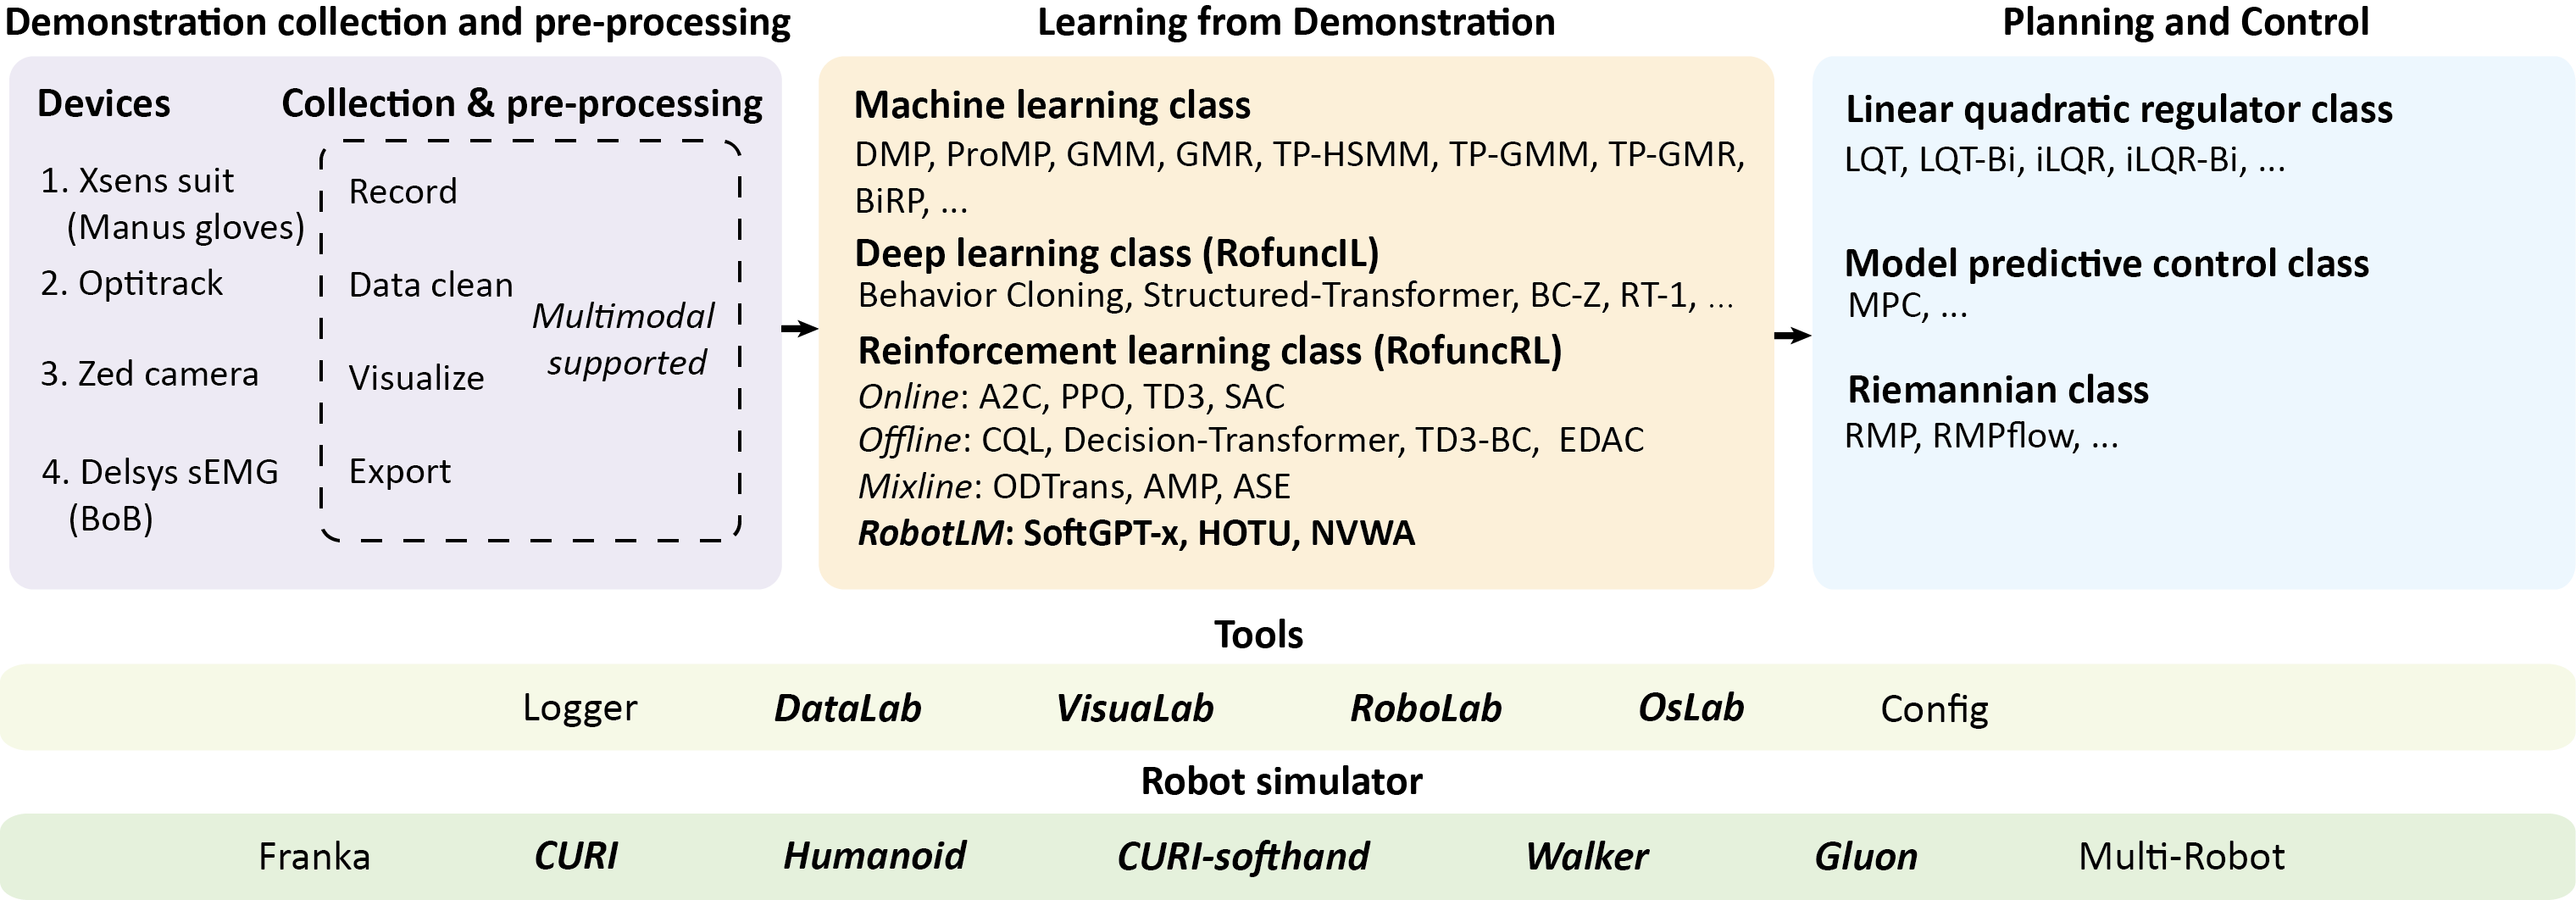
Rofunc package focuses on the Imitation Learning (IL), Reinforcement Learning (RL) and Learning from Demonstration (LfD) for (Humanoid) Robot Manipulation. It provides valuable and convenient python functions, including
demonstration collection, data pre-processing, LfD algorithms, planning, and control methods. We also provide an
IsaacGym and OmniIsaacGym based robot simulator for evaluation. This package aims to advance the field by building a full-process
toolkit and validation platform that simplifies and standardizes the process of demonstration data collection,
processing, learning, and its deployment on robots.
- Rofunc: The Full Process Python Package for Robot Learning from Demonstration and Robot Manipulation
Citation
If you use rofunc in a scientific publication, we would appreciate citations to the following paper:
@article{liu2023rofunc,
	title={Rofunc: The Full Process Python Package for Robot Learning from Demonstration and Robot Manipulation},
	author={Liu, Junjia and Dong, Zhipeng and Li, Chenzui and Li, Zhihao and Yu, Minghao and Delehelle, Donatien and Chen, Fei},
	year={2023},
	journal={Zenodo, https://github.com/Skylark0924/Rofunc},
	doi={10.5281/zenodo.10016946},
}
[!WARNING] If our code is found to be used in a published paper without proper citation, we reserve the right to address this issue formally by contacting the editor to report potential academic misconduct!
如果我们的代码被发现用于已发表的论文而没有被恰当引用,我们保留通过正式联系编辑报告潜在学术不端行为的权利。
Update News 🎉🎉🎉
- [2024-12-24] 🎮 Start trying to support Genesis simulator.
v0.0.2.6 Support dexterous grasping and human-humanoid robot skill transfer
- [2024-12-20] 🎉🚀 Human-level skill transfer from human to heterogeneous humanoid robots have been completed and are awaiting release. Preview
- [2024-01-24] 🚀 CURI Synergy-based Softhand grasping tasks are supported to be trained by
RofuncRL. - [2023-10-31] 🚀
RofuncRL: A modular easy-to-use Reinforcement Learning sub-package designed for Robot Learning tasks is released. It has been tested with simulators likeOpenAIGym,IsaacGym,OmniIsaacGym(see example gallery), and also differentiable simulators likePlasticineLabandDiffCloth. - ...
- If you want to know more about the update news, please refer to the changelog.
Installation
Please refer to the installation guide.
Documentation
To give you a quick overview of the pipeline of rofunc, we provide an interesting example of learning to play Taichi
from human demonstration. You can find it in the Quick start
section of the documentation.
The available functions and plans can be found as follows.
Note ✅: Achieved 🔃: Reformatting ⛔: TODO
RofuncRL
RofuncRL is one of the most important sub-packages of Rofunc. It is a modular easy-to-use Reinforcement Learning sub-package designed for Robot Learning tasks. It has been tested with simulators like OpenAIGym, IsaacGym, OmniIsaacGym (see example gallery), and also differentiable simulators like PlasticineLab and DiffCloth. Here is a list of robot tasks trained by RofuncRL:
Note
You can customize your own project based on RofuncRL by following the RofuncRL customize tutorial.
We also provide a RofuncRL-based repository template to generate your own repository following the RofuncRL structure by one click.
For more details, please check the documentation for RofuncRL.
The list of all supported tasks.
| Tasks | Animation | Performance | ModelZoo |
|---|---|---|---|
| Ant |  |
✅ | |
| Cartpole | |||
| Franka | |||
| Cabinet |  |
✅ | |
| Franka | |||
| CubeStack | |||
| CURI | |||
| Cabinet |  |
✅ | |
| CURI | |||
| CabinetImage | |
||
| CURI | |||
| CabinetBimanual | |||
| CURIQbSoftHand | |||
| SynergyGrasp |     |
✅ | |
| Humanoid |  |
✅ | |
| HumanoidAMP | |||
| Backflip | |
✅ | |
| HumanoidAMP | |||
| Walk | ✅ | ||
| HumanoidAMP | |||
| Run | |
✅ | |
| HumanoidAMP | |||
| Dance | |
✅ | |
| HumanoidAMP | |||
| Hop |  |
✅ | |
| HumanoidASE | |||
| GetupSwordShield |  |
✅ | |
| HumanoidASE | |||
| PerturbSwordShield |  |
✅ | |
| HumanoidASE | |||
| HeadingSwordShield | |
✅ | |
| HumanoidASE | |||
| LocationSwordShield | |
✅ | |
| HumanoidASE | |||
| ReachSwordShield | ✅ | ||
| HumanoidASE | |||
| StrikeSwordShield | |
✅ | |
| BiShadowHand | |||
| BlockStack |  |
✅ | |
| BiShadowHand | |||
| BottleCap |  |
✅ | |
| BiShadowHand | |||
| CatchAbreast |  |
✅ | |
| BiShadowHand | |||
| CatchOver2Underarm |  |
✅ | |
| BiShadowHand | |||
| CatchUnderarm |  |
✅ | |
| BiShadowHand | |||
| DoorOpenInward |  |
✅ | |
| BiShadowHand | |||
| DoorOpenOutward | |
✅ | |
| BiShadowHand | |||
| DoorCloseInward |  |
✅ | |
| BiShadowHand | |||
| DoorCloseOutward |  |
✅ | |
| BiShadowHand | |||
| GraspAndPlace |  |
✅ | |
| BiShadowHand | |||
| LiftUnderarm | |
✅ | |
| BiShadowHand | |||
| HandOver |  |
✅ | |
| BiShadowHand | |||
| Pen |  |
✅ | |
| BiShadowHand | |||
| PointCloud | |||
| BiShadowHand | |||
| PushBlock |  |
✅ | |
| BiShadowHand | |||
| ReOrientation |  |
✅ | |
| BiShadowHand | |||
| Scissors |  |
✅ | |
| BiShadowHand | |||
| SwingCup | |
✅ | |
| BiShadowHand | |||
| Switch |  |
✅ | |
| BiShadowHand | |||
| TwoCatchUnderarm |  |
✅ |
Star History
Related Papers
- Robot cooking with stir-fry: Bimanual non-prehensile manipulation of semi-fluid objects (IEEE RA-L 2022 | Code)
@article{liu2022robot,
         title={Robot cooking with stir-fry: Bimanual non-prehensile manipulation of semi-fluid objects},
         author={Liu, Junjia and Chen, Yiting and Dong, Zhipeng and Wang, Shixiong and Calinon, Sylvain and Li, Miao and Chen, Fei},
         journal={IEEE Robotics and Automation Letters},
         volume={7},
         number={2},
         pages={5159--5166},
         year={2022},
         publisher={IEEE}
}
- SoftGPT: Learn Goal-oriented Soft Object Manipulation Skills by Generative Pre-trained Heterogeneous Graph Transformer (IROS 2023)
@inproceedings{liu2023softgpt,
               title={Softgpt: Learn goal-oriented soft object manipulation skills by generative pre-trained heterogeneous graph transformer},
               author={Liu, Junjia and Li, Zhihao and Lin, Wanyu and Calinon, Sylvain and Tan, Kay Chen and Chen, Fei},
               booktitle={2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
               pages={4920--4925},
               year={2023},
               organization={IEEE}
}
- BiRP: Learning Robot Generalized Bimanual Coordination using Relative Parameterization Method on Human Demonstration (IEEE CDC 2023 | Code)
@inproceedings{liu2023birp,
               title={Birp: Learning robot generalized bimanual coordination using relative parameterization method on human demonstration},
               author={Liu, Junjia and Sim, Hengyi and Li, Chenzui and Tan, Kay Chen and Chen, Fei},
               booktitle={2023 62nd IEEE Conference on Decision and Control (CDC)},
               pages={8300--8305},
               year={2023},
               organization={IEEE}
}
- Human-Humanoid Robots’ Cross-Embodiment Behavior-Skill Transfer Using Decomposed Adversarial Learning From Demonstration (IEEE RAM 2025)
@article{liu2025human,
  title={Human--Humanoid Robots’ Cross-Embodiment Behavior-Skill Transfer Using Decomposed Adversarial Learning From Demonstration: HOTU, a Human--Humanoid Robots’ Skill Transfer Framework},
  author={Liu, Junjia and Li, Zhuo and Yu, Minghao and Dong, Zhipeng and Calinon, Sylvain and Caldwell, Darwin and Chen, Fei},
  journal={IEEE Robotics \& Automation Magazine},
  year={2025},
  publisher={IEEE}
}
The Team
Rofunc is developed and maintained by the CLOVER Lab (Collaborative and Versatile Robots Laboratory), CUHK.
Acknowledge
We would like to acknowledge the following projects: