🤖🖌️ Generate photo-realistic textures based on source images or (soon) PBR materials. Remix, remake, mashup! Useful if you want to create variations on a theme or elaborate on an existing texture.
Isaac ROS Nvblox Nvblox ROS 2 integration for local 3D scene reconstruction and mapping. Overview Isaac ROS Nvblox contains ROS 2 packages for 3D reconstruction and cost maps for navigation. processes depth and pose to reconstruct a 3D scene in real-time and outputs a 2D costmap for Nav2. The costmap is used in planning during navigation as a vision-based solution to avoid obstacles. is designed to work with depth-cameras and/or 3D LiDAR. The package uses GPU
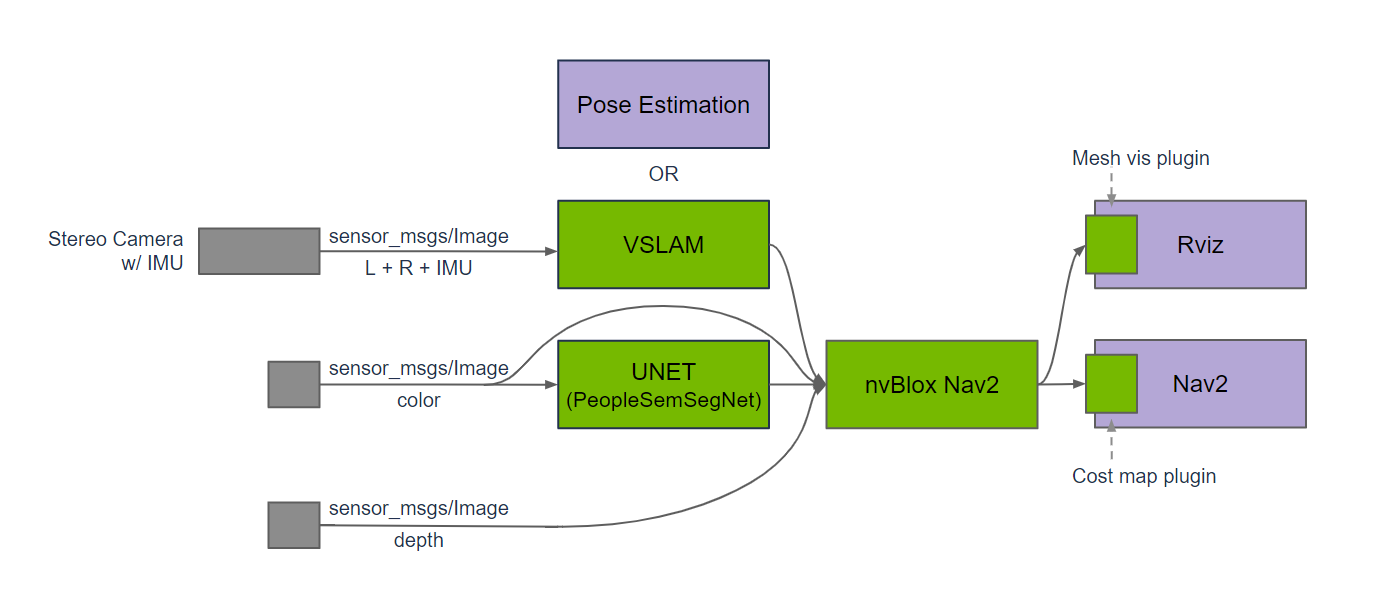
acceleration to compute a 3D reconstruction and 2D costmaps using nvblox, the underlying framework-independent C++ library. Nvblox takes a depth image, a color image, and a pose as input, with which it computes a 3D scene reconstruction on the GPU. In this graph the pose is computed using , or some other pose estimation node. The reconstruction is sliced into an output cost map which is provided through a cost map plugin into Nav2. An optional colorized 3D reconstruction is
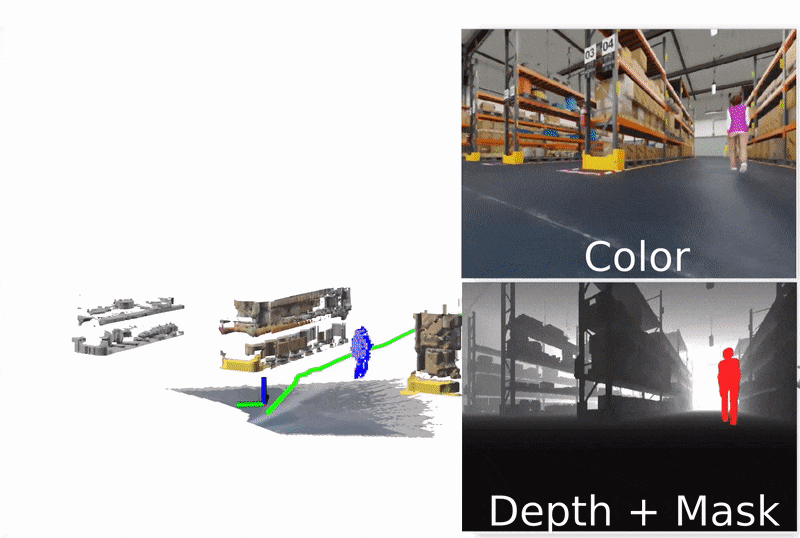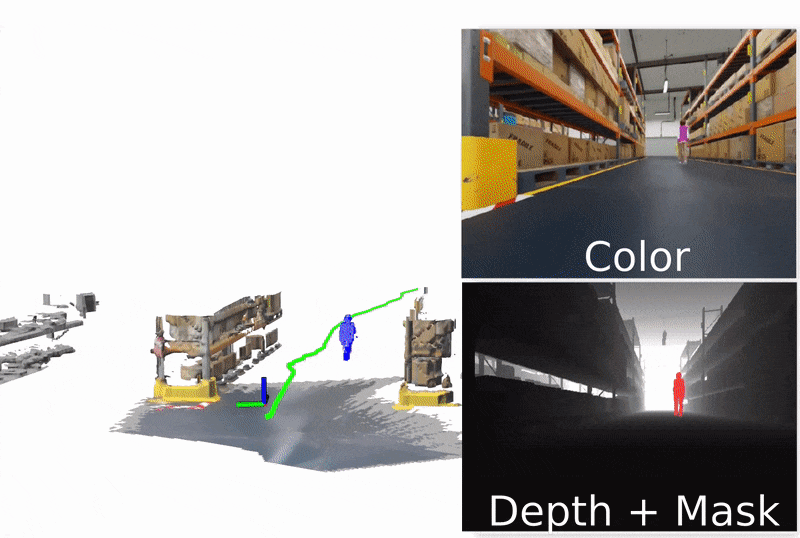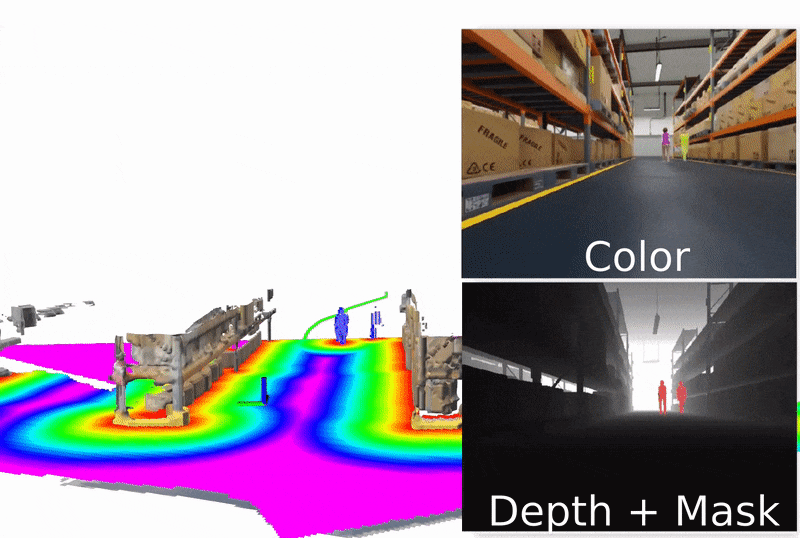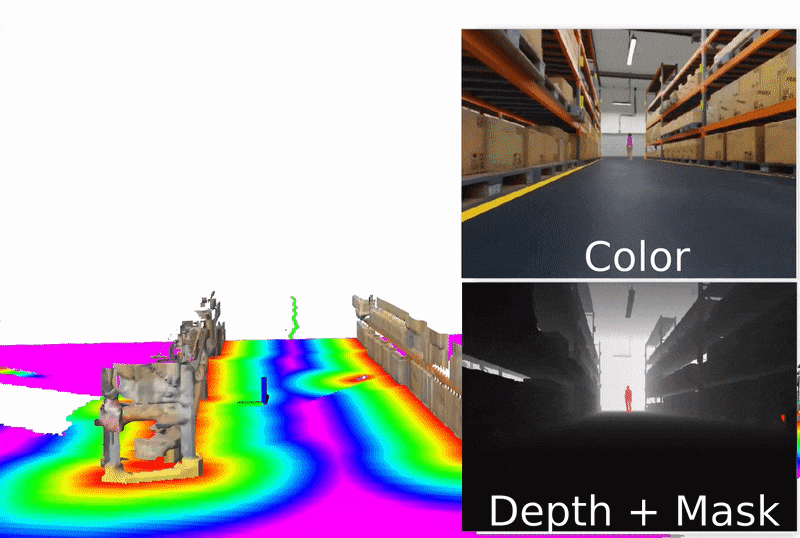
delivered into using the mesh visualization plugin. Nvblox streams mesh updates to RViz to update the reconstruction in real-time as it is built. In its default mode the environment is assumed to be static. Two additional modes of operation are provided to support mapping scenes which contain dynamic elements: people reconstruction, for mapping scenes containing people, and dynamic reconstruction, for mapping scenes containing more general dynamic objects. The graph above shows operating in people reconstruction mode. The color image
corresponding to the depth image is processed with , using the PeopleSemSegNet DNN model to estimate a segmentation mask for persons in the color image. Nvblox uses this mask to separate reconstructed persons into a separate people-only part of the reconstruction. The Technical Details provide more information on these three types of mapping. Performance The following tables provides timings for various functions of nvblox core on various platforms. (\*): Dynamics not supported on Jetson Nano.
Nvblox ROS 2 integration for local 3D scene reconstruction and mapping.
Overview
Isaac ROS Nvblox contains ROS 2 packages for 3D reconstruction and cost
maps for navigation. isaac_ros_nvblox processes depth and pose to
reconstruct a 3D scene in real-time and outputs a 2D costmap for
Nav2. The costmap is
used in planning during navigation as a vision-based solution to avoid
obstacles.
isaac_ros_nvblox is designed to work with depth-cameras and/or 3D LiDAR.
The package uses GPU acceleration to compute a 3D reconstruction and 2D costmaps using
nvblox, the underlying
framework-independent C++ library.
Above is a typical graph that uses isaac_ros_nvblox.
Nvblox takes a depth image, a color image, and a pose as input, with
which it computes a 3D scene reconstruction on the GPU. In this graph
the pose is computed using visual_slam, or some other pose estimation
node. The reconstruction
is sliced into an output cost map which is provided through a cost map plugin
into Nav2.
An optional colorized 3D reconstruction is delivered into rviz
using the mesh visualization plugin. Nvblox streams mesh updates
to RViz to update the reconstruction in real-time as it is built.
isaac_ros_nvblox offers several modes of operation. In its default mode
the environment is assumed to be static. Two additional modes of operation are provided
to support mapping scenes which contain dynamic elements: people reconstruction, for
mapping scenes containing people, and dynamic reconstruction, for mapping
scenes containing more general dynamic objects.
The graph above shows isaac_ros_nvblox operating in people reconstruction
mode. The color image corresponding to the depth image is processed with unet, using
the PeopleSemSegNet DNN model to estimate a segmentation mask for
persons in the color image. Nvblox uses this mask to separate reconstructed persons into a
separate people-only part of the reconstruction. The Technical Details
provide more information on these three types of mapping.
Performance
The following tables provides timings for various functions of
nvblox core on various platforms.