← 开源
LiJiangnanBit

path_optimizer

Optimization-based real-time path planning for vehicles.

ApplicationsSpecialistsC++
在 GitHub 打开
增长势头
+-124 小时新增 Star-0.2%
596
Star
150
Fork
+-1
本周
1
贡献者
创建于 2020-02-13 · 更新于 2026-10-16 · 今日第 19173 名
主要开发者

LiJiangnanBit/path_optimizer 排名第 19,173,有 596 个星标。

同类别比较

LiJiangnanBit/path_optimizer 排名第 19,173,此处有 8 个同类条目;basionwang-bot/HermesPet 排名第 19,171。

同类别比较
名称排名指标
iagooar/qqqa19,160
语言:
Rust
星标数:
628
分叉数:
21
简介:
Fast, stateless LLM for your shell: qq answers; qa runs commands
niuzaisheng/ScreenAgent19,164
语言:
Python
星标数:
616
分叉数:
66
简介:
ScreenAgent: A Computer Control Agent Driven by Visual Language Large Model (IJCAI-24)
krishn404/Git-Friend19,170
语言:
TypeScript
星标数:
599
分叉数:
35
简介:
GitFriend is an AI-powered GitHub companion built with React, TypeScript, and Firebase. It helps users resolve Git/GitHub issues through smart AI chat, generates dynamic and professional README files, and adds commit emojis to enhance commit history.
basionwang-bot/HermesPet19,171
语言:
TypeScript
星标数:
598
分叉数:
71
简介:
让 AI 住在你 MacBook 的刘海里 · 零依赖开箱即用 · 多引擎并行的桌面 AI 伴侣(Swift 6 / SwiftUI / macOS 14+)
PrismML-Eng/Bonsai-Image-Demo19,198
语言:
PowerShell
星标数:
556
分叉数:
75
简介:
Generate images locally
enesozturk/json-data-ai-template19,200
语言:
TypeScript
星标数:
555
分叉数:
37
简介:
JSONDataAI.com template with Next.js 13 and Vercel AI SDK
tatsu-lab/gpt_paper_assistant19,203
语言:
Python
星标数:
550
分叉数:
138
简介:
GPT4 based personalized ArXiv paper assistant bot
sb2702/free-ai-video-upscaler19,206
语言:
TypeScript
星标数:
546
分叉数:
111
简介:
Source code for free AI video upscaler tool
关键参数与规格
关键参数与规格
参数值
语言C++
类别Applications
子类别Specialists
关键词Autonomous vehicles, Optimization, Planning, Robotics
星标数596
分叉数150
贡献者1
创建日期2020-02-13
更新日期2026-10-16
1 天星标数-1
7 天星标数-1
排名19,173
上次排名16,137
排名变化-3,036
7 天星标排名17,889
上次 7 天星标排名15,493
7 天星标排名变化-2,396
总星标排名16,886
上次总星标排名16,827
总星标排名变化-59
国家China
README 摘录

path_optimizer :bell: CHECK OUT THE NEWER VERSION path_optimizer_2 and path_optimizer_ilqr **This ROS package generates feasible paths for non-holonomic vehicles. ** Simulation videos (1) Simulation in dynamic environment (2) Simulation with complex static obstacles Run demos 0. Install dependencies and build ROS kinetic on Ubuntu 16. sh* will install other dependencies (Those already installed will be skipped). 0 google benchmark glog gflags osqp-eigen grid_map ros_viz_tools tinyspline_ros. Demo A png image is

loaded as the grid map. You can click to specify the global reference path and the start/goal state of the vehicle. (1) Pick reference points using "Publish Point" tool in RViz. There are no hard and fast rules about the spacing of the points. If you want to abandon the chosen points, just double click anywhere when using the "Publish Point" tool. You can replace with other black and white images. Note that the resolution in is set to

0. 2m, whick means that the length of one pixel is 0. In application, the reference path is given by a global path or by a search algorithm like A*. (2) Pick start state using "2D Pose Estimate" tool and pick goal state using "2D Nav Goal" tool. Currently, it's not strictly required to reach the goal state. The start state must be ahead of the first reference point. Benchmark test This is a computation time test. cpp The parameters

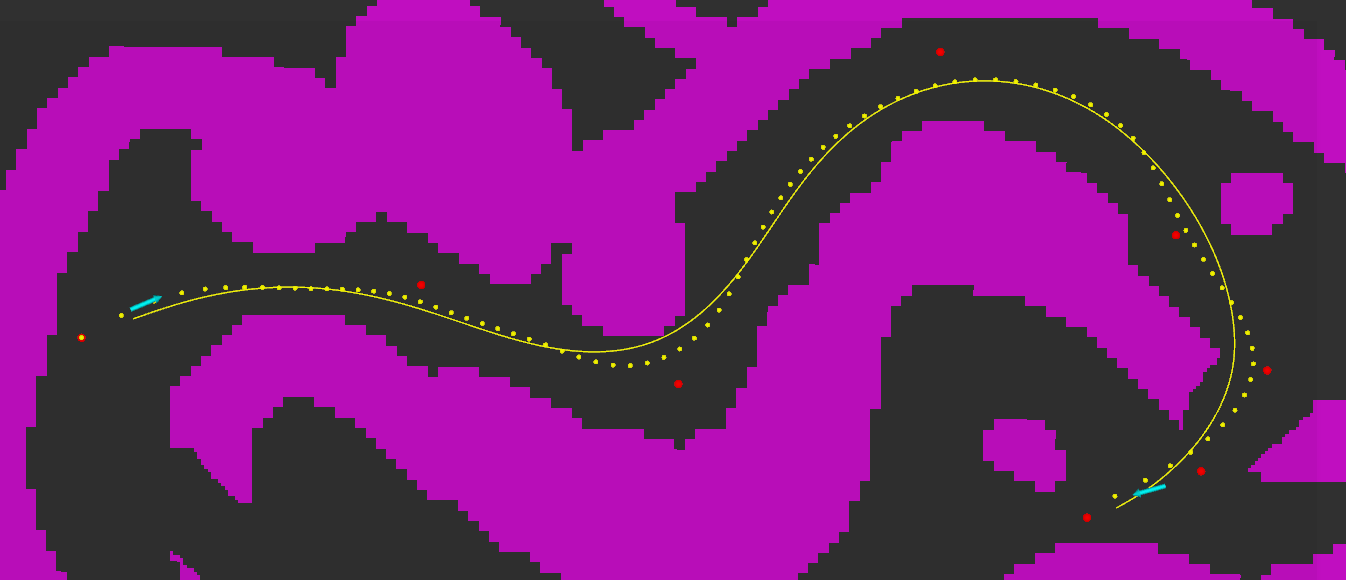
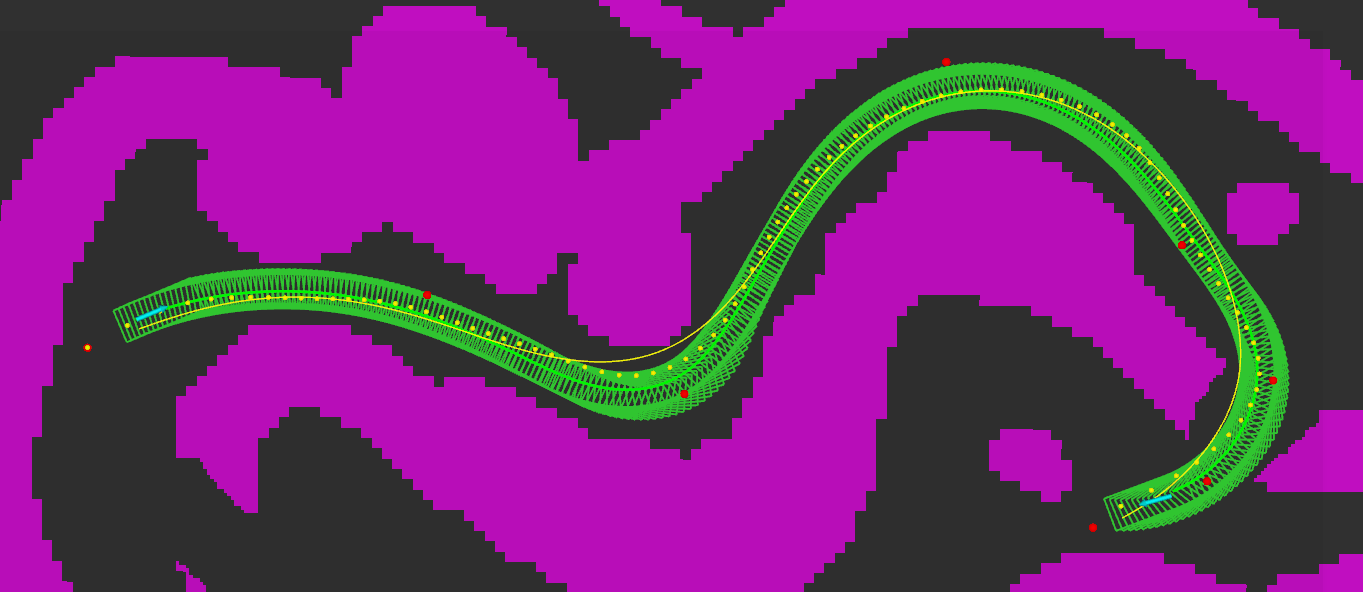
that you can change can be found in . (Optional) Use B spline curve fitting to make the path continuous and then search around it for a more reasonable reference path (yellow dots). This step can be skipped by changing settings. Smooth the reference path using IPOPT (yellow curve). Represent the path planning problem as a QP and solve it using OSQP.

常见问题

记录了多少星标和分叉?

LiJiangnanBit/path_optimizer 有 596 个星标和 150 个分叉。

仓库排名是多少?

LiJiangnanBit/path_optimizer 排名第 19,173。

记录的语言和类别是什么?

LiJiangnanBit/path_optimizer 有 596 个星标,语言为 C++,类别为 Applications。

哪个仓库排名最接近?

LiJiangnanBit/path_optimizer 与 basionwang-bot/HermesPet 比较,后者排名第 19,171,有 598 个星标。

README

path_optimizer

:bell: CHECK OUT THE NEWER VERSION path_optimizer_2 and path_optimizer_ilqr


This ROS package generates feasible paths for non-holonomic vehicles.
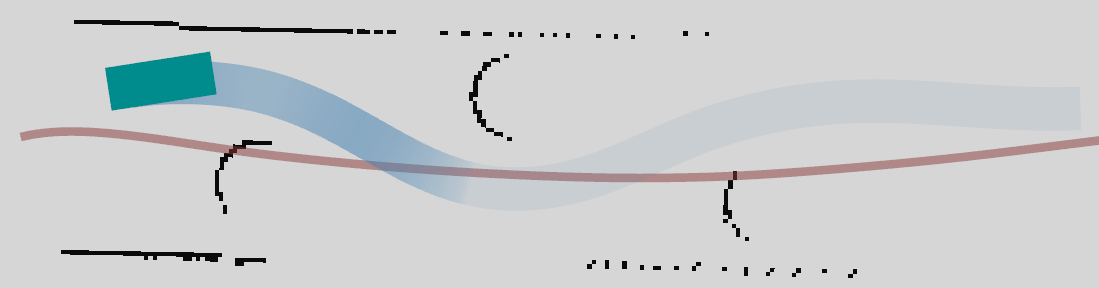
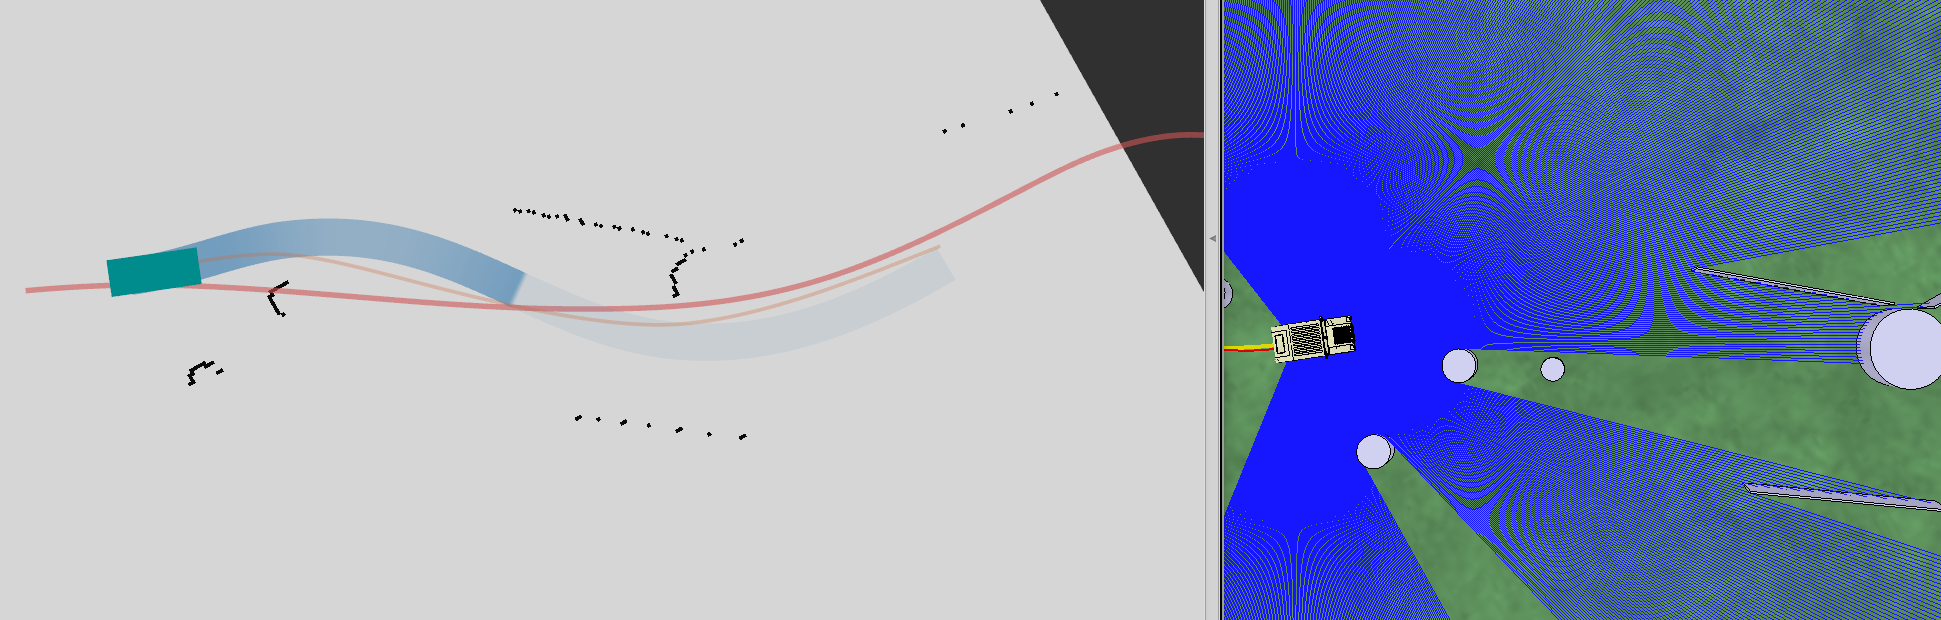
Simulation videos

(1) Simulation in dynamic environment

(2) Simulation with complex static obstacles
Run demos

0. Install dependencies and build

  • ROS kinetic on Ubuntu 16.04
  • OpenCV 3
mkdir -p workspace/src && cd workspace/src
git clone git@github.com:LiJiangnanBit/path_optimizer.git
sudo bash path_optimizer/scripts/install_deps.sh
cd ..
catkin build path_optimizer
source devel/setup.bash

install_deps.sh will install other dependencies (Those already installed will be skipped). These dependencies include:

1. Demo

A png image is loaded as the grid map. You can click to specify the global reference path and the start/goal state of the vehicle.

roslaunch path_optimizer demo.launch

(1) Pick reference points using "Publish Point" tool in RViz.

  • Pick at least six points.
  • There are no hard and fast rules about the spacing of the points.
  • If you want to abandon the chosen points, just double click anywhere when using the "Publish Point" tool.
  • You can replace gridmap.png with other black and white images. Note that the resolution in demo.cpp is set to 0.2m, whick means that the length of one pixel is 0.2m on the map.
  • In application, the reference path is given by a global path or by a search algorithm like A*.
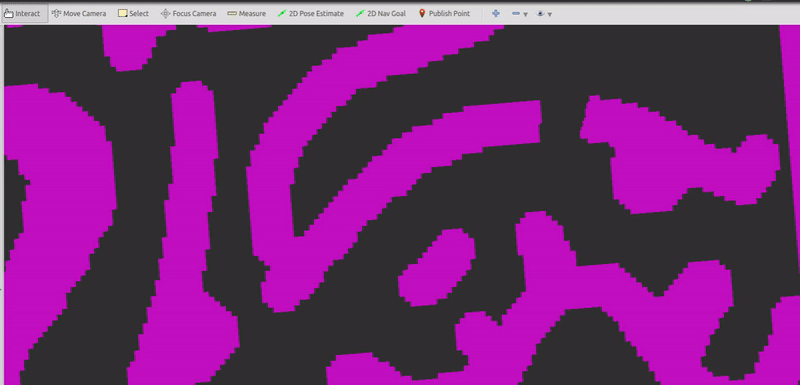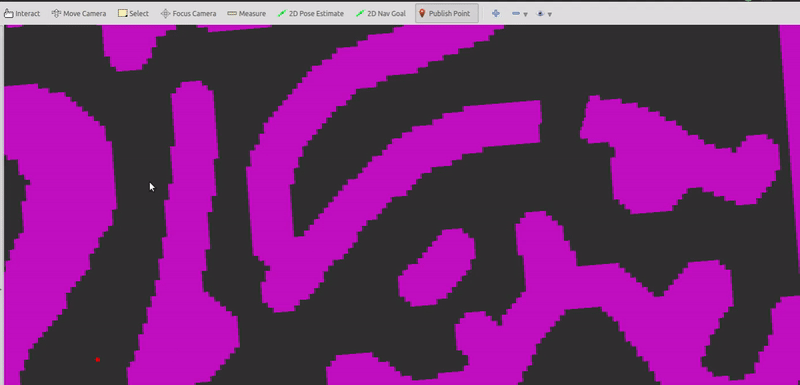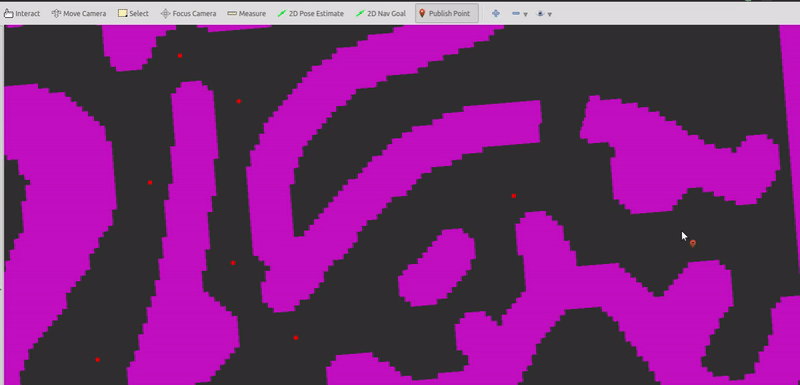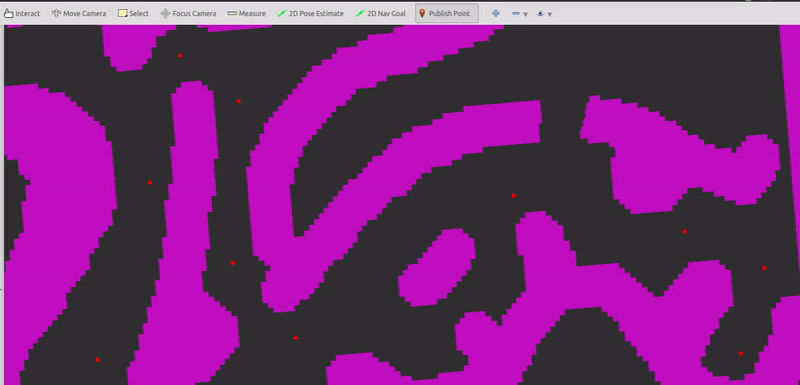
(2) Pick start state using "2D Pose Estimate" tool and pick goal state using "2D Nav Goal" tool.

  • Currently, it's not strictly required to reach the goal state. But this can be changed.
  • The start state must be ahead of the first reference point.
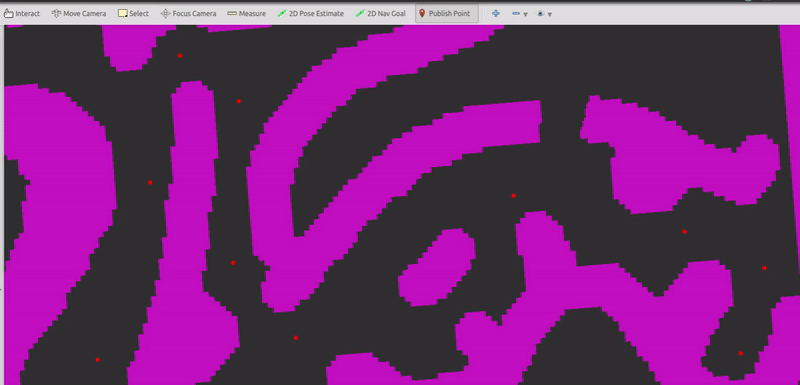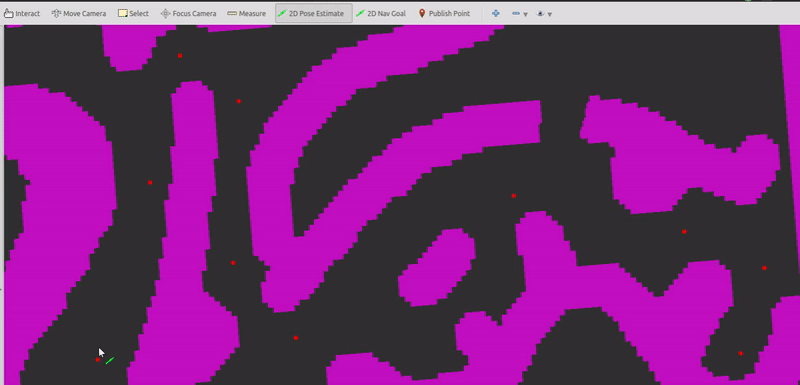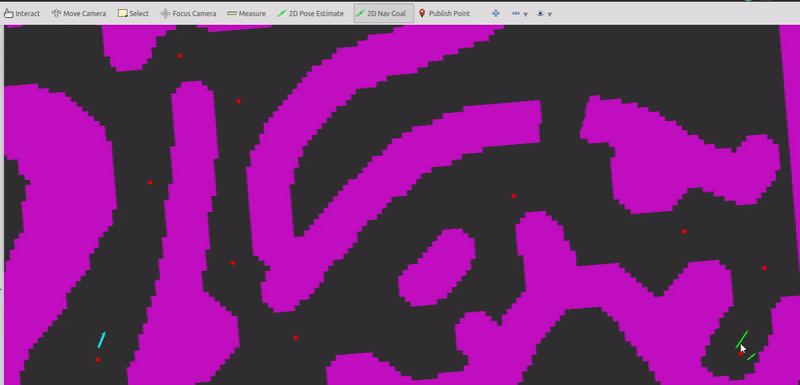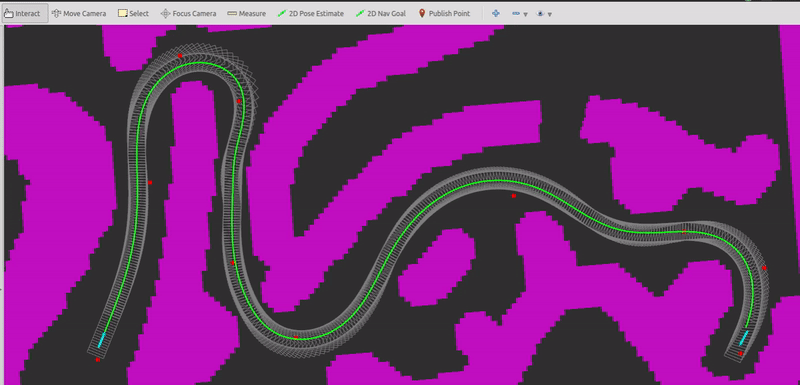
2. Benchmark test

This is a computation time test.

rosrun path_optimizer path_optimizer_benchmark

Usage

Refer to demo.cpp
The parameters that you can change can be found in planning_flags.cpp.

How it works

Refer here.

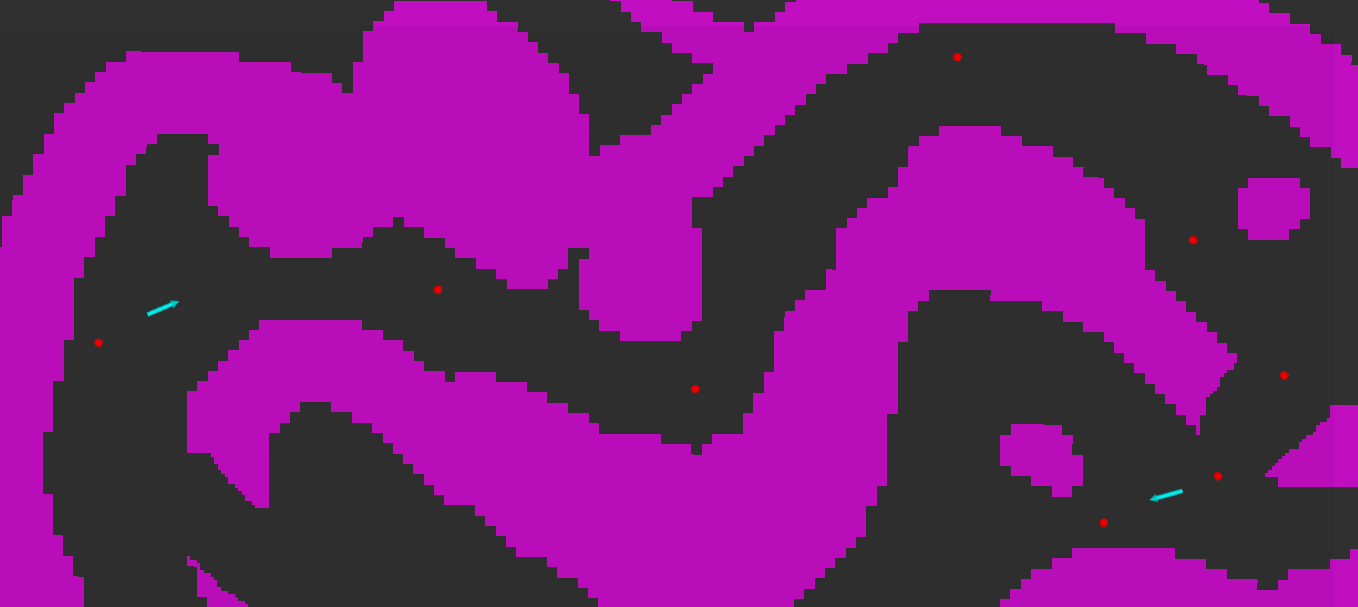
  1. Take inputs (red dots):
  2. (Optional) Use B spline curve fitting to make the path continuous and then search around it for a more reasonable reference path (yellow dots). This step can be skipped by changing settings.
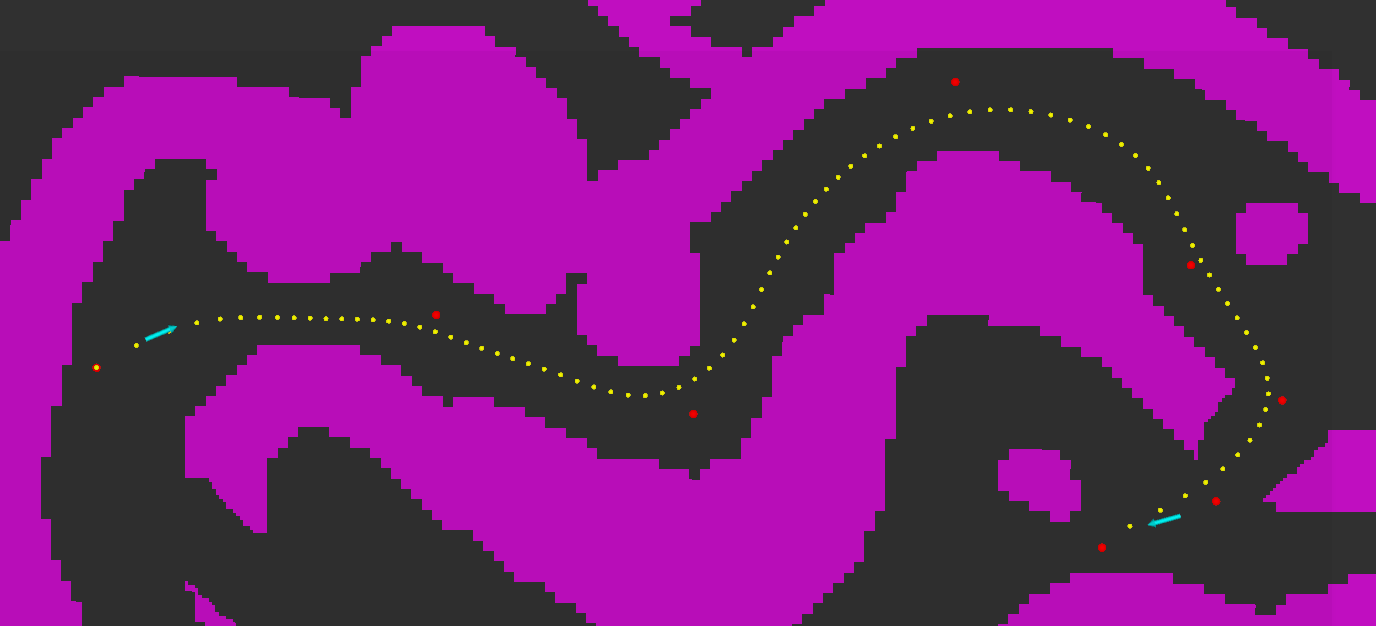
  3. Smooth the reference path using IPOPT (yellow curve).
  4. Represent the path planning problem as a QP and solve it using OSQP.
排名相邻
同类项目