ACM Multimedia2020 University-1652: A Multi-view Multi-source Benchmark for Drone-based Geo-localization :helicopter: annotates 1652 buildings in 72 universities around the world.
Unitree Go2 simulation platform for testing navigation, decision-making and autonomous tasks. (NVIDIA Isaac/ROS2)
关键参数与规格
关键参数与规格
参数
值
语言
Cuda
类别
Model Development
子类别
Environments,Reinforcement Learning
关键词
Computer vision, CUDA programming, Embodied, Robotics
星标数
640
分叉数
92
贡献者
2
创建日期
2025-04-17
更新日期
2026-10-16
1 天星标数
2
7 天星标数
6
排名
4,200
上次排名
15,507
排名变化
11,307
7 天星标排名
5,276
上次 7 天星标排名
6,426
7 天星标排名变化
1,150
总星标排名
15,964
上次总星标排名
15,989
总星标排名变化
25
国家
China
README 摘录
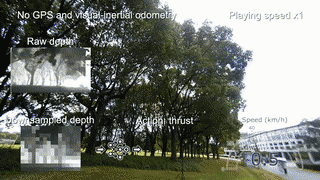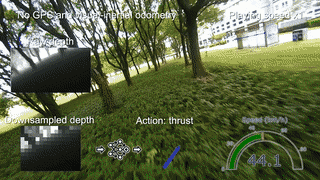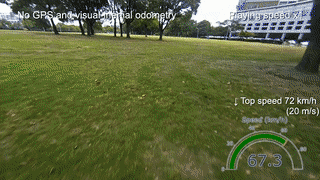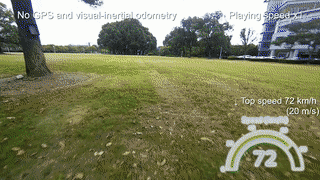
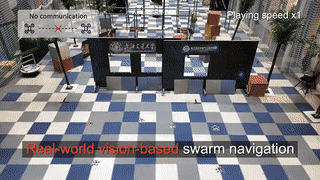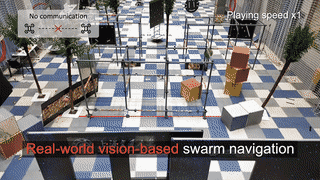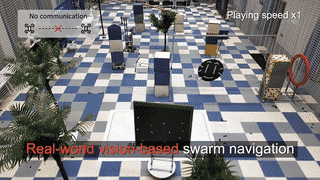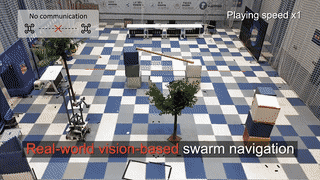
Vision-based Agile Flight Training Code Overview This repository contains the training code for our research on **Learning Vision-based Agile Flight via Differentiable Physics**. Accepted by **Nature Machine Intelligence'25**. Quick Demos Single Agent Flights Swarm Tasks Environment Setup Python Environment The code is tested with the following environment: **PyTorch**: 2. 8 The code should be compatible with other PyTorch and CUDA versions. Build CUDA Ops To build the CUDA operations, run the following command: Training To start the
training process, use the following command: Evaluation You need to download the simulation validation code from the GitHub release page. To evaluate the trained model in multi-agent settings, use the following command to launch the simulator: Citation If using this repository, please cite our work Then, run the following command to evaluate the trained model:
常见问题
记录了多少星标和分叉?
HenryHuYu/DiffPhysDrone 有 640 个星标和 92 个分叉。
仓库排名是多少?
HenryHuYu/DiffPhysDrone 排名第 4,200。
记录的语言和类别是什么?
HenryHuYu/DiffPhysDrone 有 640 个星标,语言为 Cuda,类别为 Model Development。
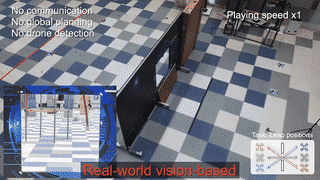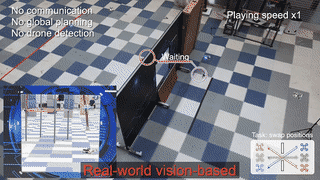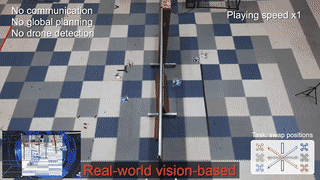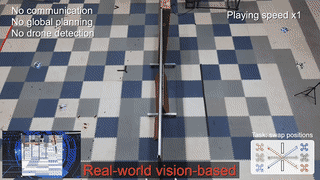
This repository contains the training code for our research on Learning Vision-based Agile Flight via Differentiable Physics. Accepted by Nature Machine Intelligence'25.
The code is tested with the following environment:
PyTorch: 2.2.2
Python: 3.11
CUDA: 11.8
The code should be compatible with other PyTorch and CUDA versions.
Build CUDA Ops
To build the CUDA operations, run the following command:
pip install -e src
Training
To start the training process, use the following command:
# For multi-agemt
python main_cuda.py $(cat configs/multi_agent.args)
# For single-agemt
python main_cuda.py $(cat configs/single_agent.args)
Evaluation
You need to download the simulation validation code from the GitHub release page.
To evaluate the trained model in multi-agent settings, use the following command to launch the simulator:
cd
./LinuxNoEditor/Blocks.sh -ResX=896 -ResY=504 -windowed -WinX=512 -WinY=304 -settings=$PWD/settings.json
Citation
If using this repository, please cite our work
@article{zhang2025learning,
  title={Learning vision-based agile flight via differentiable physics},
  author={Zhang, Yuang and Hu, Yu and Song, Yunlong and Zou, Danping and Lin, Weiyao},
  journal={Nature Machine Intelligence},
  pages={1--13},
  year={2025},
  publisher={Nature Publishing Group}
}
Then, run the following command to evaluate the trained model: