← Open Source
silvery107

rl-mpc-locomotion

Deep RL for MPC control of Quadruped Robot Locomotion.

Model DevelopmentEnvironmentsReinforcement LearningPython
Open on GitHub
Momentum
+0stars in 24 hours0.0%
1.03k
Stars
92
Forks
+1
This week
1
Contributors
Created 2021-11-22 · Updated 2026-10-12 · #11995 today
Top developers

silvery107/rl-mpc-locomotion is ranked 11,995 with 1,029 stars.

Same-category comparison

silvery107/rl-mpc-locomotion is ranked 11,995 among these 8 peers; cityflow-project/CityFlow is ranked 11,994.

Same-category comparison
NameRankMetrics
vincentherrmann/pytorch-wavenet11,985
Language:
Jupyter Notebook
Stars:
1,031
Forks:
229
Description:
An implementation of WaveNet with fast generation.
graphdeeplearning/graphtransformer11,989
Language:
Python
Stars:
1,030
Forks:
150
Description:
Graph Transformer Architecture. Source code for "A Generalization of Transformer Networks to Graphs", DLG-AAAI'21.
microsoft/gated-graph-neural-network-samples11,990
Language:
Python
Stars:
1,030
Forks:
255
Description:
Sample Code for Gated Graph Neural Networks.
cityflow-project/CityFlow11,994
Language:
C++
Stars:
1,029
Forks:
208
Description:
A Multi-Agent Reinforcement Learning Environment for Large Scale City Traffic Scenario.
Minqi824/ADBench12,002
Language:
Python
Stars:
1,027
Forks:
151
Description:
Official Implement of "ADBench: Anomaly Detection Benchmark", NeurIPS 2022.
buaacyw/MeshAnythingV212,013
Language:
Python
Stars:
1,025
Forks:
73
Description:
[ICCV 2025] From anything to mesh like human artists. Official impl. of "MeshAnything V2: Artist-Created Mesh Generation With Adjacent Mesh Tokenization".
edvardHua/PoseEstimationForMobile12,014
Language:
C++
Stars:
1,025
Forks:
266
Description:
:dancer: Real-time single person pose estimation for Android and iOS.
CLUEbenchmark/CLUECorpus202012,022
Stars:
1,023
Forks:
83
Key parameters and specifications
ParameterValue
LanguagePython
CategoryModel Development
SubcategoryEnvironments, Reinforcement Learning
KeywordsEmbodied, Robotics
Stars1,029
Forks92
Contributors1
Created date2021-11-22
Updated date2026-10-12
Stars in 1 day0
Stars in 7 days1
Rank11,995
Previous rank11,912
Rank change-83
7-day stars rank10,279
Previous 7-day stars rank10,319
7-day stars rank change40
Total stars rank10,921
Previous total stars rank10,906
Total stars rank change-15
CountryUSA
README summary

RL MPC Locomotion This repo aims to provide a fast simulation and RL training framework for a quadruped locomotion task by dynamically predicting the weight parameters of a MPC controller. The control framework is a hierarchical controller composed of a higher-level policy network and a lower-level model predictive controller. The MPC controller refers to Cheetah Software but written in python, and it completely opens the interface between sensor data and motor commands, so that the controller can be

easily ported to any mainstream simulators. The RL training utilizes the NVIDIA Isaac Gym in parallel using Unitree Robotics Aliengo model, and transferring it from simulation to reality on a real Aliengo robot (sim2real is not included in this codebase). 3 *Isaac Gym* - Preview 4 Installation 1. Initialize submodules bash cd extern/rsl_rl pip install -e . bridge_MPC_to_RL False ` Roadmap [x] **MPC Controller** Quadruped, RobotRunner -> [x] **RL Environment** Gamepad Reader, Simulation Utils, Weight Policy, Train -> User Notes

Setup a Simulation in Isaac Gym Install MIT Cheetah Software OSQP, qpOASES and CVXOPT Solver Instructions Development Logs Gallery

Frequently asked questions

How many stars and forks are recorded?

silvery107/rl-mpc-locomotion has 1,029 stars and 92 forks.

What is the repository rank?

silvery107/rl-mpc-locomotion is ranked 11,995.

What language and category are recorded?

silvery107/rl-mpc-locomotion has 1,029 stars, uses Python and belongs to Model Development.

Which repository is closest in rank?

silvery107/rl-mpc-locomotion is compared with cityflow-project/CityFlow, ranked 11,994 with 1,029 stars.

README

RL MPC Locomotion

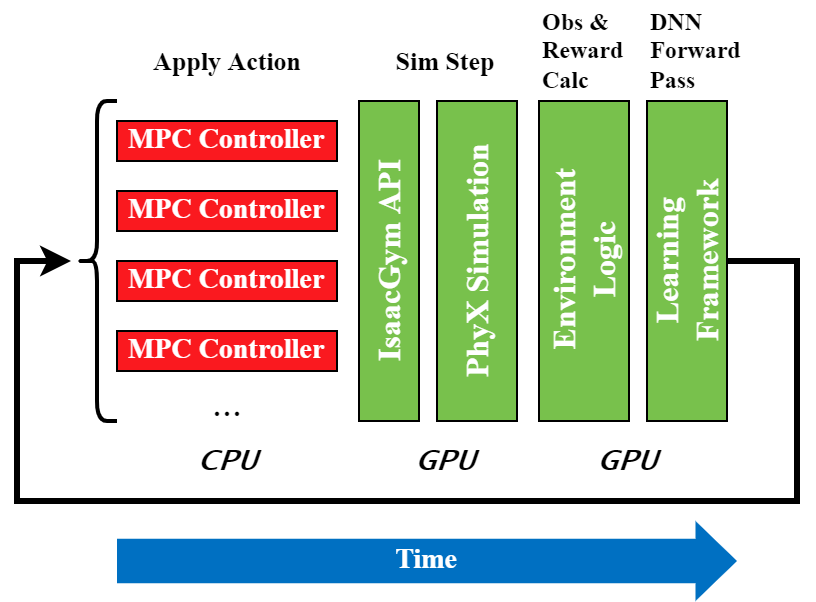
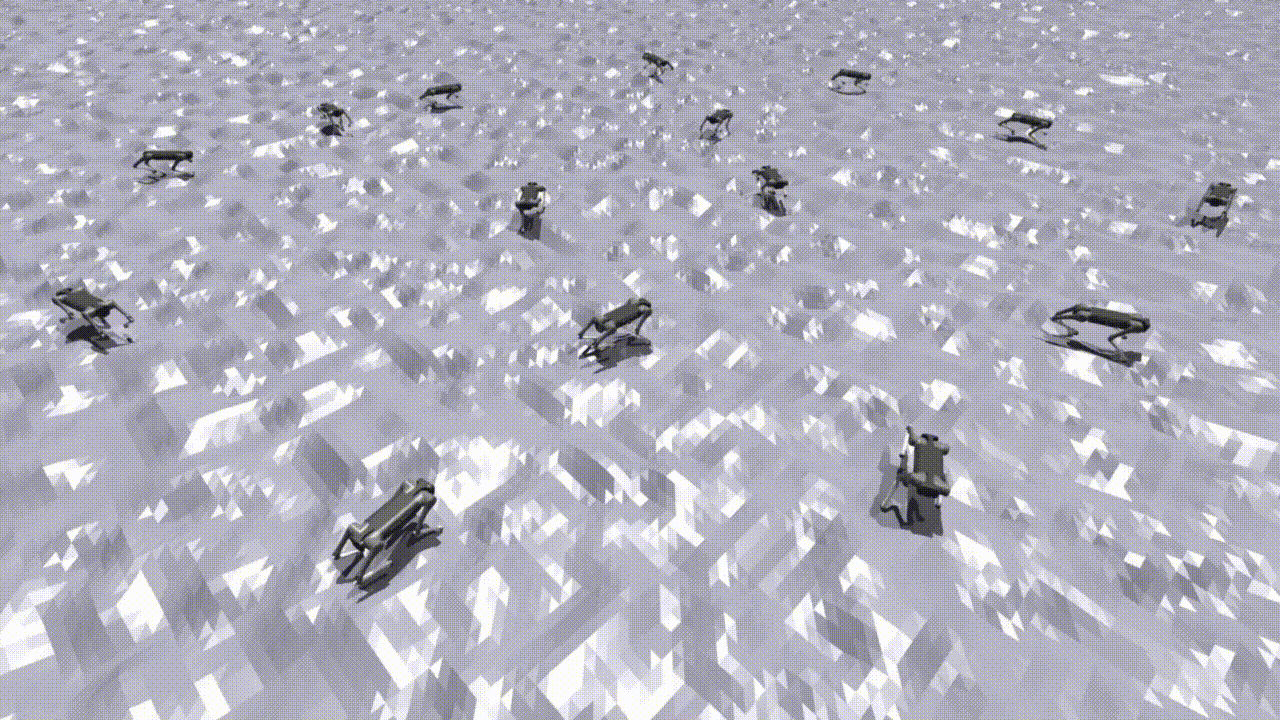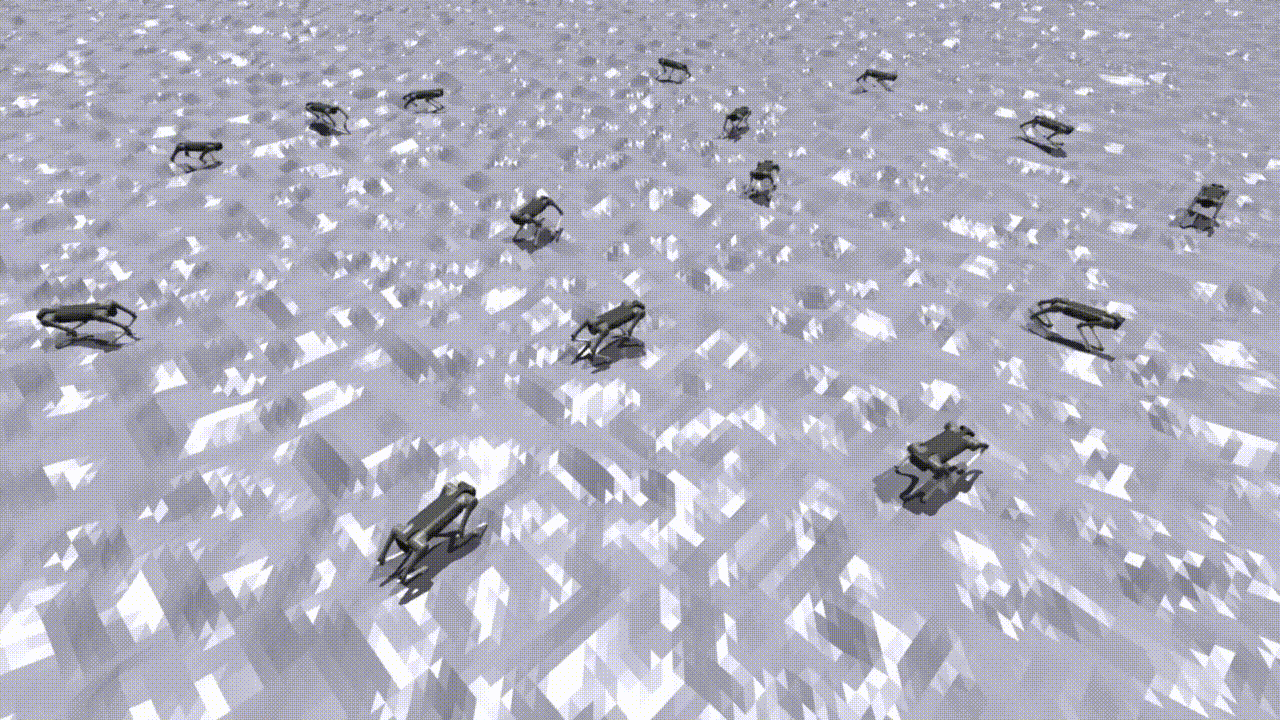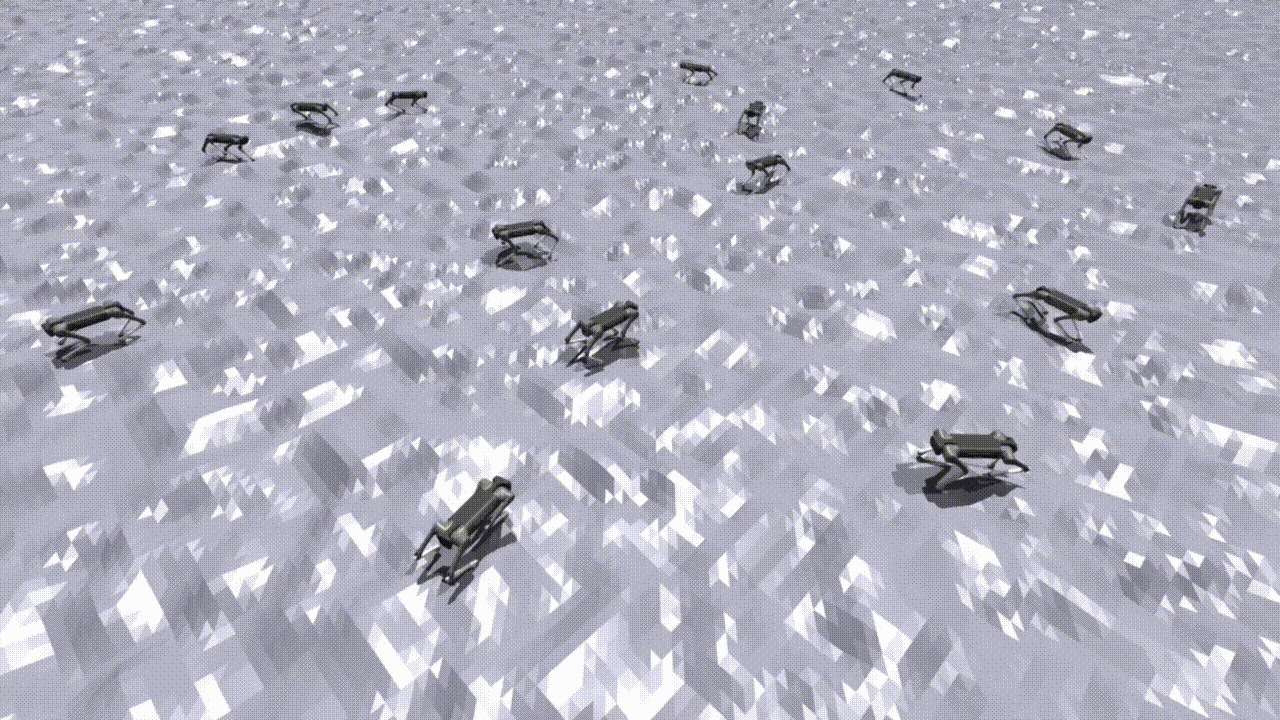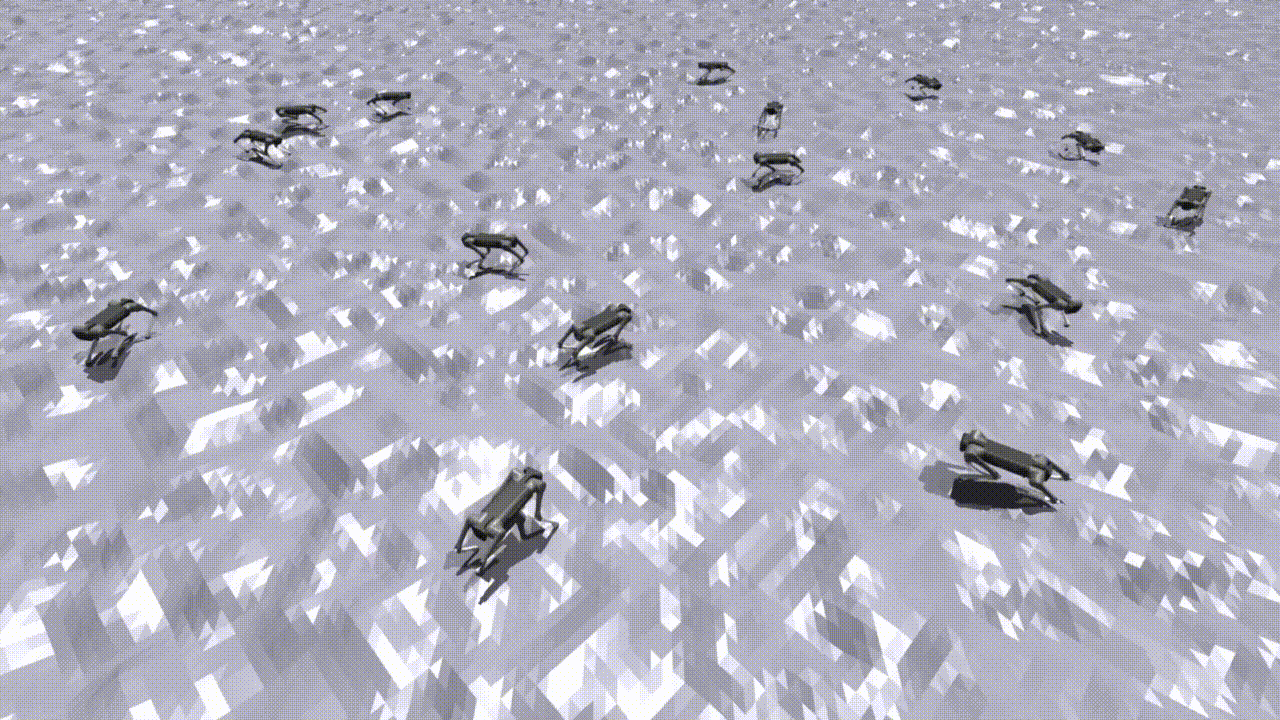
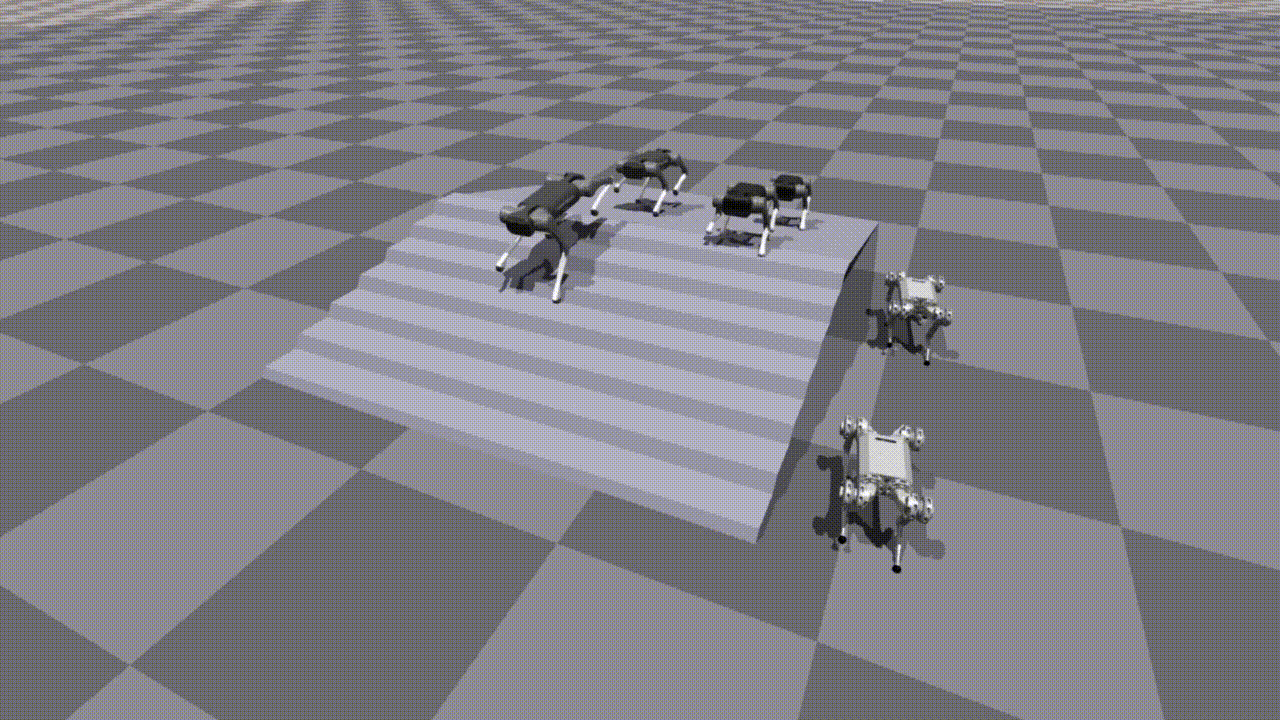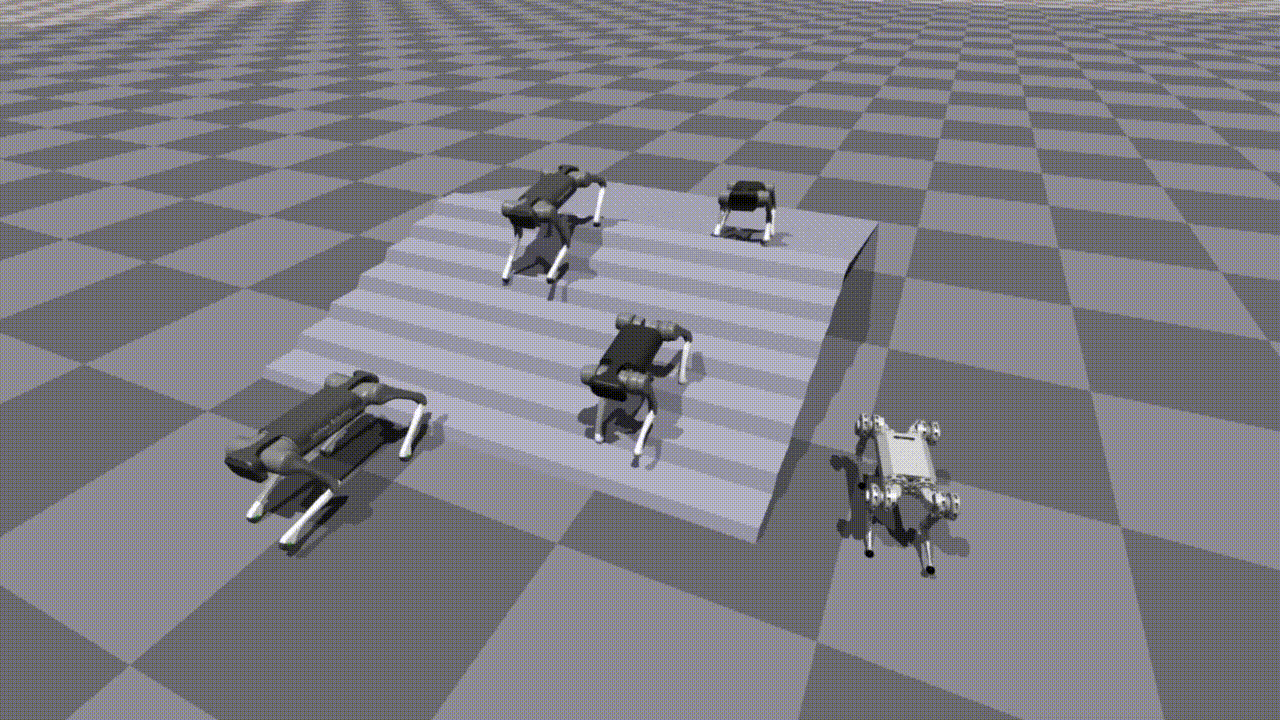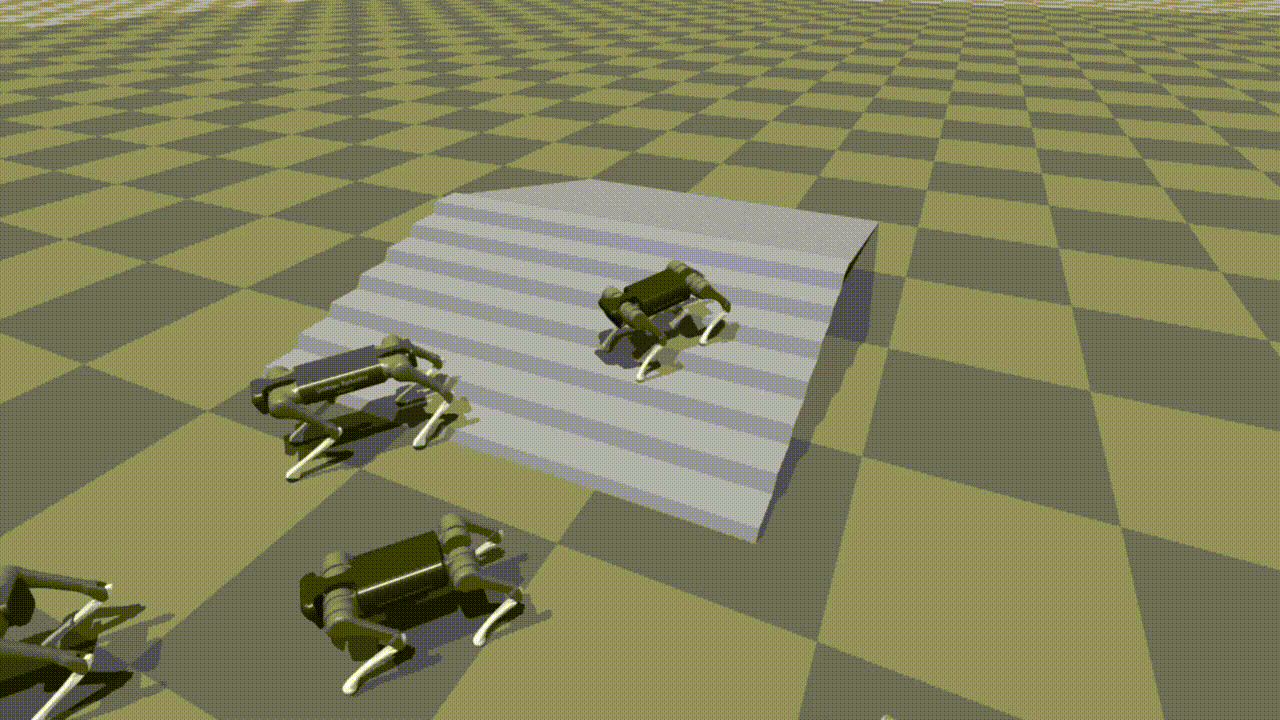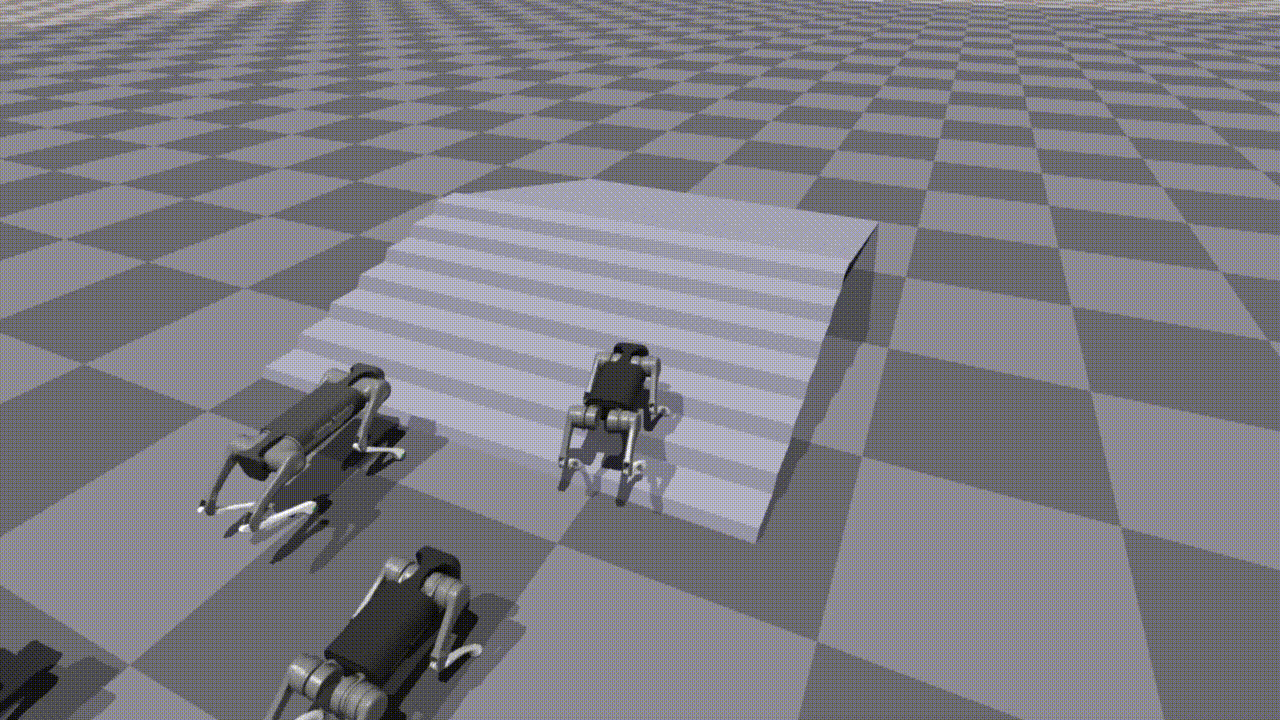
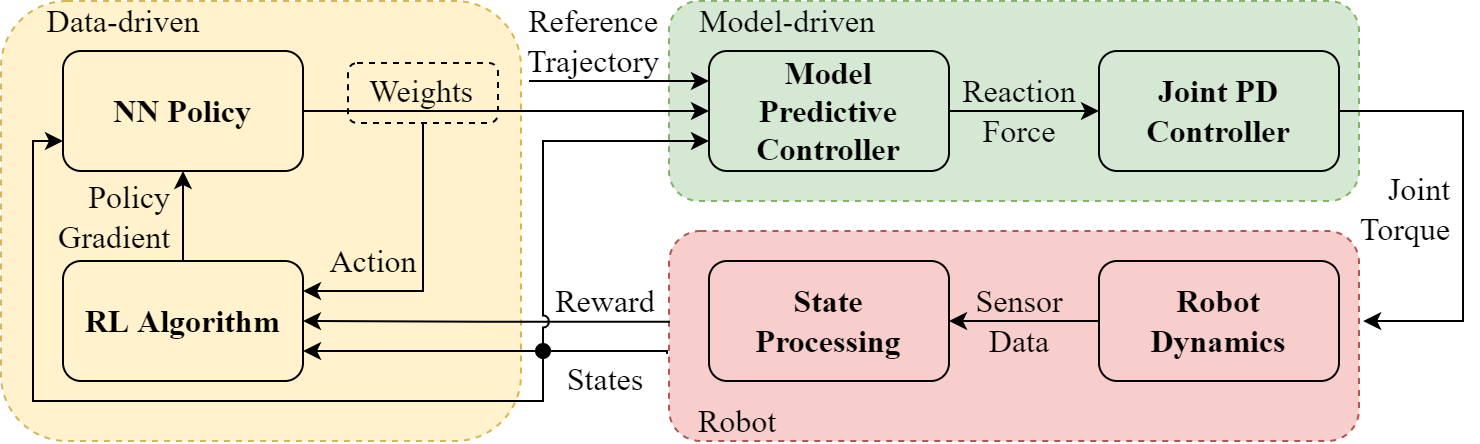
This repo aims to provide a fast simulation and RL training framework for a quadruped locomotion task by dynamically predicting the weight parameters of a MPC controller. The control framework is a hierarchical controller composed of a higher-level policy network and a lower-level model predictive controller.

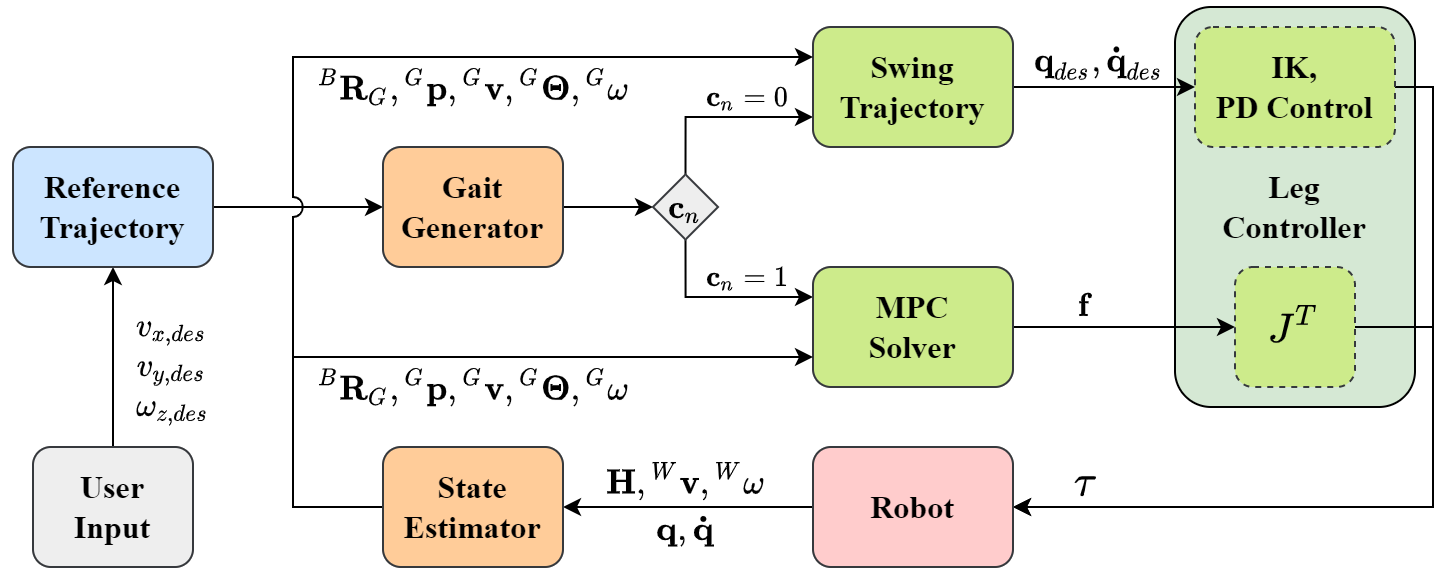
The MPC controller refers to Cheetah Software but written in python, and it completely opens the interface between sensor data and motor commands, so that the controller can be easily ported to any mainstream simulators.

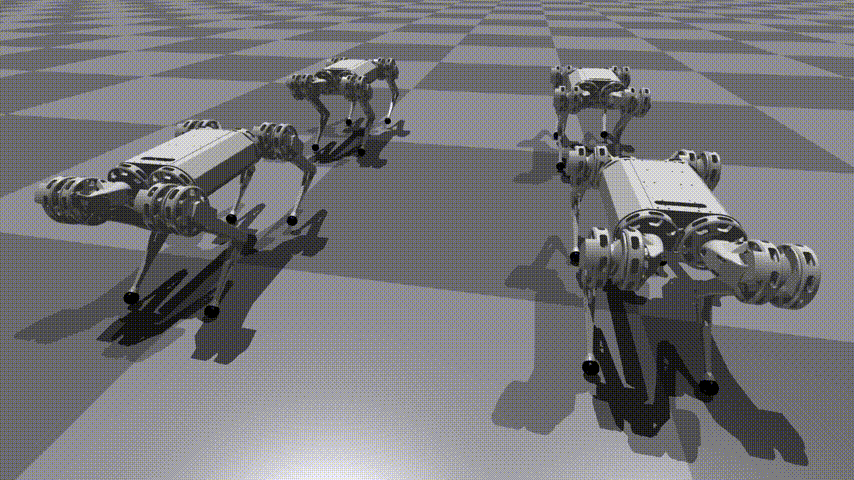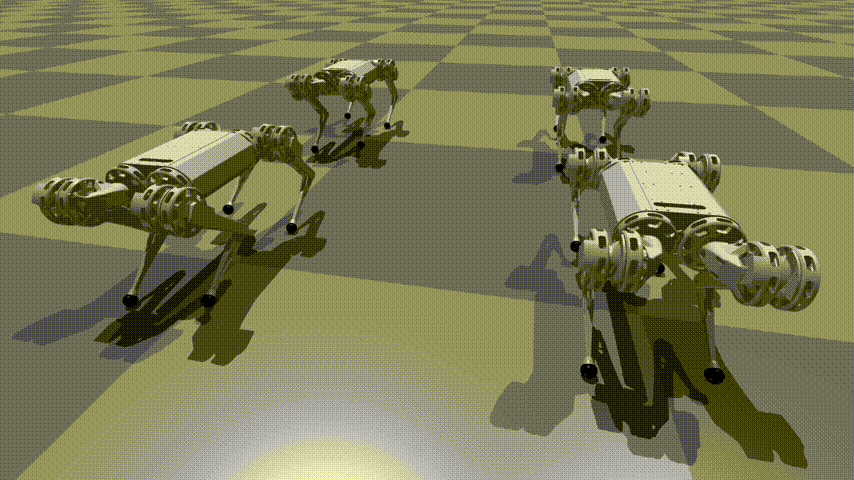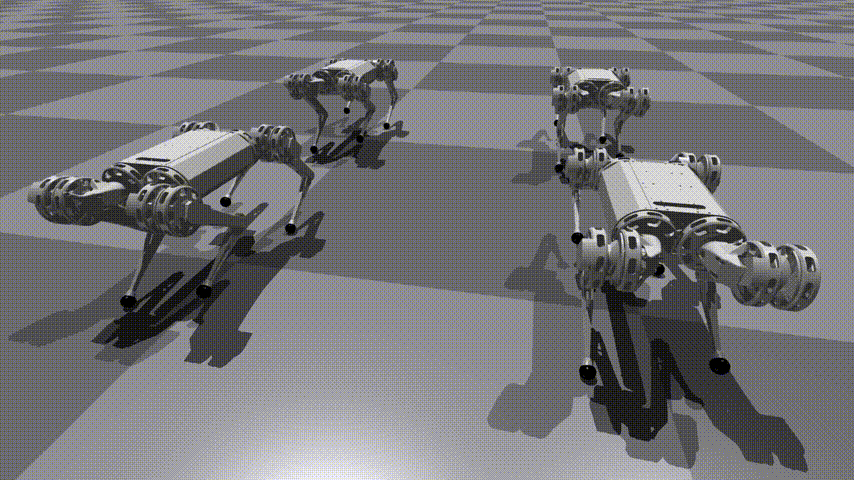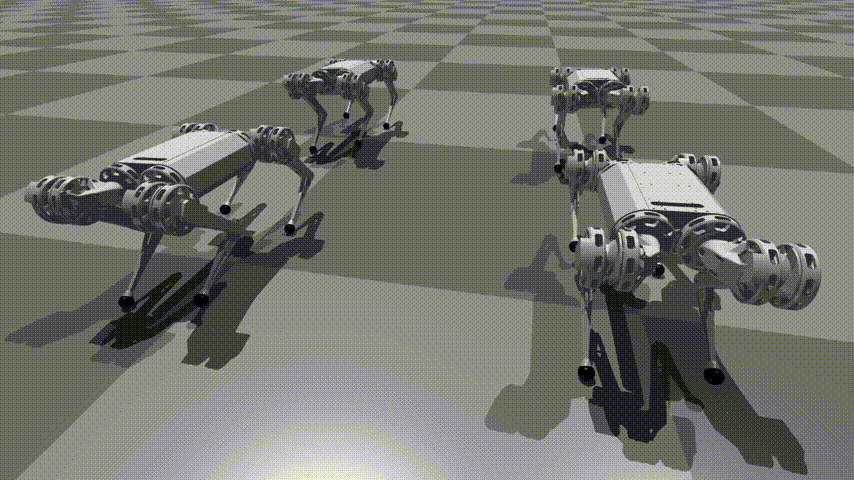
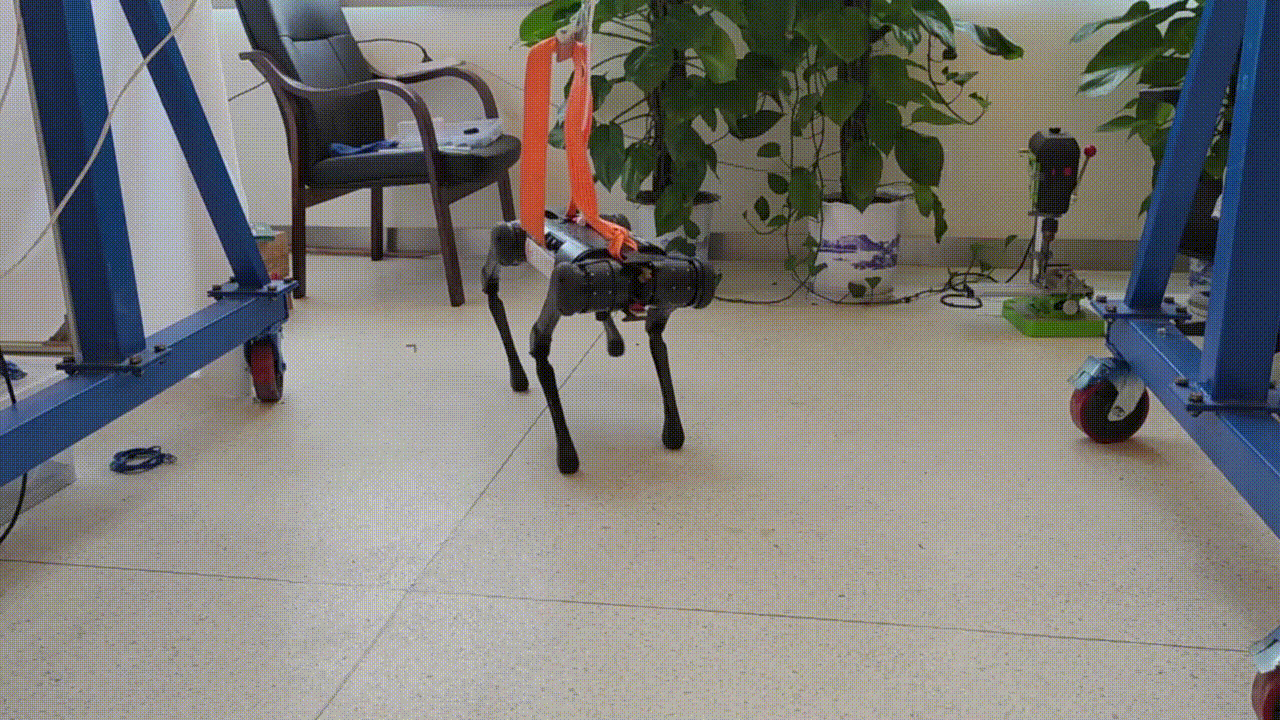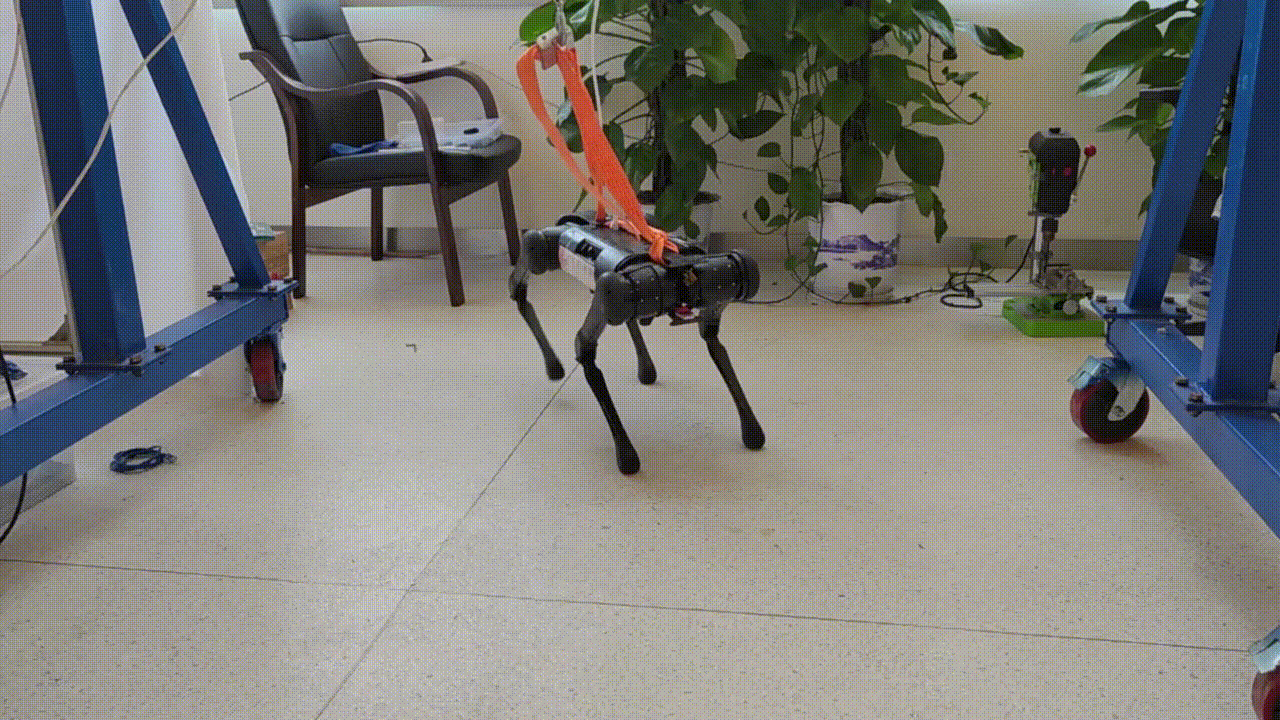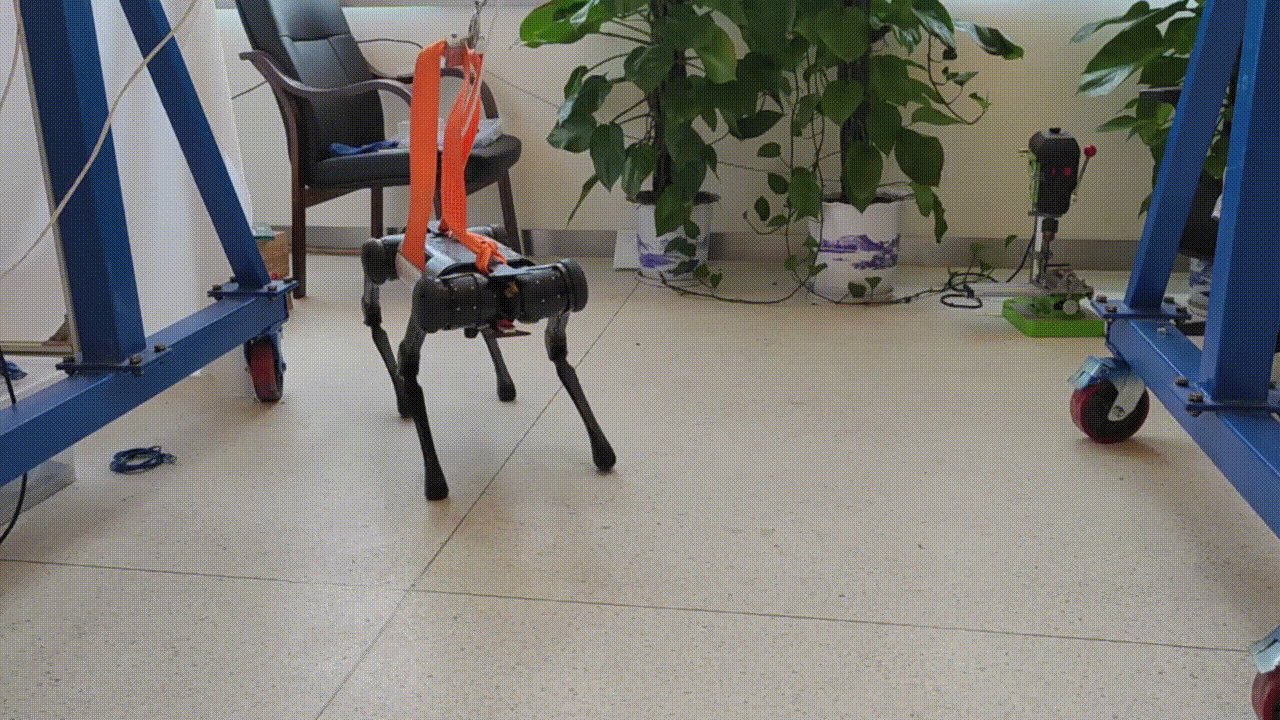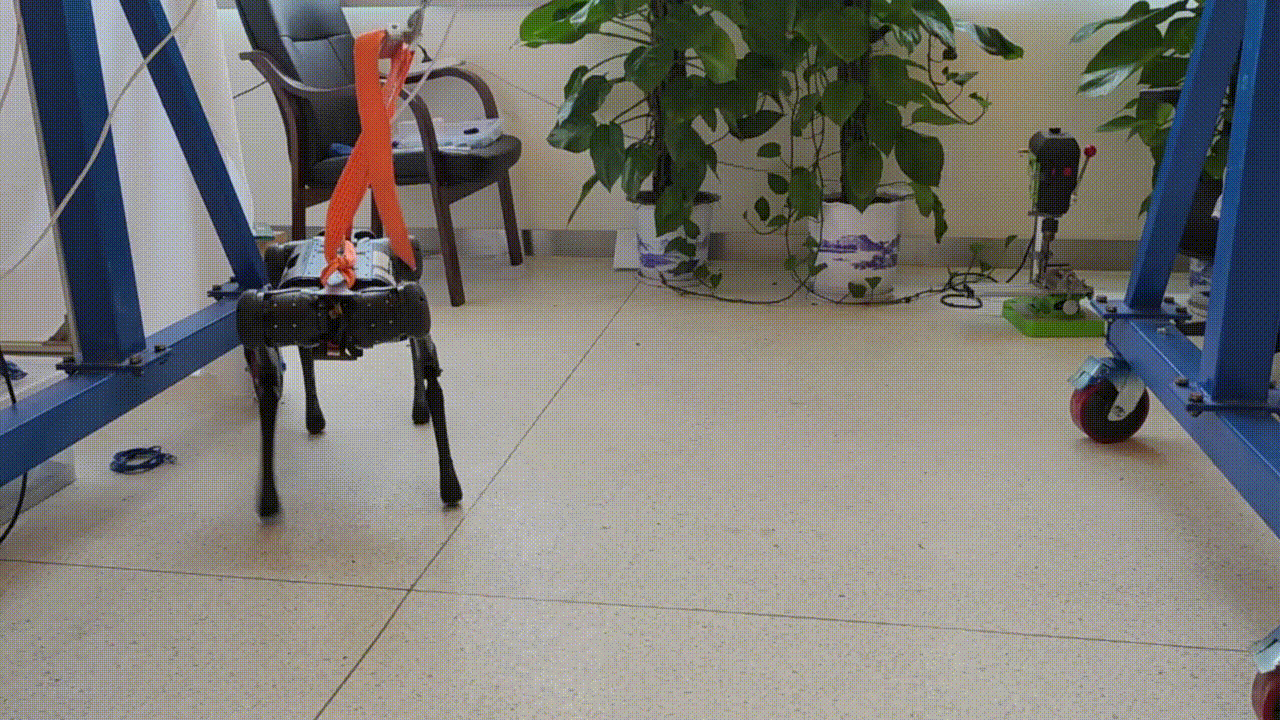
The RL training utilizes the NVIDIA Isaac Gym in parallel using Unitree Robotics Aliengo model, and transferring it from simulation to reality on a real Aliengo robot (sim2real is not included in this codebase).

Frameworks
Dependencies

Installation

  1. Clone this repository
    git clone git@github.com:silvery107/rl-mpc-locomotion.git
    
  2. Initialize submodules
     git submodule update --init
    
    Or use the --recurse option in step 1 to clone submodules at the same time.
  3. Create the conda environment:
    conda env create -f environment.yml
    
  4. Install rsl_rl at commit 2ad79cf under `` folder
    cd extern/rsl_rl
    pip install -e .
    
  5. Compile python binding of the MPC solver:
    pip install -e .
    

Quick Start

  1. Play the MPC controller on Aliengo:

    python RL_MPC_Locomotion.py --robot=Aliengo
    

    All supported robot types are Go1, A1 and Aliengo.

    Note that you need to plug in your Xbox-like gamepad to control it, or pass --disable-gamepad. The controller mode is default to Fsm (Finite State Machine), and you can also try Min for the minimum MPC controller without FSM.

    • Gamepad keymap

      Press LB to switch gait types between Trot, Walk and Bound.

      Press RB to switch FSM states between Locomotion and Recovery Stand

  2. Train a new policy:

    cd RL_Environment
    python train.py task=Aliengo headless=False
    

    Press the v key to disable viewer updates, and press again to resume. Set headless=True to train without rendering.

    Tensorboard support is available, run tensorboard --logdir runs.

  3. Load a pretrained checkpoint:

    python train.py task=Aliengo checkpoint=runs/Aliengo/nn/Aliengo.pth test=True num_envs=4
    

    Set test=False to continue training.

  4. Run the pretrained weight-policy for MPC controller on Aliengo: Set bridge_MPC_to_RL to False in ``

    python RL_MPC_Locomotion.py --robot=Aliengo --mode=Policy --checkpoint=path/to/ckpt
    

    If no checkpoint is given, it will load the latest run.

Roadmap
User Notes

Gallery

Nearby in the ranking
Similar items