← Open Source
michiganrobotics

rob311

How to Build Robots and Make Them Move.

MiscPython
Open on GitHub
Momentum
+0stars in 24 hours0.0%
1.27k
Stars
242
Forks
+4
This week
1
Contributors
Created 2023-06-14 · Updated 2026-10-14 · #10907 today
Top developers

michiganrobotics/rob311 is ranked 10,907 with 1,266 stars.

Same-category comparison

michiganrobotics/rob311 is ranked 10,907 among these 8 peers; daaain/claude-code-log is ranked 10,997.

Same-category comparison
NameRankMetrics
zed-industries/extensions9,233
Language:
JavaScript
Stars:
1,931
Forks:
2,704
Description:
Extensions for the Zed editor.
LottieFiles/lottie-player9,755
Language:
TypeScript
Stars:
1,657
Forks:
184
Description:
Lottie viewer/player as an easy to use web component. https://lottiefiles.com/web-player.
wenfxl/openai-cpa10,434
Stars:
1,404
Forks:
441
Description:
Enterprise Distributed Automation Platform for massive concurrent workload execution. Unifies elastic cluster orchestration, multi-channel identity verification messaging, real-time ops telemetry, and multi-warehouse lifecycle control (CPA / Sub2API / Image2API) in one high-throughput control plane.
acheong08/ChatGPTProxy10,672
Language:
Go
Stars:
1,328
Forks:
322
Description:
Simple Cloudflare bypass for ChatGPT.
daaain/claude-code-log10,997
Language:
Python
Stars:
1,242
Forks:
101
Description:
A Python CLI tool that converts Claude Code transcript JSONL files into readable HTML / Markdown format.
CSCB/vibe-mouse11,295
Language:
Python
Stars:
1,173
Forks:
0
Description:
Core open-source Vibecoding interactive mouse project, belonging to a self-developed open-source system including the nation's first open-source robot actuator and stepless mobile intelligent monitoring solution.
generaltranslation/gt11,771
Language:
TypeScript
Stars:
1,069
Forks:
40
Description:
Full-stack localization for every framework.
microsoft/vscode-copilot-release12,033
Stars:
1,022
Forks:
144
Description:
Feedback on GitHub Copilot Chat UX in Visual Studio Code.
Key parameters and specifications
ParameterValue
LanguagePython
CategoryMisc
KeywordsRobotics
Stars1,266
Forks242
Contributors1
Created date2023-06-14
Updated date2026-10-14
Stars in 1 day0
Stars in 7 days4
Rank10,907
Previous rank5,829
Rank change-5,078
7-day stars rank6,194
Previous 7-day stars rank6,193
7-day stars rank change-1
Total stars rank9,283
Previous total stars rank9,266
Total stars rank change-17
CountryUSA
README summary

Robotics 311: How to Build Robots and Make Them Move ROB 311 is an undergraduate robotics course at the University of Michigan that introduces the fundamentals of mechanical design, control, fabrication, actuation, instrumentation, and computer interfaces required to realize robotic systems. Students will learn to analyze/simulate rigid body kinematics, kinetics, and dynamics, as well as assess the impedance properties of their designs. This first iteration was offered in Fall 2022. The course is based around building a ballbot, which

balances on a basketball to move around. Lectures All lecture videos are available on YouTube: ROB 311 Fall 2022 Playlist If a lecture features additional files, those are located in lecture files. Labs and hardware Labs are based around the design and build of the ballbot, requiring certain hardware and access to machines, including 3D printer, laser cutter, and water jet. The parts list (or see full bill of materials): Raspberry Pi Pico BlinkM led 3 Pololu 37D gearmotors 3

motor couplers acrylic sheets velcro strips 6 omni wheel halves 2 wired mouse basketball Note lab 1, a primer on soldering, is not included in this repository, and lab 5 is skipped.

Frequently asked questions

How many stars and forks are recorded?

michiganrobotics/rob311 has 1,266 stars and 242 forks.

What is the repository rank?

michiganrobotics/rob311 is ranked 10,907.

What language and category are recorded?

michiganrobotics/rob311 has 1,266 stars, uses Python and belongs to Misc.

Which repository is closest in rank?

michiganrobotics/rob311 is compared with daaain/claude-code-log, ranked 10,997 with 1,242 stars.

README

Robotics 311: How to Build Robots and Make Them Move

ROB 311 is an undergraduate robotics course at the University of Michigan that introduces the fundamentals of mechanical design, control, fabrication, actuation, instrumentation, and computer interfaces required to realize robotic systems. Students will learn to analyze/simulate rigid body kinematics, kinetics, and dynamics, as well as assess the impedance properties of their designs.

This first iteration was offered in Fall 2022. The course is based around building a ballbot, which balances on a basketball to move around.

Lectures

All lecture videos are available on YouTube: ROB 311 Fall 2022 Playlist

If a lecture features additional files, those are located in lecture files.

Labs and hardware

Labs are based around the design and build of the ballbot, requiring certain hardware and access to machines, including 3D printer, laser cutter, and water jet.
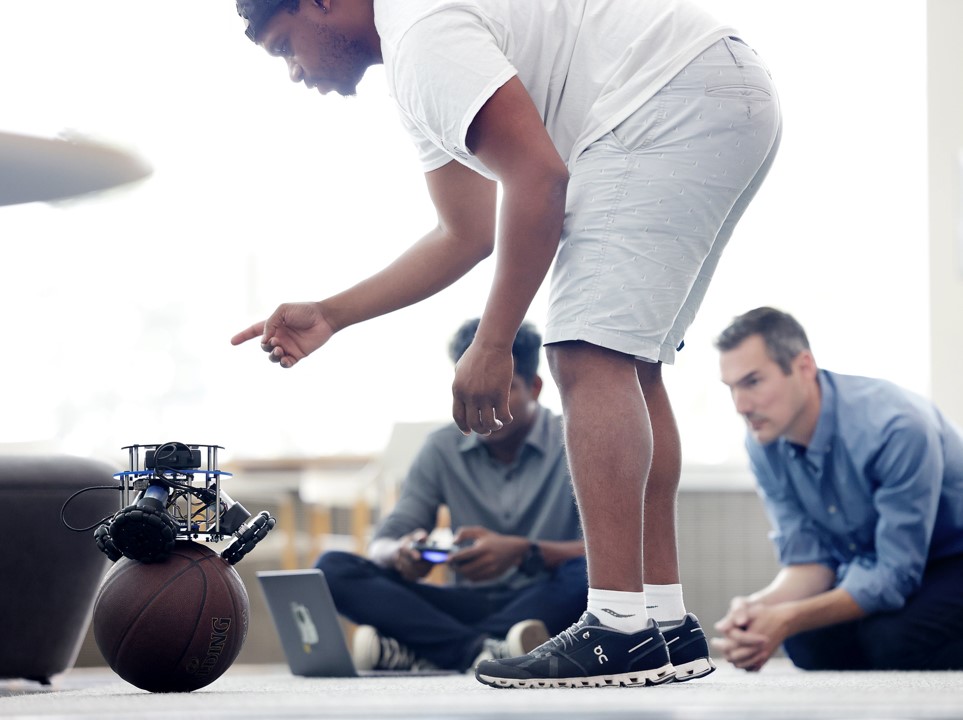
The parts list (or see full bill of materials):

  • Raspberry Pi Pico
  • BlinkM led
  • 3 Pololu 37D gearmotors
  • 3 motor couplers
  • acrylic sheets
  • velcro strips
  • 6 omni wheel halves
  • 2 wired mouse
  • basketball

Note lab 1, a primer on soldering, is not included in this repository, and lab 5 is skipped.

Course Plan

Lecture Topic YouTube Assignments Due
1 Introduction to robot development Video
L1 Lab: Soldering
2 Motors, transmissions, & drivers I Video
3 Motors, transmissions, & drivers II Video
L2 Lab: Raspberry Pi's
4 Mechanical modeling Video
5 Modeling & design Video HW 1
L3 Lab: Solidworks
6 Thermal modeling Video
7 Manufacturing Video
L4 Lab: Lasercutting
8 Additive manufacturing Video
9 Subtractive manufacturing Video
L6 Lab: Ballbot assembly Ballbot assembled
10 Manufacturing best practices Video
11 Gears, screws & linkages Video
L7 Lab: Python
12 Full planar model Video HW 2
13 Torque conversion Video
L8 Lab: Closed loop control
14 Kinematic conversions Video
L9 Lab: Kinematics
15 Sensors Video HW 3
16 Digital communications Video
L10 Lab: Stability control
17 Omni wheels Video
18 Ballbot work session No lecture
L11 Lab: Outer velocity loop control
19 Review Video Midterm (not publicly available)
L12 Lab: Virtual environments
20 Control Video HW 4
21 Control loop structure Video
L13 Lab: Filtering data
22 Ballbot work session No lecture
23 Filtering data Video
L14 Lab: Ballbot work session HW 5
24 Steering control Video
25 Final competition

Credits

  • Elliott Rouse, Associate Professor, U-M
  • Yves Nazon
  • Senthur Ayyappan

For more

Nearby in the ranking
Similar items