HybrIK: Hybrid Analytical-Neural Inverse Kinematics for Body Mesh Recovery
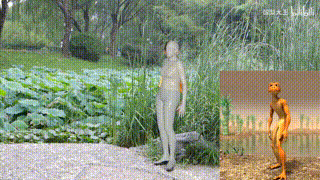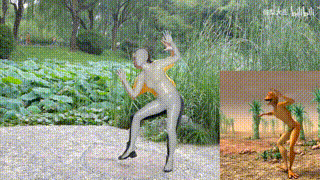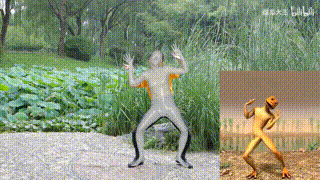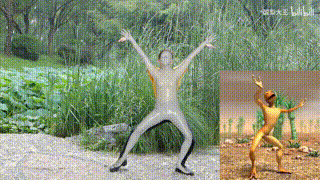


This repo contains the code of our papers:
HybrIK: A Hybrid Analytical-Neural Inverse Kinematics Solution for 3D Human Pose and Shape Estimation, In CVPR 2021
HybrIK-X: Hybrid Analytical-Neural Inverse Kinematics for Whole-body Mesh Recovery, TPAMI 2025
News :triangular_flag_on_post:
[2024/12/31] HybrIK-X is accepted by TPAMI!
[2023/06/02] Demo code for whole-body HybrIK-X is released.
[2022/12/03] HybrIK for Blender add-on is now available for download. The output of HybrIK can be imported to Blender and saved as fbx.
[2022/08/16] Pretrained model with HRNet-W48 backbone is available.
[2022/07/31] Training code with predicted camera is released.
[2022/07/25] HybrIK is now supported in Alphapose! Multi-person demo with pose-tracking is available.
[2022/04/27] is ready to use.
[2022/04/26] Achieve SOTA results by adding the 3DPW dataset for training.
[2022/04/25] The demo code is released!
Key idea: Inverse Kinematics
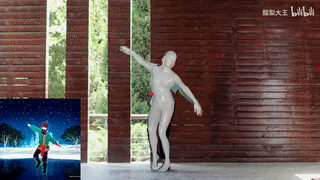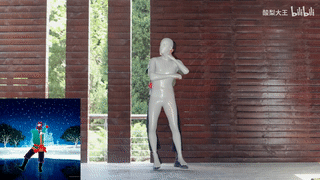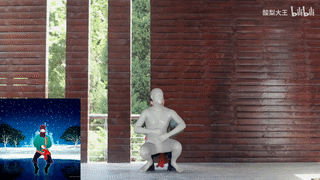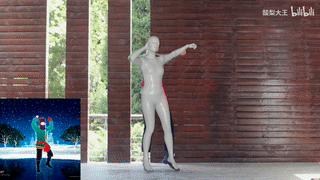
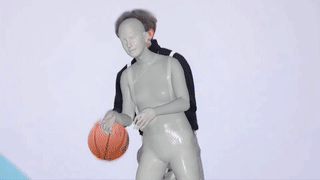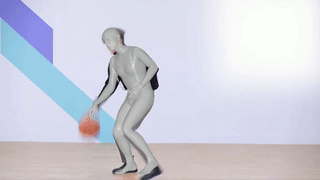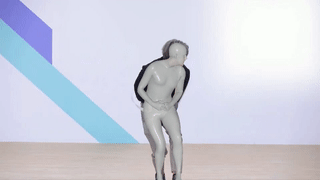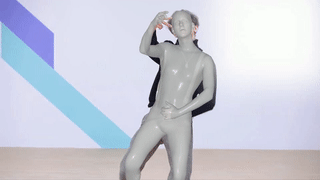
HybrIK and HybrIK-X are based on a hybrid inverse kinematics (IK) to convert accurate 3D keypoints to parametric body meshes.

Twist-and-Swing Decomposition
Installation instructions
# 1. Create a conda virtual environment.
conda create -n hybrik python=3.8 -y
conda activate hybrik

# 2. Install PyTorch
conda install pytorch==1.9.1 torchvision==0.10.1 -c pytorch

# 3. Install PyTorch3D (Optional, only for visualization)
conda install -c fvcore -c iopath -c conda-forge fvcore iopath
conda install -c bottler nvidiacub
pip install git+ssh://git@github.com/facebookresearch/pytorch3d.git@stable

# 4. Pull our code
git clone https://github.com/Jeff-sjtu/HybrIK.git
cd HybrIK

# 5. Install
pip install pycocotools
python setup.py develop  # or "pip install -e ."
Download necessary model files from [Google Drive | Baidu (code: 2u3c) ] and un-zip them in the ${ROOT} directory.
MODEL ZOO
HybrIK (SMPL)
| Backbone | Training Data | PA-MPJPE (3DPW) | MPJPE (3DPW) | PA-MPJPE (Human3.6M) | MPJPE (Human3.6M) | Download | Config |
|---|---|---|---|---|---|---|---|
| ResNet-34 | w/ 3DPW | 44.5 | 72.4 | 33.8 | 55.5 | model | cfg |
| HRNet-W48 | w/o 3DPW | 48.6 | 88.0 | 29.5 | 50.4 | model | cfg |
| HRNet-W48 | w/ 3DPW | 41.8 | 71.3 | 29.8 | 47.1 | model | cfg |
HybrIK-X (SMPL-X)
| Backbone | MVE (AGORA Test) | MPJPE (AGORA Test) | Download | Config |
|---|---|---|---|---|
| HRNet-W48 | 134.1 | 127.5 | model | cfg |
| HRNet-W48 + RLE | 112.1 | 107.6 | model | cfg |
Demo
First make sure you download the pretrained model (with predicted camera) and place it in the ${ROOT}/pretrained_models directory, i.e., ./pretrained_models/hybrik_hrnet.pth and ./pretrained_models/hybrikx_rle_hrnet.pth.
SMPL
- Visualize HybrIK on videos (run in single frame) and save results:
python scripts/demo_video.py --video-name examples/dance.mp4 --out-dir res_dance --save-pk --save-img
The saved results in ./res_dance/res.pk can be imported to Blender with our add-on.
- Visualize HybrIK on images:
python scripts/demo_image.py --img-dir examples --out-dir res
SMPL-X
python scripts/demo_video_x.py --video-name examples/dance.mp4 --out-dir res_dance --save-pk --save-img
Fetch data
Download Human3.6M, MPI-INF-3DHP, 3DPW and MSCOCO datasets. You need to follow directory structure of the data as below. Thanks to the great job done by Moon et al., we use the Human3.6M images provided in PoseNet.
|-- data
`-- |-- h36m
    `-- |-- annotations
        `-- images
`-- |-- pw3d
    `-- |-- json
        `-- imageFiles
`-- |-- 3dhp
    `-- |-- annotation_mpi_inf_3dhp_train.json
        |-- annotation_mpi_inf_3dhp_test.json
        |-- mpi_inf_3dhp_train_set
        `-- mpi_inf_3dhp_test_set
`-- |-- coco
    `-- |-- annotations
        |   |-- person_keypoints_train2017.json
        |   `-- person_keypoints_val2017.json
        |-- train2017
        `-- val2017
- Download Human3.6M parsed annotations. [ Google | Baidu ]
- Download 3DPW parsed annotations. [ Google | Baidu ]
- Download MPI-INF-3DHP parsed annotations. [ Google | Baidu ]
Train from scratch
./scripts/train_smpl_cam.sh test_3dpw configs/256x192_adam_lr1e-3-res34_smpl_3d_cam_2x_mix_w_pw3d.yaml
Evaluation
Download the pretrained model (ResNet-34 or HRNet-W48).
./scripts/validate_smpl_cam.sh ./configs/256x192_adam_lr1e-3-hrw48_cam_2x_w_pw3d_3dhp.yaml ./pretrained_hrnet.pth
Citing
If our code helps your research, please consider citing the following paper:
@inproceedings{li2021hybrik,
    title={Hybrik: A hybrid analytical-neural inverse kinematics solution for 3d human pose and shape estimation},
    author={Li, Jiefeng and Xu, Chao and Chen, Zhicun and Bian, Siyuan and Yang, Lixin and Lu, Cewu},
    booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition},
    pages={3383--3393},
    year={2021}
}

@article{li2023hybrik,
    title={HybrIK-X: Hybrid Analytical-Neural Inverse Kinematics for Whole-body Mesh Recovery},
    author={Li, Jiefeng and Bian, Siyuan and Xu, Chao and Chen, Zhicun and Yang, Lixin and Lu, Cewu},
    journal={arXiv preprint arXiv:2304.05690},
    year={2023}
}