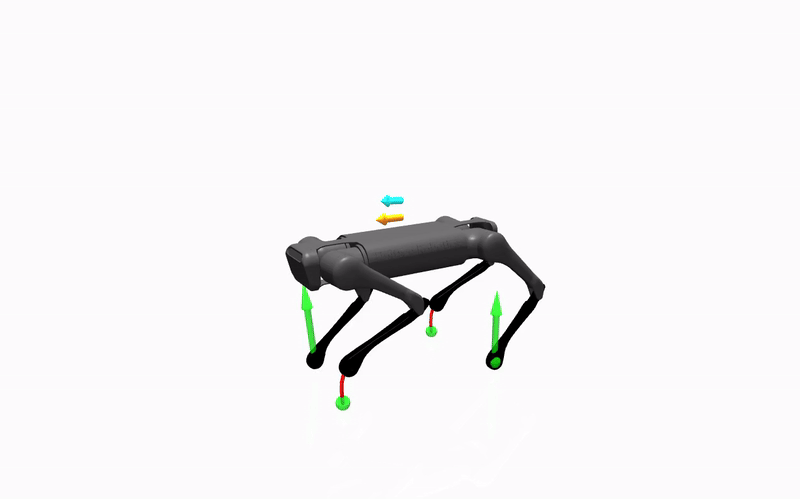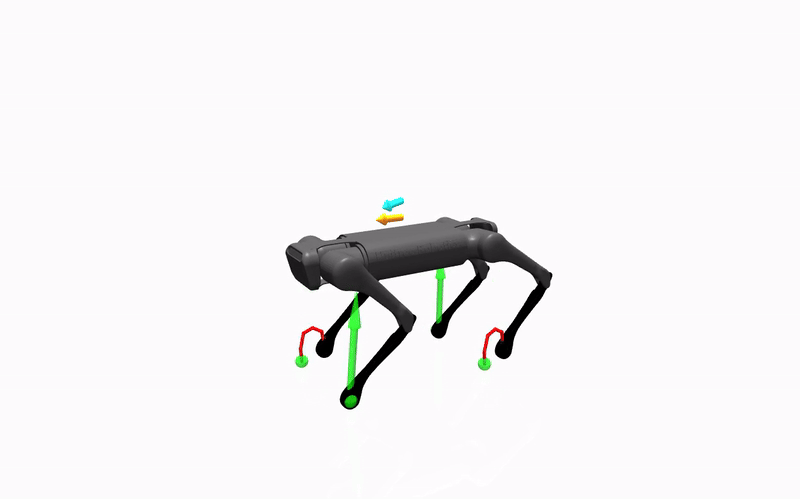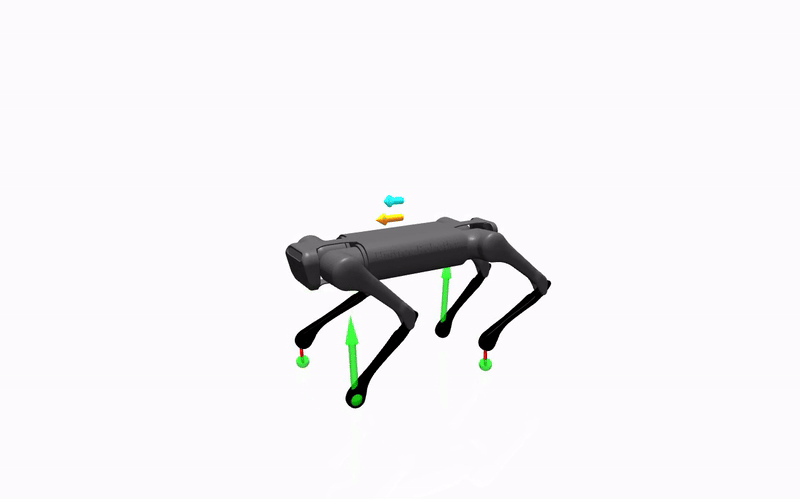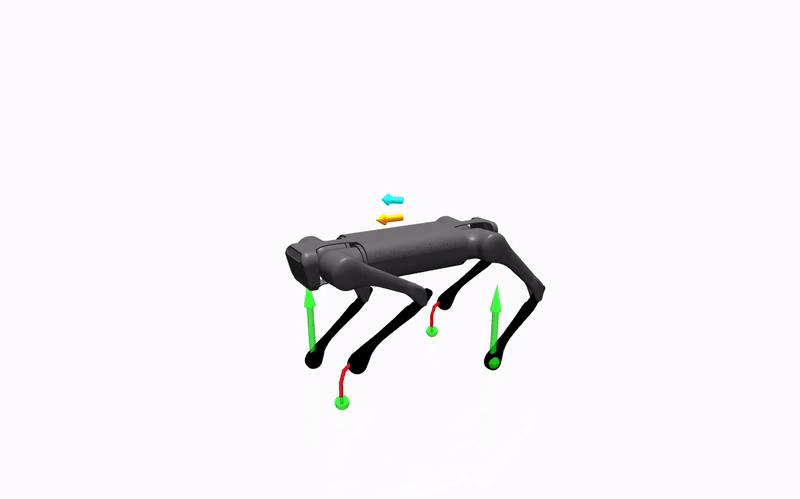
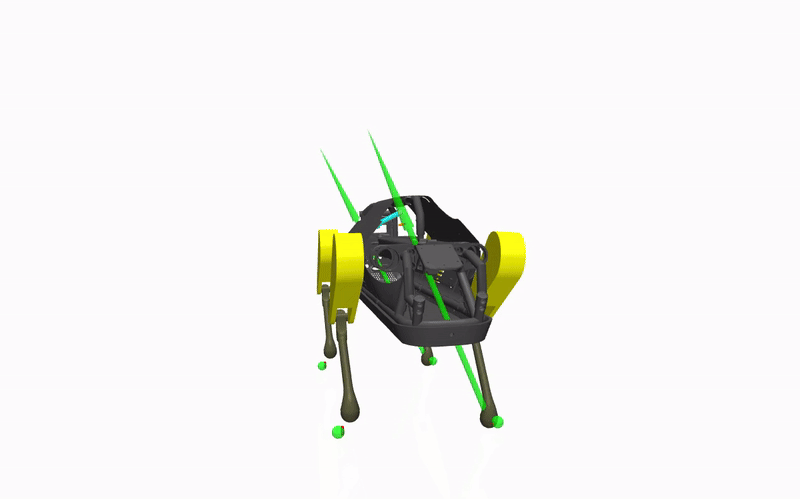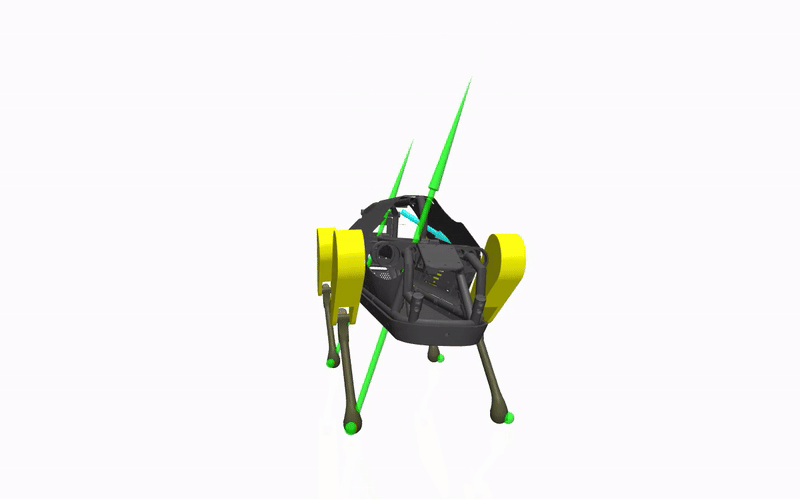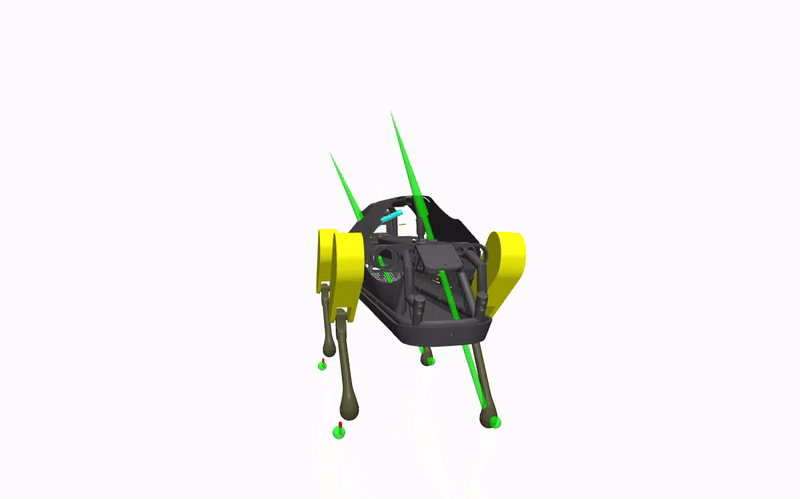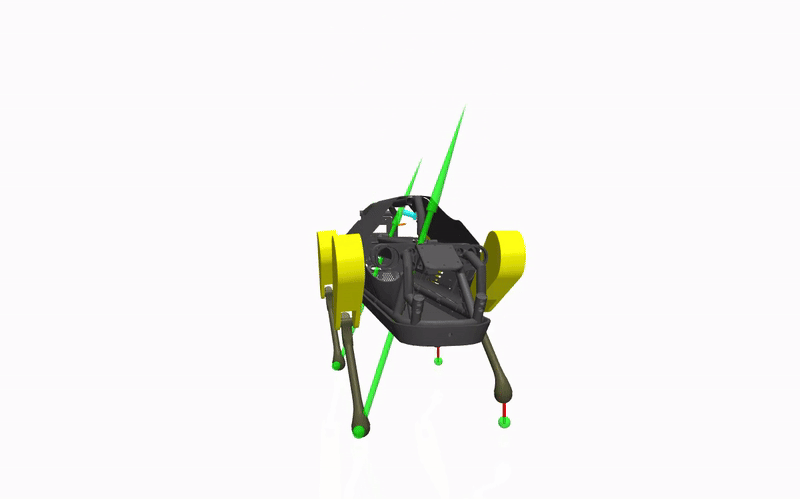
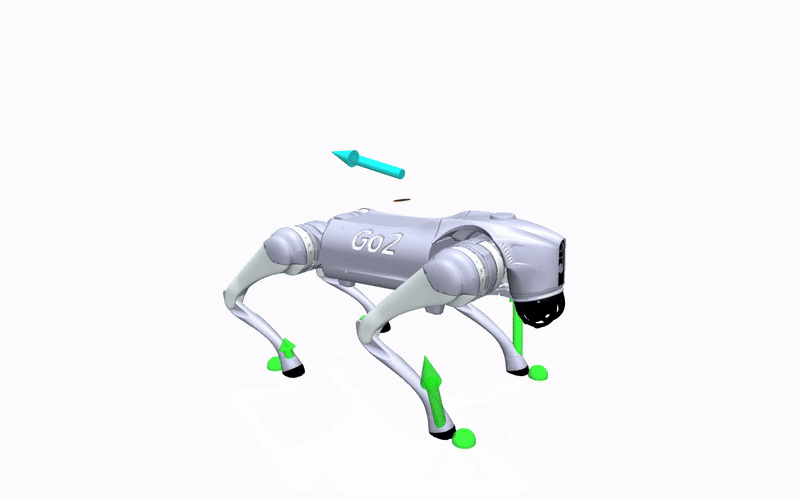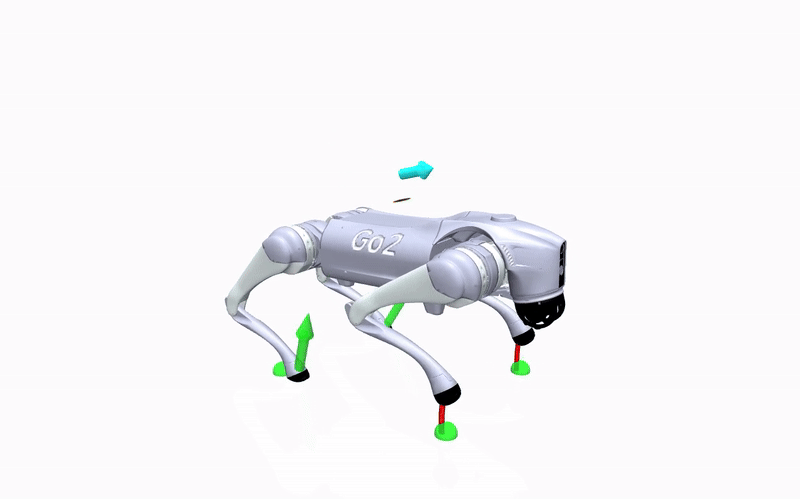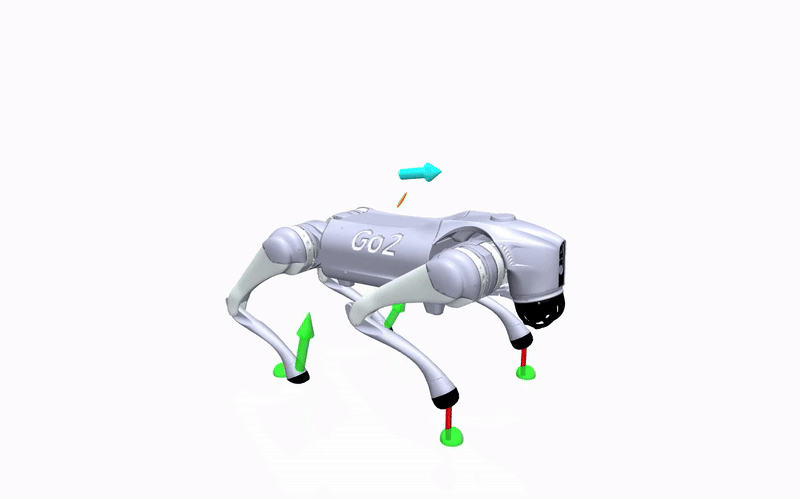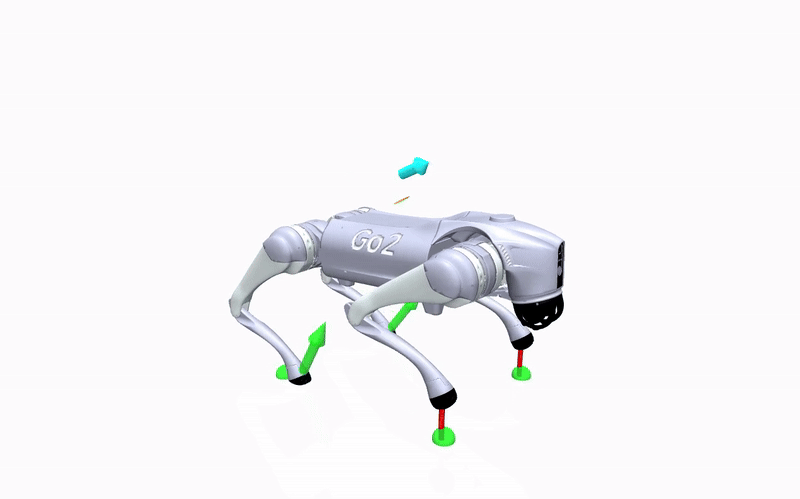
Overview
This repo contains a model predictive controller based on the single rigid body model and written in Python. It comes in two flavours: gradient-based via acados or sampling-based via jax. The controller is tested on real robots and is compatible with Mujoco.
Features gradient-based mpc:
- less than 5ms computation on an intel i7-13700H cpu
- optional integrators for model mismatch
- optional smoothing for the ground reaction forces
- optional foothold optimization
- optional real-time iteration or advanced-step real-time iteration
- optional zero moment point/center of mass constraints
- optional lyapunov-based criteria
Features sampling-based mpc:
- 10000 parallel rollouts in less than 2ms on an nvidia 4050 mobile gpu!
- optional step frequency adaptation for enhancing robustness
- implements different strategies: random sampling, mppi, cemppi and ot-mpc
- different control parametrizations: zero-order, linear splines or cubic splines (see mujoco-mpc)
- optional control refinement via rollout gradient
- optional high-frequency feedback gains via Feedback-MPPI
Real-world deployment via:
- muse for state estimation
- unitree-ros2-dls for unitree robot communication
Supported robots:
- GO2
- A2
- B2
- GO1
- Aliengo
- Spot
- Mini-Cheetah
- HyqReal1
- HyqReal2
Installation and Run
See here.
How to contribute
PRs are very welcome (search for TODO in the issue, or add what you like)!
Citing this work
If you find the work useful, please consider citing one of our works:
On the Benefits of GPU Sample-Based Stochastic Predictive Controllers for Legged Locomotion (IROS-2024):
@INPROCEEDINGS{turrisi2024sampling,
  author={Turrisi, Giulio and Modugno, Valerio and Amatucci, Lorenzo and Kanoulas, Dimitrios and Semini, Claudio},
  booktitle={2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  title={On the Benefits of GPU Sample-Based Stochastic Predictive Controllers for Legged Locomotion},
  year={2024},
  pages={13757-13764},
  doi={10.1109/IROS58592.2024.10801698}}
](https://arxiv.org/abs/2605.02147)
Adaptive Non-Linear Centroidal MPC With Stability Guarantees for Robust Locomotion of Legged Robots (RAL-2025):
@ARTICLE{elobaid2025adaptivestablempc,
  author={Elobaid, Mohamed and Turrisi, Giulio and Rapetti, Lorenzo and Romualdi, Giulio and Dafarra, Stefano and Kawakami, Tomohiro and Chaki, Tomohiro and Yoshiike, Takahide and Semini, Claudio and Pucci, Daniele},
  journal={IEEE Robotics and Automation Letters},
  title={Adaptive Non-Linear Centroidal MPC With Stability Guarantees for Robust Locomotion of Legged Robots},
  year={2025},
  volume={10},
  number={3},
  pages={2806-2813},
  doi={10.1109/LRA.2025.3536296}}
Maintainer
This repository is maintained by Giulio Turrisi and Daniel Ordonez.