DART
DART (Dynamic Animation and Robotics Toolkit) is an open-source C++17 library, with Python bindings (dartpy), for the kinematics, dynamics, and contact simulation of articulated rigid and soft bodies in robotics and computer animation. It represents articulated systems in generalized coordinates and computes their motion with Featherstone's Articulated Body Algorithm, which makes it accurate and stable.
[!NOTE]
mainis the development branch. For the latest stable release, install a package below.
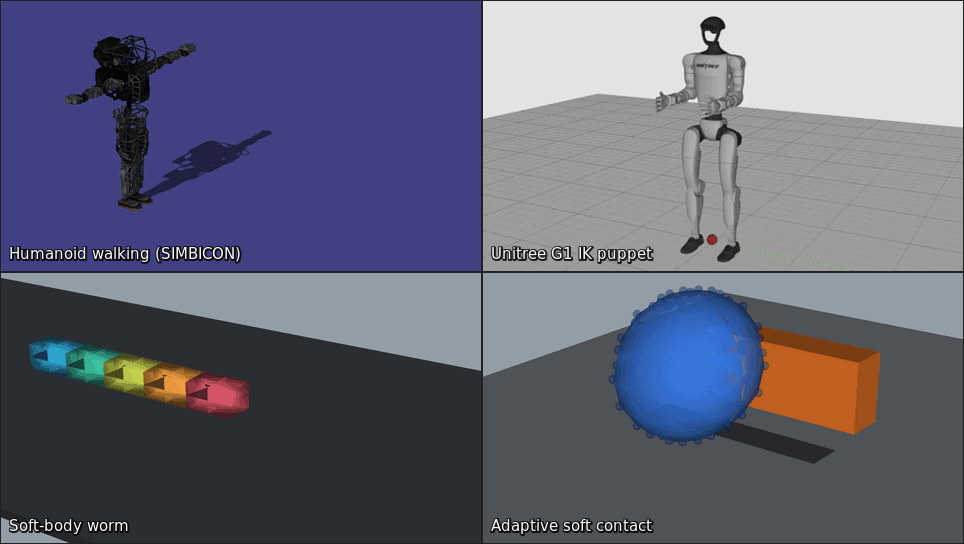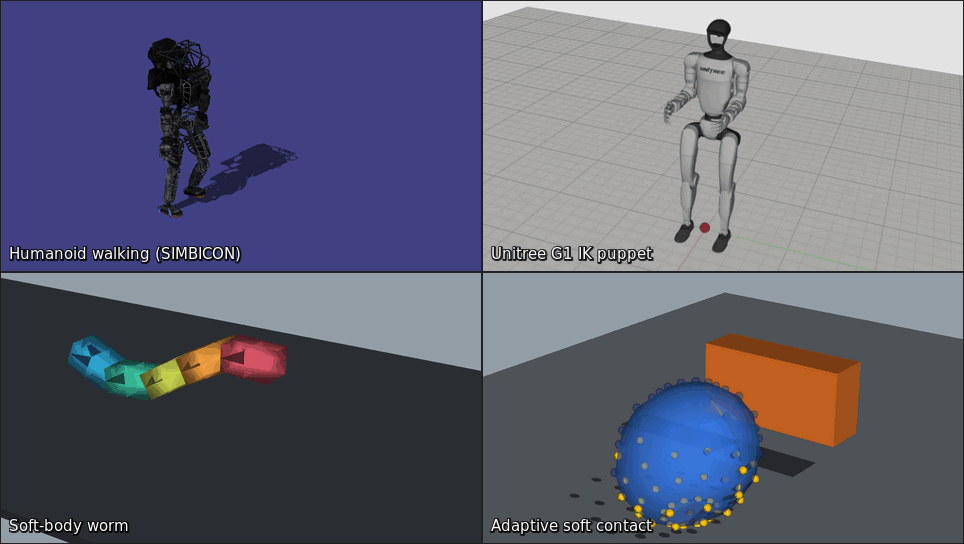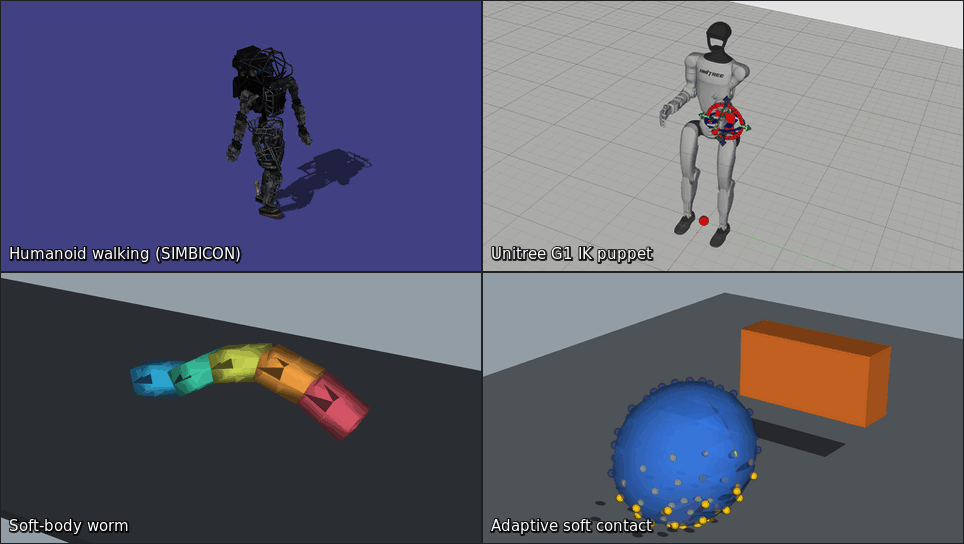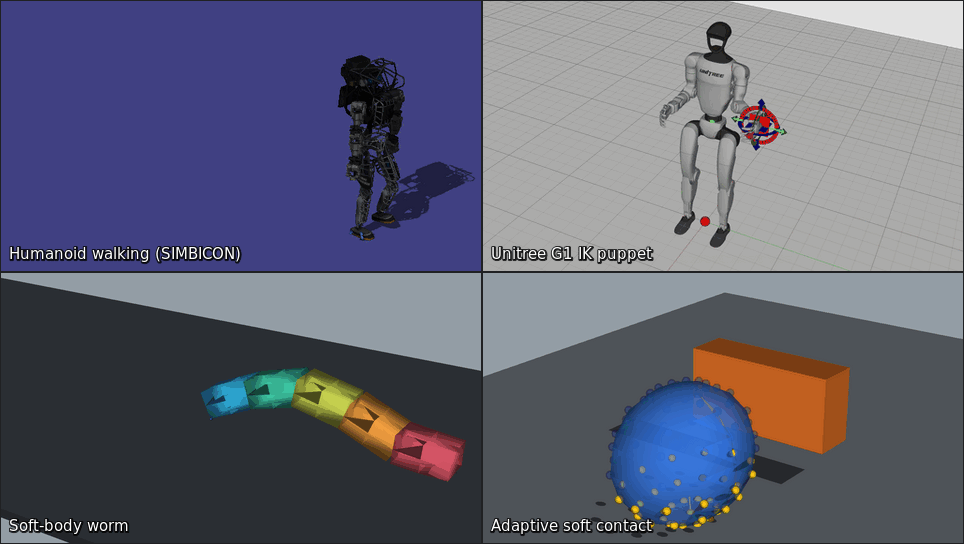
Atlas, soft-worm, and soft-contact scenes from dart-demos (pixi run demos), plus a Unitree G1 IK puppet from an earlier example
Why DART?
- Research-grade dynamics — Featherstone's algorithms in generalized coordinates, with direct access to the mass matrix, Coriolis and gravity forces, Jacobians, and their derivatives
- Contacts and constraints — LCP-based contact with Dantzig and PGS solvers, joint limits, closed kinematic loops, and soft bodies; collision detection through FCL (default), Bullet, ODE, or DART's native detector
- Model loading — URDF, SDF, SKEL, and MJCF (experimental) parsers
- Kinematics and control — hierarchical whole-body inverse kinematics with analytical solver support (e.g., IkFast), plus operational-space and stable-PD control examples
- C++ and Python — the same engine through dartpy, packages on PyPI, conda-forge, and major package managers, and reproducible source builds with pixi
- Battle-tested — powers Gazebo through gz-physics, and is used by research labs worldwide
Quick Start
Python
import dartpy as dart

world = dart.simulation.World()  # 1 ms time step, gravity along -z

# A shapeless 1 kg rigid body (the default inertia) free-falling from z = 1 m.
body = dart.dynamics.Skeleton("body")
body.createFreeJointAndBodyNodePair()
body.setPosition(5, 1.0)  # FreeJoint DOFs: rotation (0-2), translation (3-5)
world.addSkeleton(body)

for _ in range(100):
    world.step()

print(f"t = {world.getTime():.3f} s, z = {body.getPosition(5):.3f} m")
# t = 0.100 s, z = 0.950 m
C++
#include

#include

int main()
{
  auto world = dart::simulation::World::create();

  // A shapeless 1 kg rigid body (the default inertia) free-falling from z = 1 m.
  auto body = dart::dynamics::Skeleton::create("body");
  body->createJointAndBodyNodePair();
  body->setPosition(5, 1.0); // FreeJoint DOFs: rotation (0-2), translation (3-5)
  world->addSkeleton(body);

  for (int i = 0; i < 100; ++i)
    world->step();

  std::cout << "t = " << world->getTime() << " s, z = " << body->getPosition(5)
            << " m\n";
}
# CMakeLists.txt next to main.cpp
cmake_minimum_required(VERSION 3.22.1)
project(my_app CXX)
find_package(DART REQUIRED CONFIG)
add_executable(my_app main.cpp)
target_link_libraries(my_app PUBLIC dart)
Installation
Python
| Method | Command |
|---|---|
| pip | pip install dartpy |
| uv | uv add dartpy |
| pixi | pixi add dartpy |
| conda | conda install -c conda-forge dartpy |
PyPI wheels cover the most common platforms and Python versions; see the Python installation guide for the exact list.
C++
| Platform | Command |
|---|---|
| Cross-platform (recommended) | pixi add dartsim-cpp or conda install -c conda-forge dartsim-cpp |
| Ubuntu / Debian | sudo apt install libdart-all-dev |
| Arch Linux (AUR) | yay -S libdart |
| FreeBSD | pkg install dartsim |
| macOS (Homebrew) | brew install dartsim |
| Windows (vcpkg) | vcpkg install dartsim:x64-windows |
Distribution packages can lag behind the latest release: all distributions →. See the C++ installation guide for details.
Build from source
git clone https://github.com/dartsim/dart.git
cd dart
pixi run test   # configure, build, and run the C++ tests
pixi run demos  # build and launch the interactive demo app
See the build guide for options and other platforms.
Documentation
- User guide: English | 한국어
- Gallery: videos and projects · Performance: benchmark dashboard
- Questions: GitHub Discussions · AI Q&A (experimental): DeepWiki
Contributing
Contributions are welcome; start with the contributing guide.
- Architecture — components and compatibility boundaries
- Building and testing
- Background theory — dynamics, contact solving, and mathematical foundations
- Changelog
- AGENTS.md — guidelines for AI coding agents
Branches
main is the development branch for the next release: pull requests target it,
and all new patches land on it. Stable versions are available as
tagged releases and as the packages
above.
Citation
If you use DART in an academic publication, please consider citing the JOSS paper:
@article{Lee2018,
  doi       = {10.21105/joss.00500},
  url       = {https://doi.org/10.21105/joss.00500},
  year      = {2018},
  publisher = {The Open Journal},
  volume    = {3},
  number    = {22},
  pages     = {500},
  author    = {Jeongseok Lee and Michael X. Grey and Sehoon Ha and Tobias Kunz and Sumit Jain and Yuting Ye and Siddhartha S. Srinivasa and Mike Stilman and C. Karen Liu},
  title     = {DART: Dynamic Animation and Robotics Toolkit},
  journal   = {Journal of Open Source Software}
}
License
DART is licensed under the BSD 2-Clause License.