[NeurIPS'26] MemSkill: Learning and Evolving Memory Skills for Self-Evolving Agents.
Key parameters and specifications
Key parameters and specifications
Parameter
Value
Language
Python
Category
Model Development
Subcategory
Environments, Reinforcement Learning
Keywords
Benchmarks, Embodied, Physics, Robotics
Stars
587
Forks
90
Contributors
7
Created date
2023-02-09
Updated date
2026-10-16
Stars in 1 day
1
Stars in 7 days
3
Rank
6,665
Previous rank
16,319
Rank change
9,654
7-day stars rank
7,375
Previous 7-day stars rank
8,827
7-day stars rank change
1,452
Total stars rank
17,050
Previous total stars rank
17,074
Total stars rank change
24
Country
China
README summary
However, due to several difficulties, this version of the project is hard to maintain and update anymore. I sincerely apologize for the inconvenience. There may or may not be a clearner refactored version in the future. If you believe it is highly helpful to your research, you are welcomed to contact me by emailing to btx0424@outlook. OmniDrones *OmniDrones* is an open-source platform designed for reinforcement learning research on multi-rotor drone systems. Built on Nvidia Isaac Sim, *OmniDrones
* features highly efficient and flexible simulation that can be adopted for various research purposes. We also provide a suite of benchmark tasks and algorithm baselines to provide preliminary results for subsequent works. For usage and more details, please refer to the documentation. Unfortunately, it does not support Windows. Welcome to join our Discord for discussions and questions! Notice The initial release of **OmniDrones** is developed based on Isaac Sim 2022. The current version is developed based on Isaac Sim 4
. Announcement 2023-09-25 The initial release of **OmniDrones** is developed based on Isaac Sim 2022. 0) is expected to bring substantial changes but is not yet available, the APIs and usage of **OmniDrones** are subject to change. We will try our best to keep the documentation up-to-date. Announcement 2023-10-25 The new release of Isaac Sim (2023. 0) has brought substantial changes as well as new possibilities, among which the most important is new sensors. We
are actively working on it at the branch. The branch will still be maintained for compatibility. Feel free to raise issues if you encounter any problems or have ideas to discuss. Citation Please cite this paper if you use *OmniDrones* in your work: Acknowledgement Some of the abstractions and implementation was heavily inspired by Isaac Lab.
Frequently asked questions
How many stars and forks are recorded?
btx0424/OmniDrones has 587 stars and 90 forks.
What is the repository rank?
btx0424/OmniDrones is ranked 6,665.
What language and category are recorded?
btx0424/OmniDrones has 587 stars, uses Python and belongs to Model Development.
Which repository is closest in rank?
btx0424/OmniDrones is compared with neuralhydrology/neuralhydrology, ranked 6,666 with 587 stars.
README
Future of this Project
I greatly appreciate the interest by the community in this project. However, due to several difficulties, this version of the project is hard to maintain and update anymore. I sincerely apologize for the inconvenience. There may or may not be a clearner refactored version in the future. If you believe it is highly helpful to your research, you are welcomed to contact me by emailing to btx0424@outlook.com.
OmniDrones
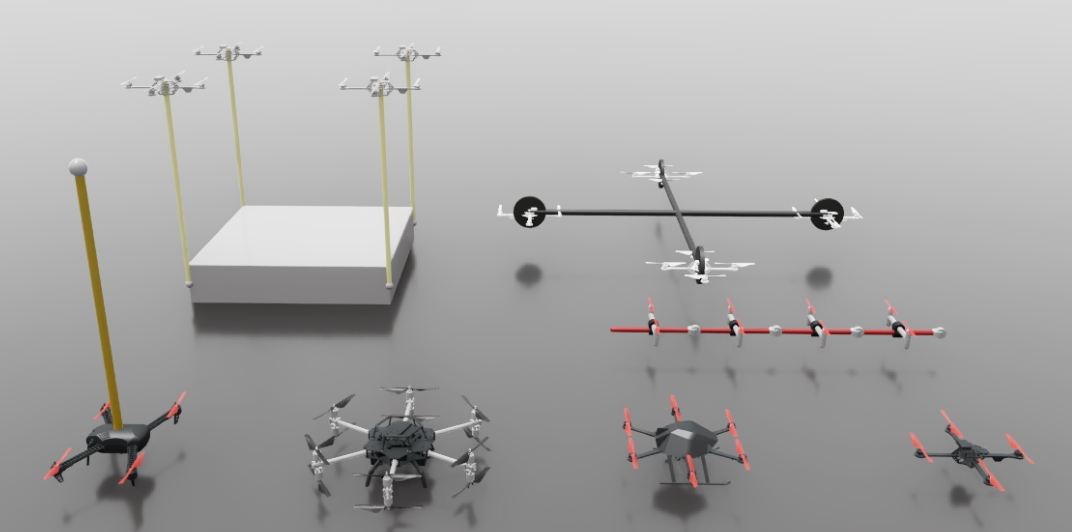
OmniDrones is an open-source platform designed for reinforcement learning research on multi-rotor drone systems. Built on Nvidia Isaac Sim, OmniDrones features highly efficient and flexible simulation that can be adopted for various research purposes. We also provide a suite of benchmark tasks and algorithm baselines to provide preliminary results for subsequent works.
For usage and more details, please refer to the documentation. Unfortunately, it does not support Windows.
Welcome to join our Discord for discussions and questions!
Notice
The initial release of OmniDrones is developed based on Isaac Sim 2022.2.0. It can be found at the release branch. The current version is developed based on Isaac Sim 4.1.0.
Announcement 2023-09-25
The initial release of OmniDrones is developed based on Isaac Sim 2022.2.0. As the next version of
Isaac Sim (2023.1.0) is expected to bring substantial changes but is not yet available, the APIs and usage
of OmniDrones are subject to change. We will try our best to keep the documentation up-to-date.
Announcement 2023-10-25
The new release of Isaac Sim (2023.1.0) has brought substantial changes as well as new possibilities, among
which the most important is new sensors. We are actively working on it at the devel branch. The release
branch will still be maintained for compatibility. Feel free to raise issues if you encounter any problems
or have ideas to discuss.
Citation
Please cite this paper if you use OmniDrones in your work:
@misc{xu2023omnidrones,
    title={OmniDrones: An Efficient and Flexible Platform for Reinforcement Learning in Drone Control},
    author={Botian Xu and Feng Gao and Chao Yu and Ruize Zhang and Yi Wu and Yu Wang},
    year={2023},
    eprint={2309.12825},
    archivePrefix={arXiv},
    primaryClass={cs.RO}
}
Acknowledgement
Some of the abstractions and implementation was heavily inspired by Isaac Lab.