🌍 Boundless-World-Model
[](https://huggingface.co/spaces/WorldArena/WorldArena)
[](https://huggingface.co/BLM-Lab/Boundless-World-Model)
[](https://arxiv.org/abs/2607.29302)
BWM is a physically consistent, action-conditioned video world model built upon Wan2.2-TI2V-5B, serving as a low-cost yet high-fidelity simulator for robotic manipulation.
🗞️ News
- [2026-07] 📄 Technical report released! Read the BWM technical report on arXiv.
- [2026-05] 🏆 Top results on WorldArena Leaderboard! BLM ranks 1st among open-source models on Track 1 and Track 2 Data Engine, while BWM-fast ranks 2nd overall on Track 1.
- [2026-05] 🚀 Inference code released! Generate action-conditioned robot manipulation videos with BWM. See 🛠️ Usage.
- [2026-05] 🎉 Model definition released! The BWM architecture and core model components are now available.
🏆 Competition Results
CVPR 2026 WorldArena Challenge
-
BLM: 🥇 1st Place among open-source models on Track 1 and Track 2 Data Engine.
-
BWM-fast: 🥈 2nd Place on the overall Track 1 leaderboard.
 Track 1 open-source leaderboard  Track 2 Data Engine open-source leaderboard  Track 1 overall leaderboard
Leaderboard: https://huggingface.co/spaces/WorldArena/WorldArena
Table of Contents
- ✅ TODO
- 🏗️ Framework
- 🎬 Qualitative Results
- 🛠️ Usage
- 🏋️ Training
- 🙏 Acknowledgements
- 📧 Contact
- 📜 Citing
✅ TODO
- [x] Release inference code
- [x] Release model definition
- [x] Release model weights
- [ ] Release training code
- [x] Release technical report
🏗️ Framework
-
Overview of BWM. BWM combines action-aligned data construction, action-conditioned world simulation, and downstream robot-learning applications.

-
Overview of BWM framework. BWM autoregressively predicts future observation chunks from the initial observation, dynamic history, and action chunk. Robot actions enter the video diffusion backbone as cross-attention tokens and action-conditioned timestep embeddings.

🎬 Qualitative Results
CVPR 2026 WorldArena Challenge
The following simulation scenes are generated autoregressively by BWM from initial frames and action sequences in the WorldArena test set, achieving high-fidelity visual realism while maintaining long-horizon physical consistency.
🧩 Scene 1: Compositional Spatial Rearrangement


- Task: arrange blocks by size, stack bowls
- Challenge: Multi-object spatial ordering, stacking stability, and contact-rich placement
- Ours:
- ✅ Preserves object identity and target layout
- ✅ Maintains stable stacking contacts
- ✅ Predicts adaptive gripper control
🚪 Scene 2: Articulated Hinge Interaction


- Task: open microwave, open laptop
- Challenge: Articulated hinge motion, constrained rotation, and persistent object state
- Ours:
- ✅ Captures hinge-constrained opening dynamics
- ✅ Maintains coherent object geometry during rotation
- ✅ Preserves opened states over long-horizon rollouts
🕹️ Scene 3: Fine-Grained Affordance Interaction


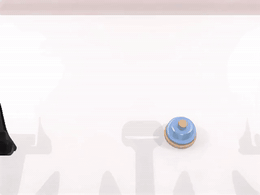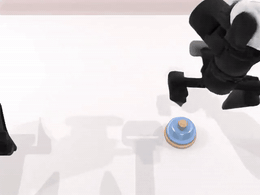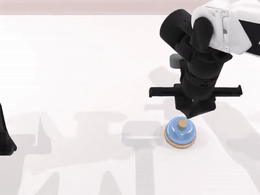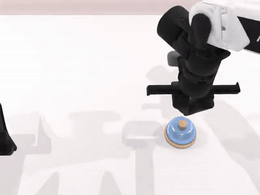

- Task: turn switch, hang mug, click bell, stamp seal
- Challenge: Small contact regions, constrained placement, and precise state-changing interactions
- Ours:
- ✅ Captures fine-grained affordance dynamics
- ✅ Aligns contact with object affordances
- ✅ Preserves state-changing interactions
🤝 Scene 4: Bimanual Coordination and Handover


- Task: hand over block, hand over mic
- Challenge: Dual-arm synchronization, inter-arm occlusion, and coordinated grasp timing
- Ours:
- ✅ Models synchronized dual-arm motion
- ✅ Preserves object continuity
- ✅ Avoids close-contact collisions
📦 Scene 5: Long-Horizon Constrained Placement


- Task: put object in cabinet, put bottles in dustbin
- Challenge: Long-horizon transport, partial occlusion, and constrained final placement
- Ours:
- ✅ Maintains long-horizon scene coherence
- ✅ Handles occlusion without object drift
- ✅ Produces stable constrained placement
Out-of-Distribution Generalization
To test generalization beyond benchmark initial states, we use GPT-Image-2-created initial scenes with original robot action sequences and let BWM autoregressively roll out the future under object appearance shifts.


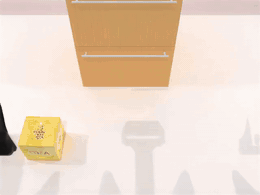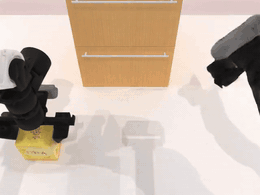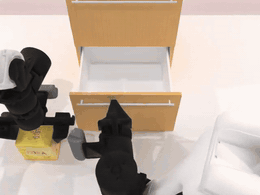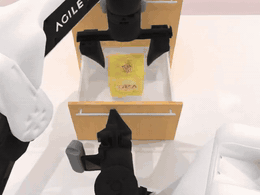


- Task: shake bottle, put object in cabinet
- Challenge: Novel initial scenes and object appearance shifts
- Ours:
- ✅ Generalizes to GPT-Image-2-created initial scenes
- ✅ Preserves action-conditioned dynamics
- ✅ Maintains coherent robot-object interaction
🛠️ Usage
Quick Start: Video Generation Inference
Environment Setup
# Create conda environment
conda create -n BWM python=3.10.20
conda activate BWM

# Install PyTorch with CUDA support
pip install torch==2.8.0 torchvision==0.23.0 torchaudio==2.8.0 --index-url https://download.pytorch.org/whl/cu128

# Install DiffSynth-Studio
pip install diffsynth==2.0.11

# Install dependencies
pip install -r requirements.txt
Model Weights
Download the Wan2.2-TI2V-5B base model from ModelScope:
modelscope download --model Wan-AI/Wan2.2-TI2V-5B --local_dir models/Wan2.2-TI2V-5B
Download the BWM checkpoint from Hugging Face:
hf download BLM-Lab/Boundless-World-Model step-12000.safetensors --local-dir ckpt/BLM
Run Inference
The demo metadata, videos, actions, and normalization statistics are already included under demo/.
Set local paths before running inference:
cp scripts/local.example.sh scripts/local.sh
Update MODEL_PATHS and CKPT_PATH in scripts/local.sh, then run:
bash scripts/infer_example.sh
🏋️ Training
Coming soon !
🙏 Acknowledgements
This project builds upon the following open-source projects and benchmarks. We thank these teams for their contributions:
- Wan2.2: https://github.com/Wan-Video/Wan2.2
- DiffSynth-Studio: https://github.com/modelscope/DiffSynth-Studio
- WorldArena: https://github.com/tsinghua-fib-lab/WorldArena/
- ABot-PhysWorld: https://github.com/amap-cvlab/ABot-PhysWorld
We also acknowledge the following engineering contributions:
- Wentao Tan: basic architecture design · Email · GitHub
- Zengrong Lin: core code implementation · Email · GitHub
- Yang Sun: code refactoring and software maintainability · Email · GitHub
We further thank all project contributors for their valuable discussions, support for the paper experiments, and participation in the WorldArena challenge.
- Supervision: Heng Tao Shen
- Principal Investigator: Lei Zhu
- Student Project Leadership: Wentao Tan, Tianshi Wang
- WorldArena Challenge:
- Strategy Design: Wentao Tan, Bowen Wang
- Inference-Time Scaling: Tianshi Wang, Chenming Li
- Data Pipeline: Bowen Wang, Enci Xie, Wentao Tan, Chenming Li, Yang Sun, Yipeng Chen, Xuebin Fang, Zequn Wang
- Metric Analysis: Wentao Tan, Enci Xie, Chenming Li, Tianshi Wang
- Closed-Loop Rollout: Zequn Wang, Zhe Li, Heng Zhi, Zengrong Lin
- Model Architecture:
- Innovation: Wentao Tan, Zengrong Lin, Enci Xie, Baixu Ji
- Model Training: Zengrong Lin, Yang Sun, Zhe Li
- Post Training: Yang Sun, Zengrong Lin, Wentao Tan
- Baselines: Zequn Wang, Heng Zhi, Yipeng Chen, Chenyu Liu, Wenjie Yang, Hao Xue, Chen Xu
- VLAs Support:
- Real-World: Heng Zhi
- Simulation: Heng Zhi, Baixu Ji
- Infrastructure:
- Distributed Evaluation: Wenhao Liu
- Real-World Setup: Zhe Li
- Discussion Support: Fengling Li, Pengfei Zhang
📧 Contact
Contributors are listed in alphabetical order by English name.
Baixu Ji, Bowen Wang, Chen Xu, Chenming Li, Chenyu Liu, Enci Xie, Fengling Li, Hao Xue, Heng Tao Shen, Heng Zhi, Lei Zhu, Pengfei Zhang, Tianshi Wang, Wenhao Liu, Wenjie Yang, Wentao Tan, Xuebin Fang, Yang Sun, Yipeng Chen, Zengrong Lin, Zequn Wang, Zhe Li
📜 Citing
If you find BWM is useful in your research or applications, please consider giving us a star 🌟.
@article{bwm2026,
  author       = {{BWM Team}},
  title        = {{BWM}: A Low-Cost High-Fidelity World Simulator for Robot Learning},
  year         = {2026},
  journal      = {arXiv preprint arXiv:2607.29302}
}