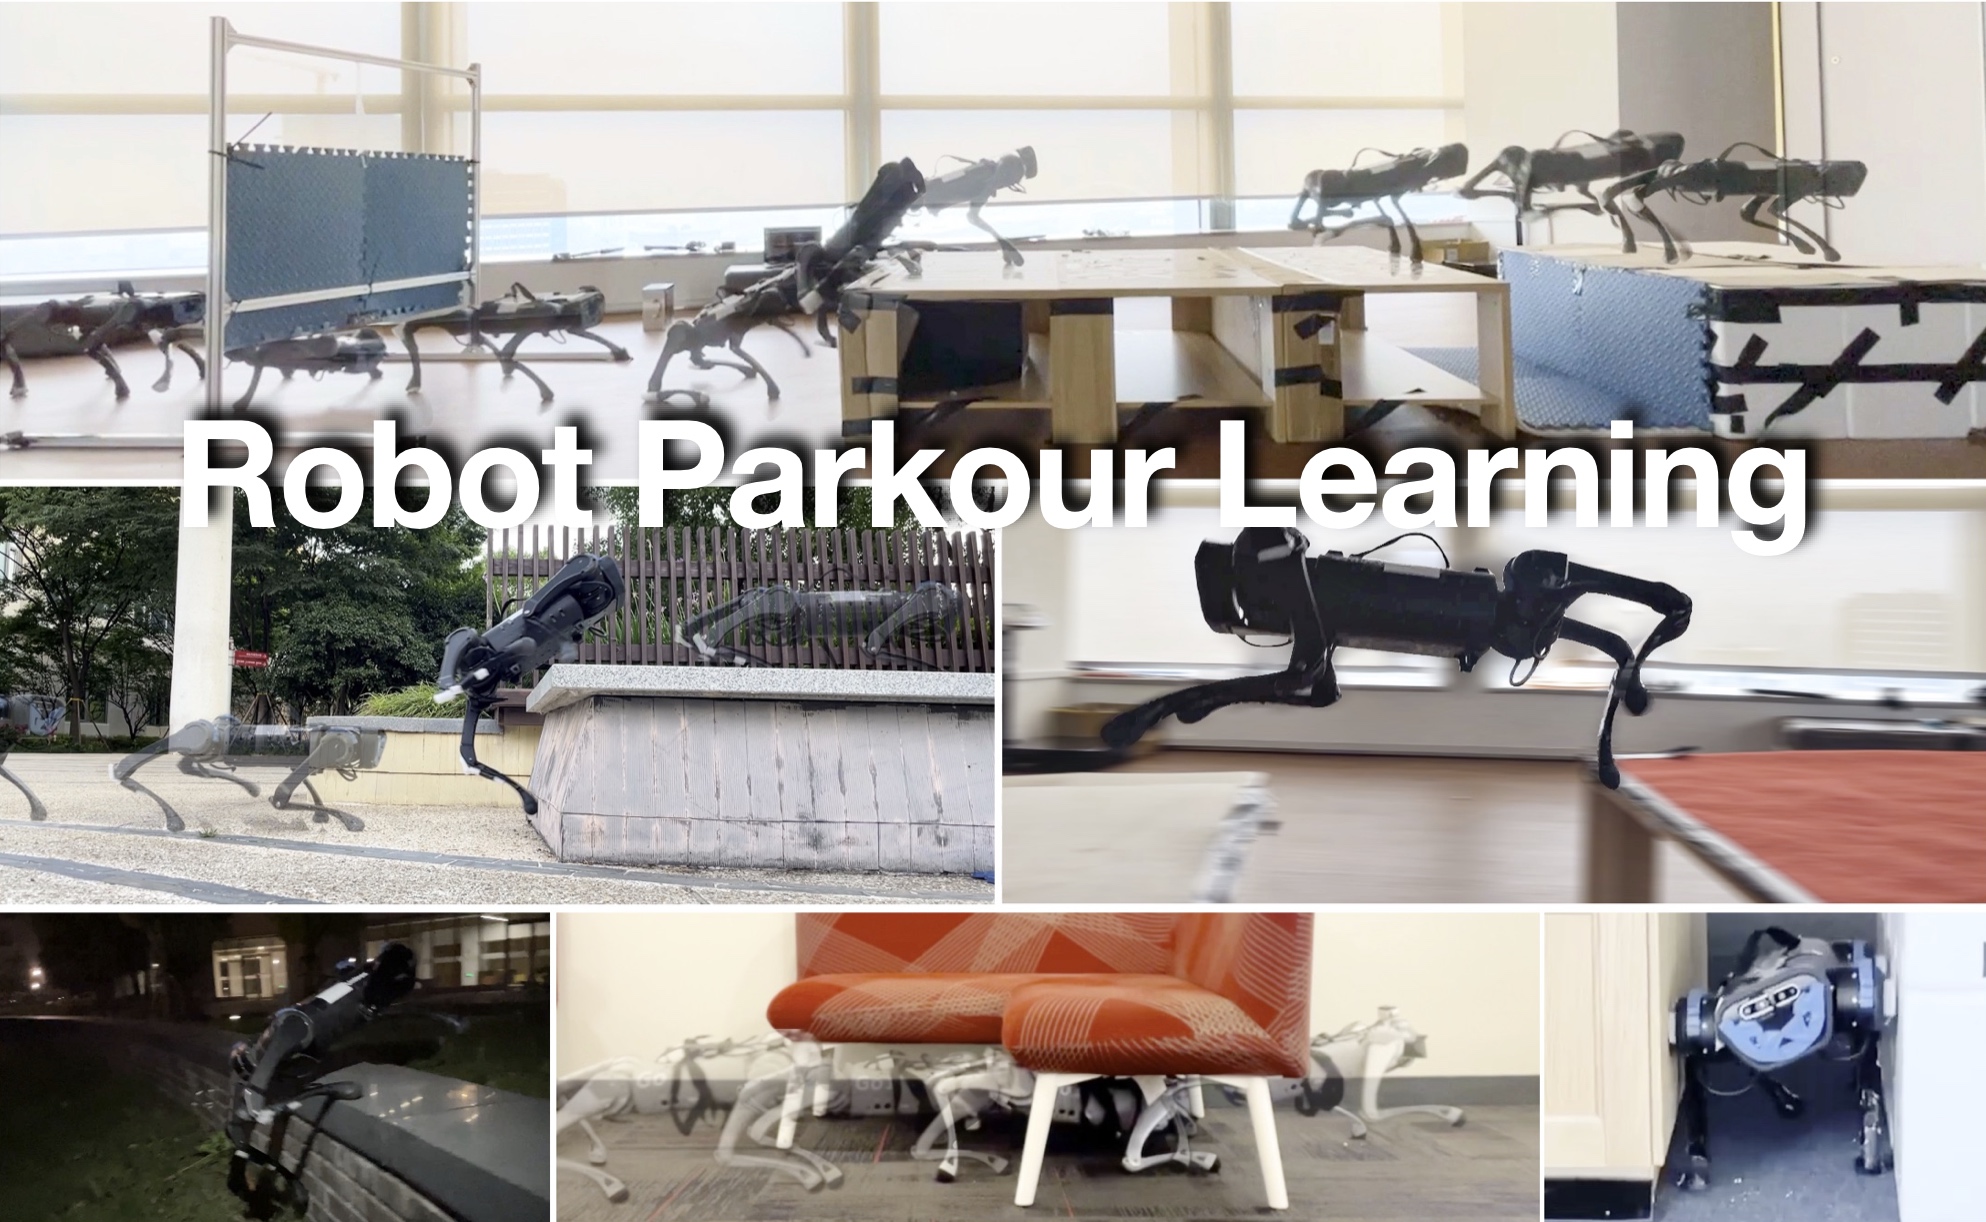
Robot Parkour Learning
Project website: https://robot-parkour.github.io/
Authors: Ziwen Zhuang*, Zipeng Fu*, Jianren Wang, Christopher Atkeson, Sören Schwertfeger, Chelsea Finn, Hang Zhao
Conference on Robot Learning (CoRL) 2023, Oral, Best Systems Paper Award Finalist (top 3)
Repository Structure
legged_gym: contains the isaacgym environment and config files.legged_gym/legged_gym/envs/{robot}/: contains all the training config files for a specific robotlegged_gym/legged_gym/envs/base/: contains all the environment implementation.legged_gym/legged_gym/utils/terrain/: contains the terrain generation code.
rsl_rl: contains the network module and algorithm implementation. You can copy this folder directly to your robot.rsl_rl/rsl_rl/algorithms/: contains the algorithm implementation.rsl_rl/rsl_rl/modules/: contains the network module implementation.
Training in Simulation
To install and run the code for training A1/Go2 in simulation, please clone this repository and follow the instructions in legged_gym/README.md.
Hardware Deployment
To deploy the trained model on your unitree Go1 robot, please follow the instructions in Deploy-Go1.md for deploying on the Unittree Go1 robot.
To deploy the trained model on your unitree Go2 robot, please follow the instructions in Deploy-Go2.md for deploying on the Unittree Go2 robot.
Trouble Shooting
If you cannot run the distillation part or all graphics computing goes to GPU 0 dispite you have multiple GPUs and have set the CUDA_VISIBLE_DEVICES, please use docker to isolate each GPU.
NOTE: When playing the distilled policy in simulation, DO remember to set ckpt_manipulator = None when configuring the runner. Please refer to #82 for more detail.
To Do
- [x] Go1 training configuration (does not guarantee the same performance as the paper)
- [ ] A1 deployment code
- [x] Go1 deployment code
- [x] Go2 training configuration example (does not guarantee the same performance as the paper)
- [x] Go2 deployment code example
Citation
If you find this project helpful to your research, please consider cite us! This is really important to us.
@inproceedings{
    zhuang2023robot,
    title={Robot Parkour Learning},
    author={Ziwen Zhuang and Zipeng Fu and Jianren Wang and Christopher G Atkeson and S{\"o}ren Schwertfeger and Chelsea Finn and Hang Zhao},
    booktitle={Conference on Robot Learning {CoRL}},
    year={2023}
}