Vision-based Agile Flight Training Code
Overview
This repository contains the training code for our research on Learning Vision-based Agile Flight via Differentiable Physics. Accepted by Nature Machine Intelligence'25.
Project webpage is alive.
Quick Demos
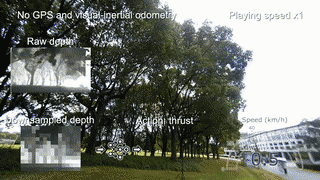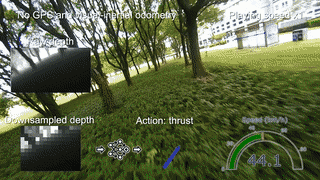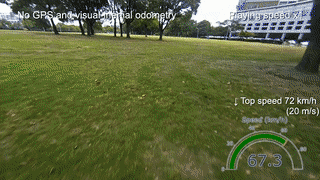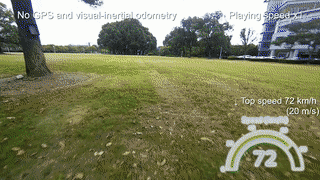
Single Agent Flights
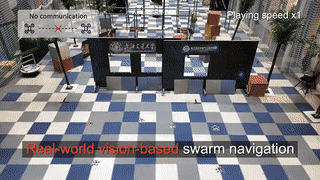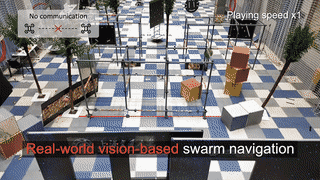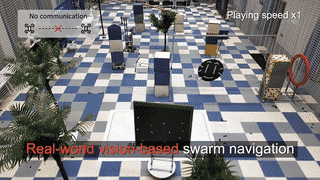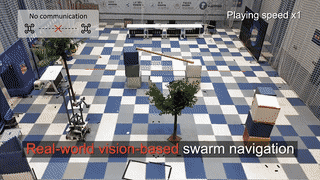
Swarm Tasks
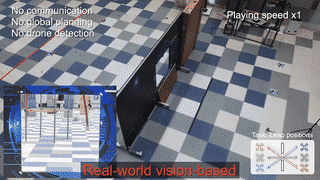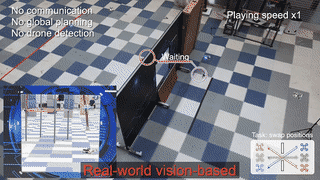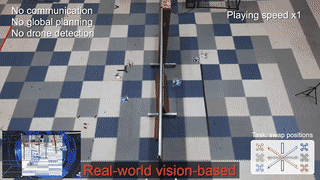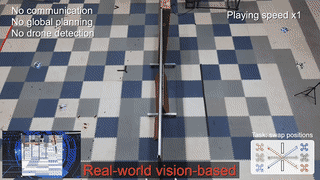
Environment Setup
Python Environment
The code is tested with the following environment:
- PyTorch: 2.2.2
- Python: 3.11
- CUDA: 11.8
The code should be compatible with other PyTorch and CUDA versions.
Build CUDA Ops
To build the CUDA operations, run the following command:
pip install -e src
Training
To start the training process, use the following command:
# For multi-agemt
python main_cuda.py $(cat configs/multi_agent.args)
# For single-agemt
python main_cuda.py $(cat configs/single_agent.args)
Evaluation
You need to download the simulation validation code from the GitHub release page. To evaluate the trained model in multi-agent settings, use the following command to launch the simulator:
cd
./LinuxNoEditor/Blocks.sh -ResX=896 -ResY=504 -windowed -WinX=512 -WinY=304 -settings=$PWD/settings.json
Citation
If using this repository, please cite our work
@article{zhang2025learning,
  title={Learning vision-based agile flight via differentiable physics},
  author={Zhang, Yuang and Hu, Yu and Song, Yunlong and Zou, Danping and Lin, Weiyao},
  journal={Nature Machine Intelligence},
  pages={1--13},
  year={2025},
  publisher={Nature Publishing Group}
}
Then, run the following command to evaluate the trained model:
python eval.py --resume --target_speed 2.5